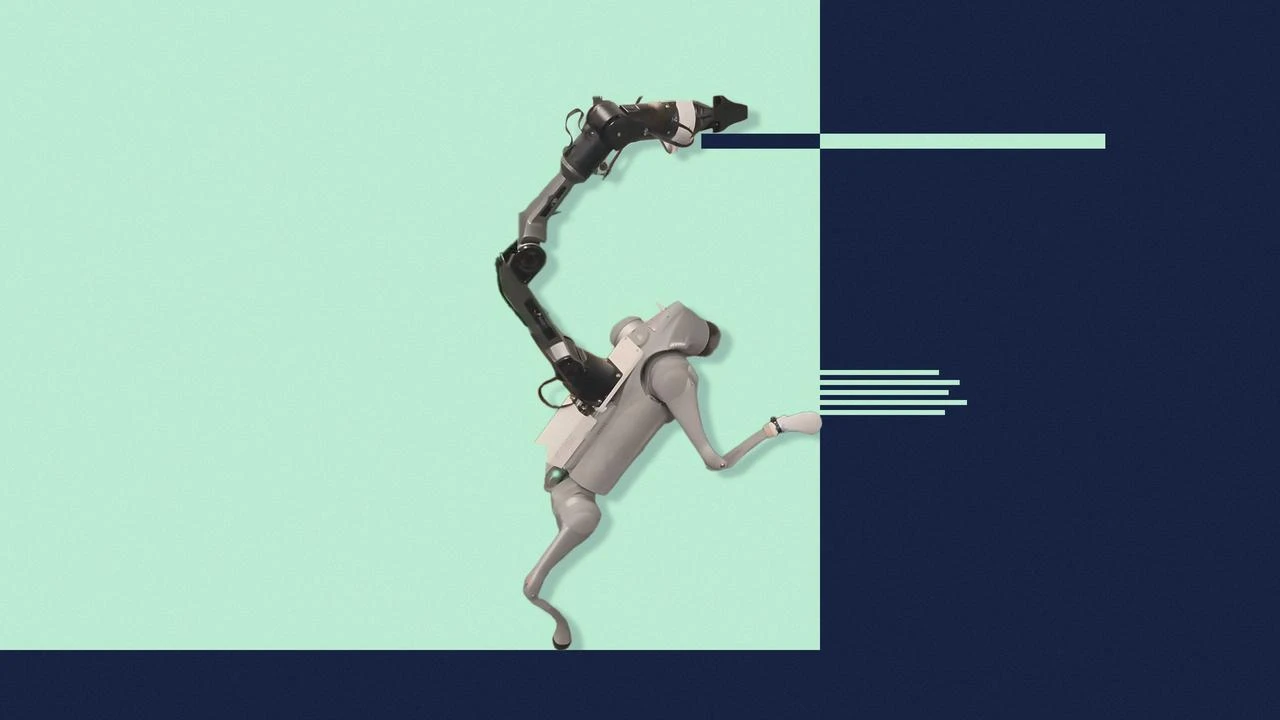
Carnegie Mellon Researchers Introduce ELEVATE Framework to Help Quadrupeds Acquire New Controllers from Task Failures
Quadruped robots with manipulators face a hard limit when required motions are absent from pre-trained libraries. The new ELEVATE framework enables these robots to autonomously diagnose missing physical capabilities during task failures and train new whole-body controllers using reinforcement learning.