Peking University Team Succeeds in 27 of 30 Real-Robot Dexterous Task Tests by Optimizing Hand-Object Configurations
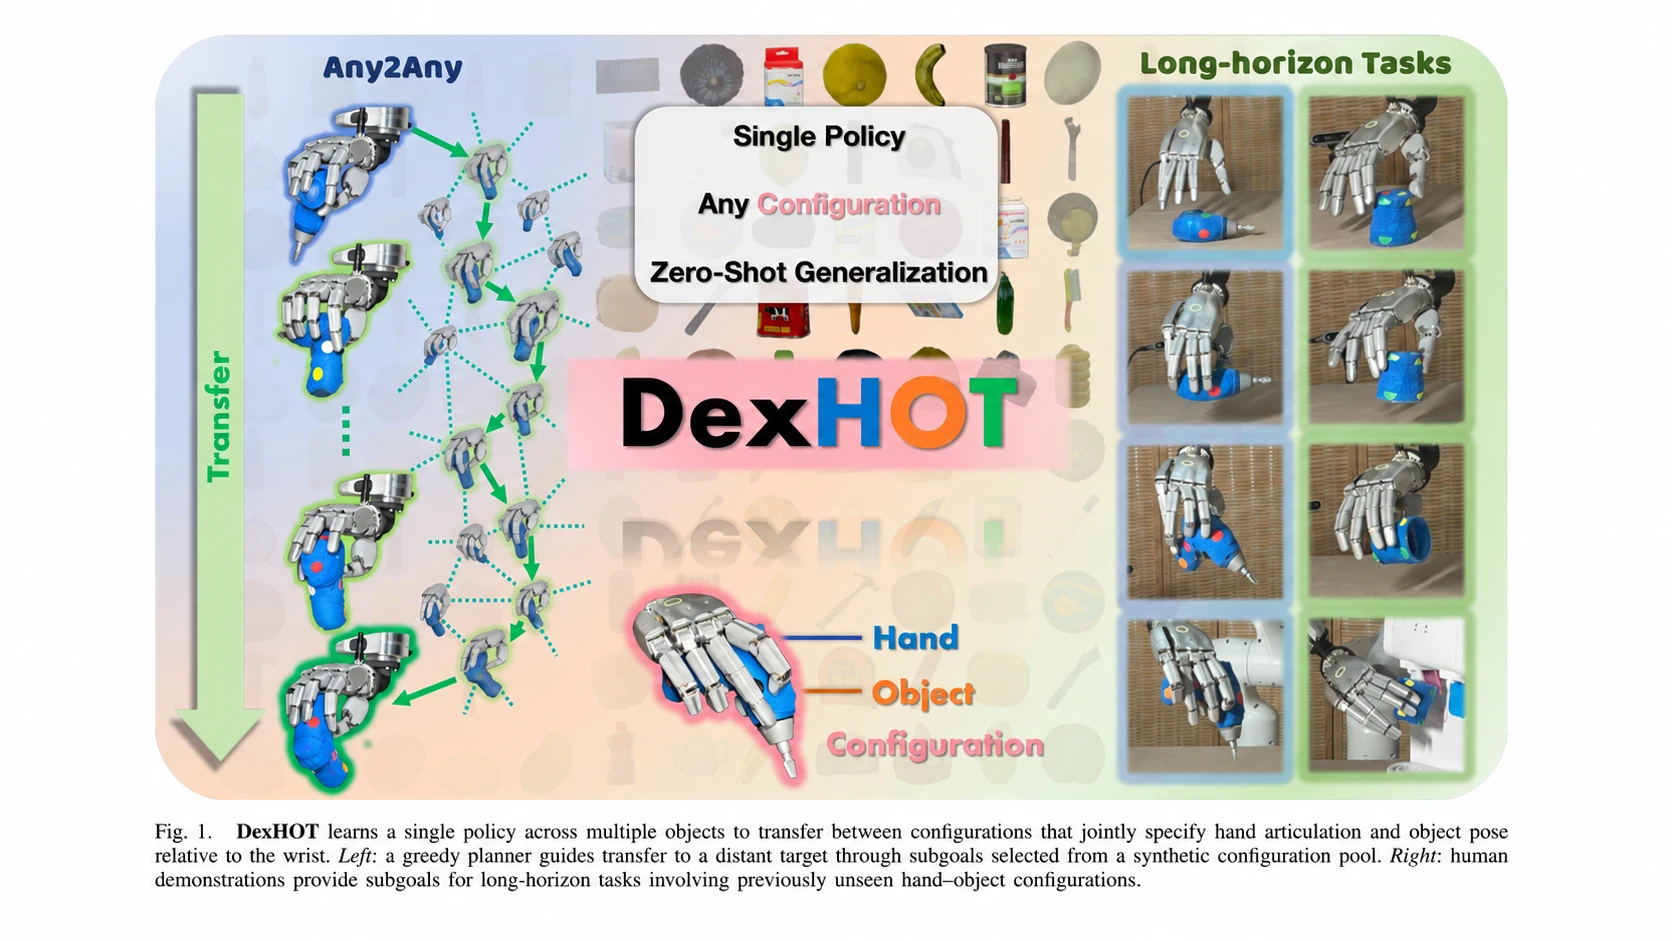
A joint team from Peking University, PrimeBot, and the Beijing Institute for General AI has introduced DexHOT, a framework that optimizes hand-object configurations rather than just object poses, achieving a 90% success rate in real-robot dexterous manipulation tasks.