Yunzhu Li: World Models Must Be Controllable to Train and Evaluate Robots | CoRL 2026
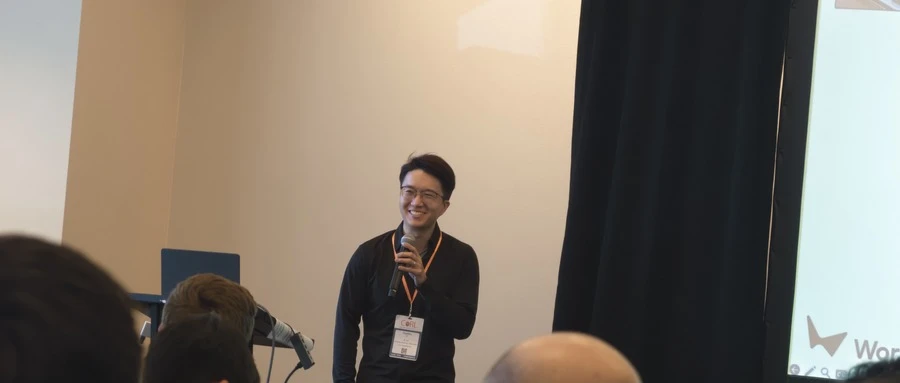
At the "Do Robots Need World Models?" workshop at CoRL 2026 on November 12, Columbia University's Yunzhu Li argued that world models must be highly controllable to serve as scalable data sources for robot training and policy evaluation.