
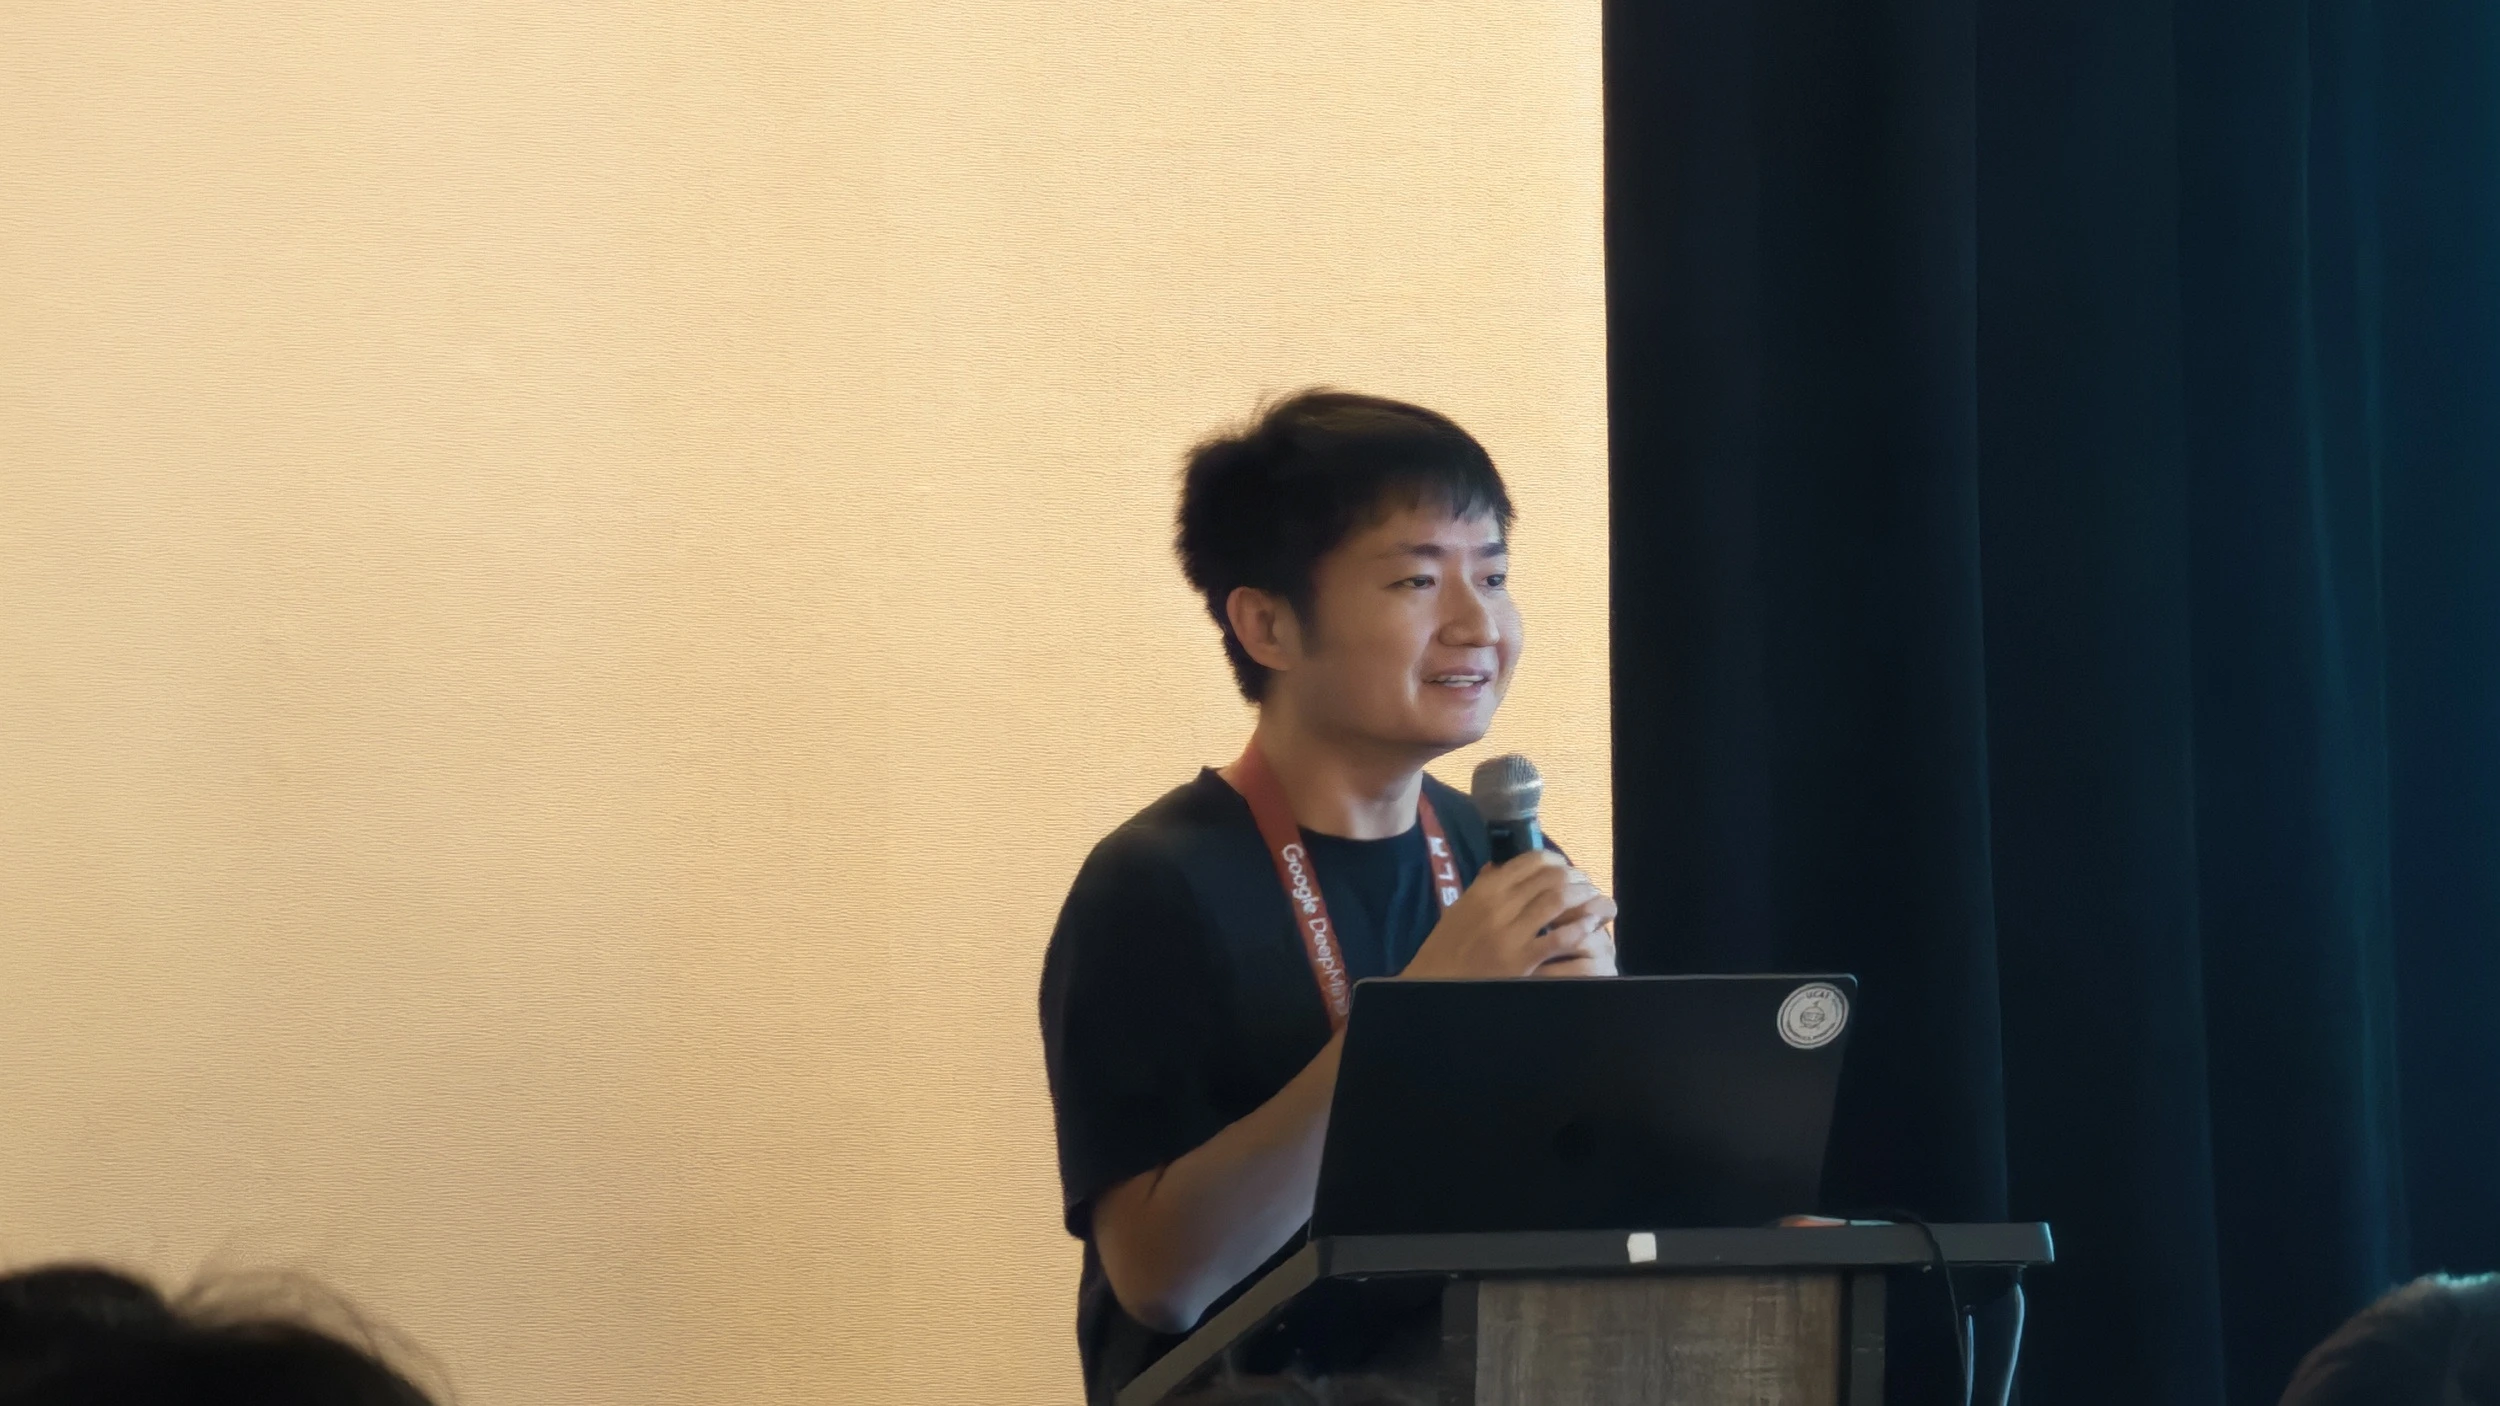
Guanya Shi: Agents Expected to Unify Model-Based and Model-Free Approaches | CoRL 2026
At the Agentic Robotics workshop at CoRL 2026 on November 12, Carnegie Mellon University's Guanya Shi presented research on agentic self-improvement, demonstrating how agents can unify model-based and model-free approaches through real-world and simulation-based auto-research.
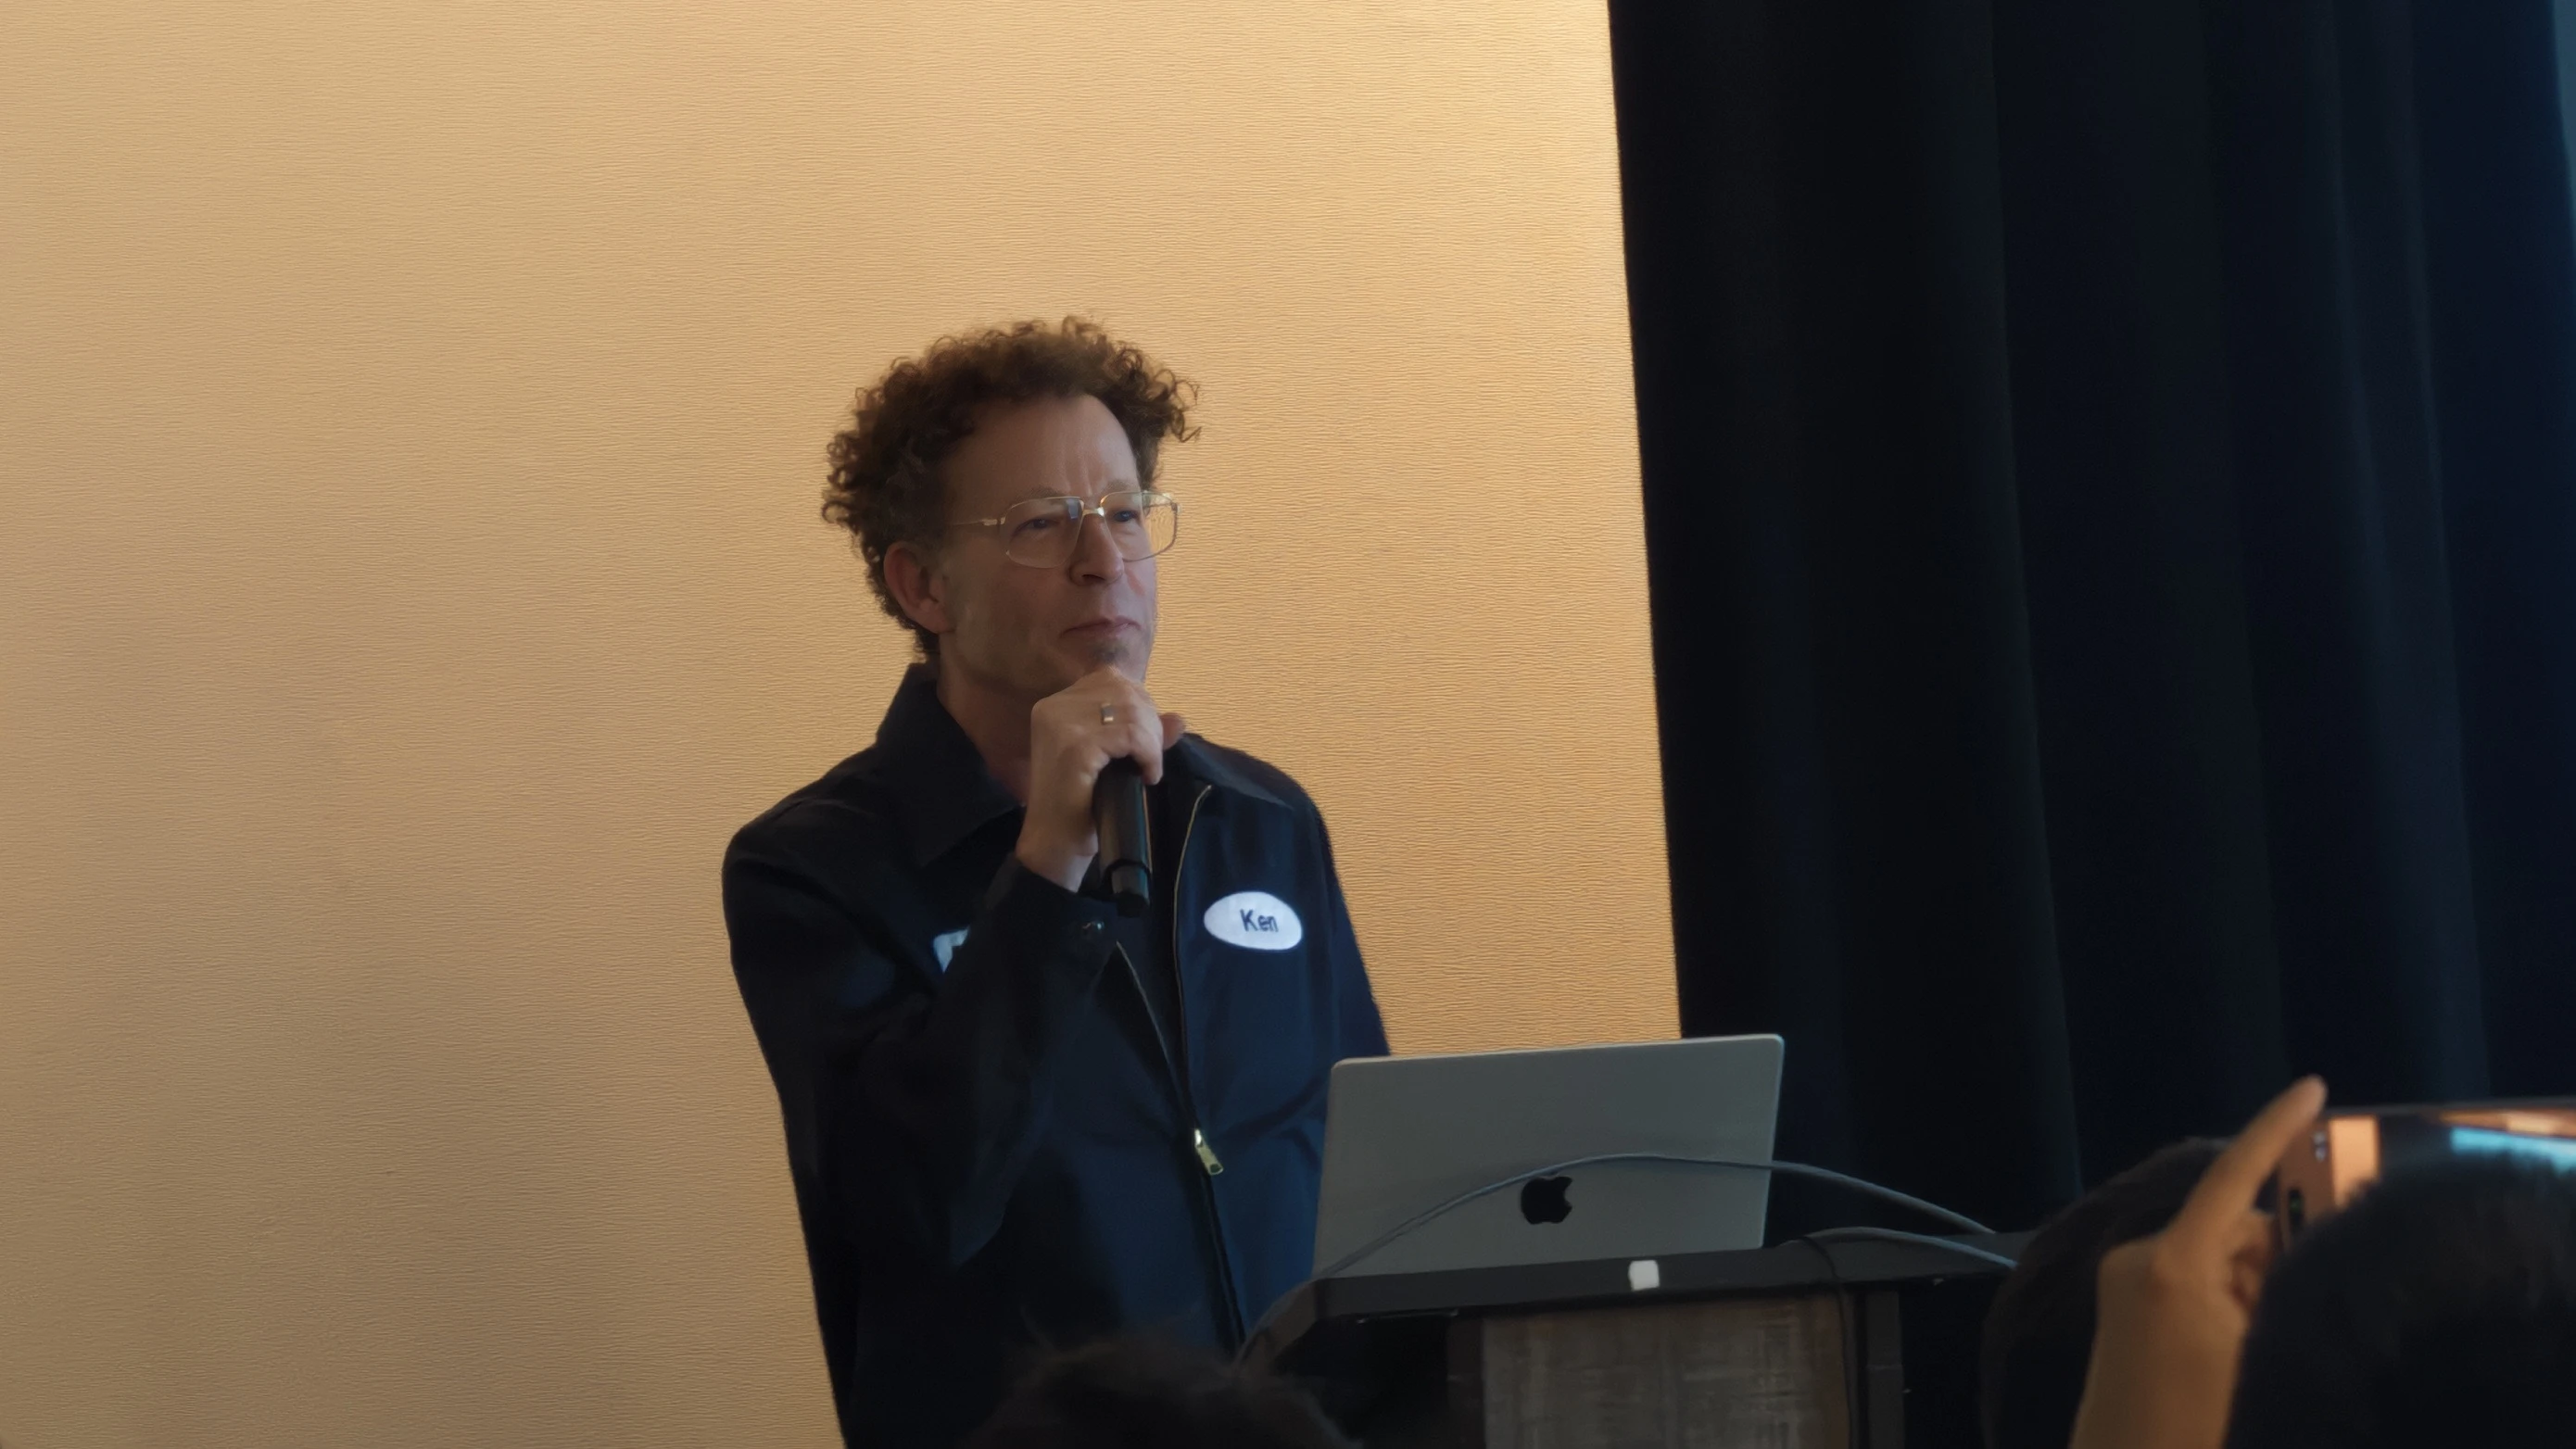
Ken Goldberg: Can Agentic Robotics Close the Reliability, Speed, and Explainability Gap?
At the CoRL 2026 Workshop on Agentic Robotics, UC Berkeley's Ken Goldberg argued that both model-based and model-free robotics approaches have hit plateaus in reliability and explainability, and presented his lab's Graph-as-Policy framework as a potential path toward industrial-grade variational automation.
Yunzhu Li: World Models Must Be Controllable to Train and Evaluate Robots | CoRL 2026
At the "Do Robots Need World Models?" workshop at CoRL 2026 on November 12, Columbia University's Yunzhu Li argued that world models must be highly controllable to serve as scalable data sources for robot training and policy evaluation.