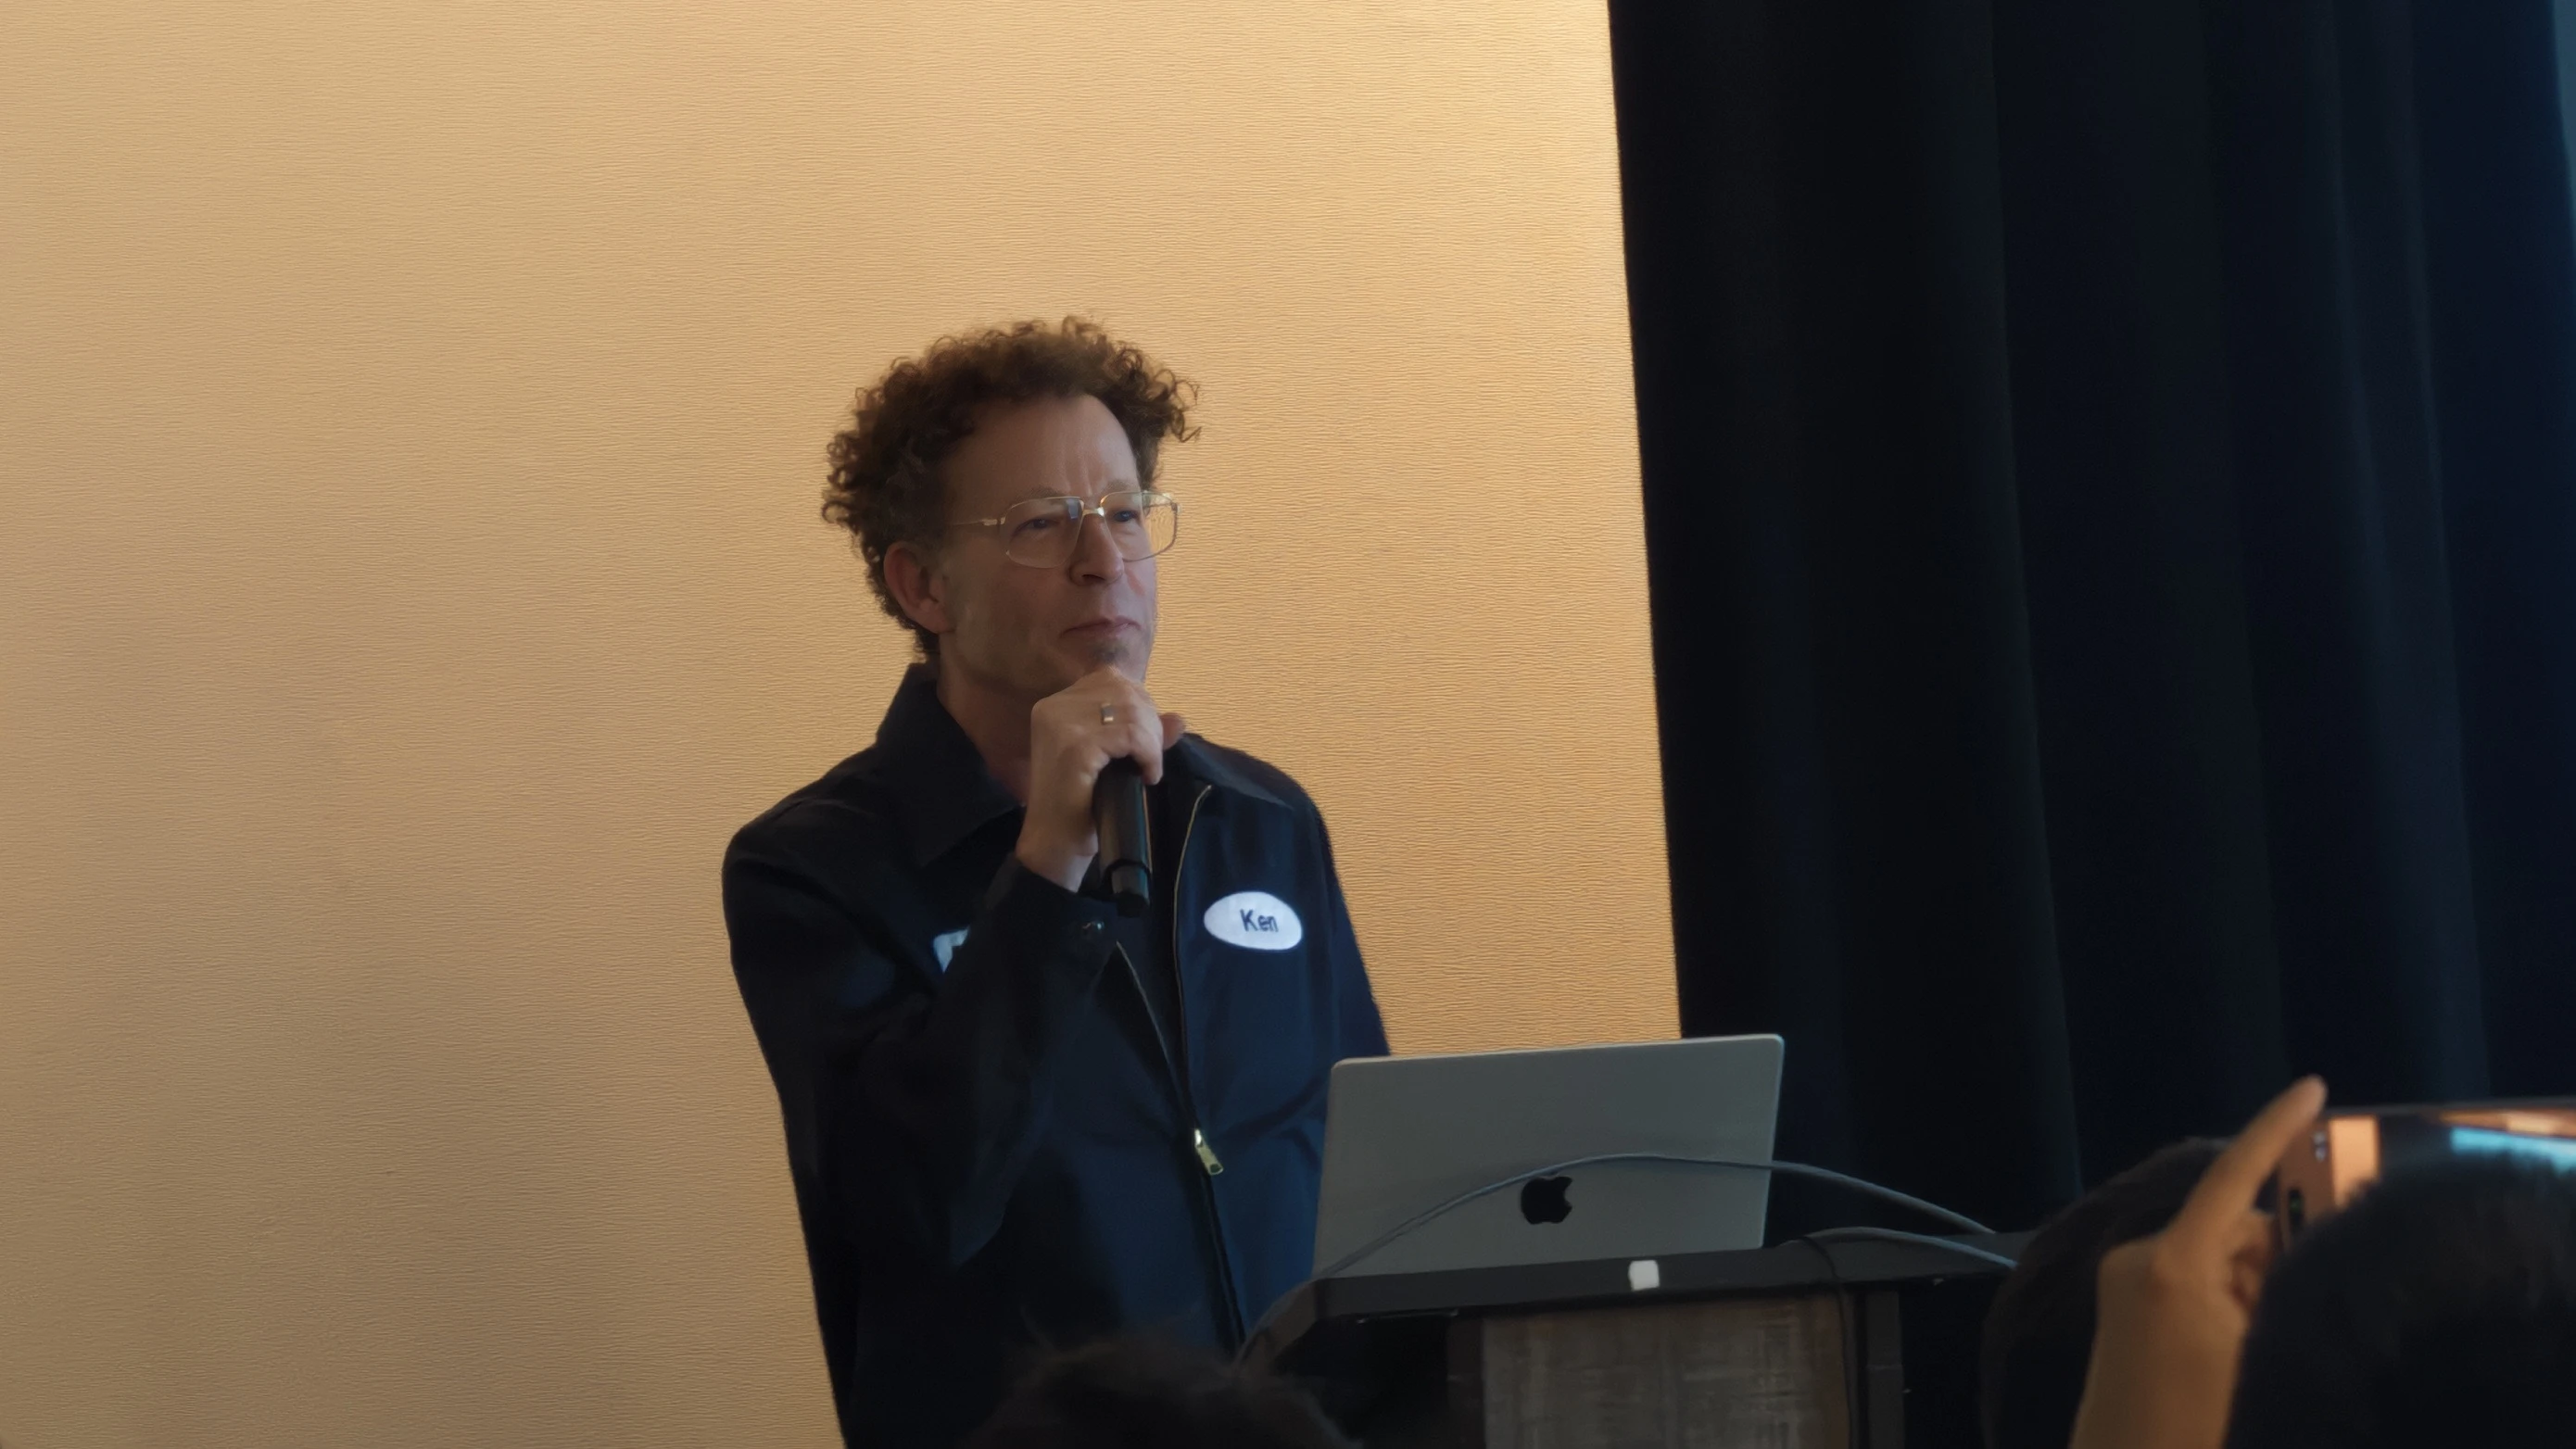
Ken Goldberg: Can Agentic Robotics Close the Reliability, Speed, and Explainability Gap?
At the CoRL 2026 Workshop on Agentic Robotics, UC Berkeley's Ken Goldberg argued that both model-based and model-free robotics approaches have hit plateaus in reliability and explainability, and presented his lab's Graph-as-Policy framework as a potential path toward industrial-grade variational automation.