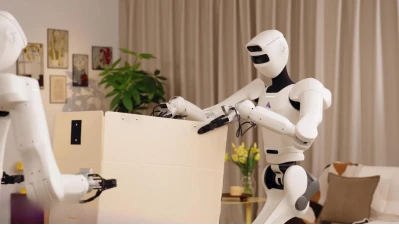
Astribot Unveils CoMind Framework for Proactive Multi-Robot Collaboration
Released on November 13, the CoMind framework addresses field-of-view occlusions in multi-robot tasks by enabling robots to proactively filter and share task-relevant context, bypassing the need for centralized control or raw data transmission.