Li Xiang Qi Che’s ME-Dex 1.0 Predicts Future Tactile States Alongside Visual Frames
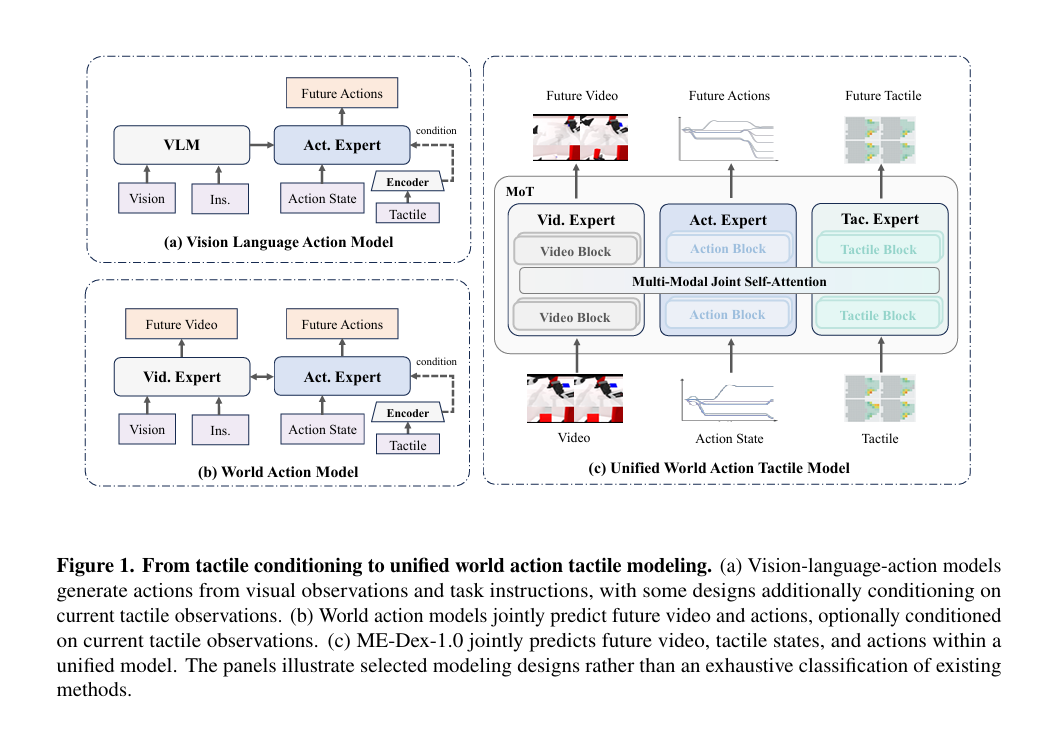
Li Xiang Qi Che’s foundation model team released ME-Dex 1.0, a world action model that treats tactile sensing as a parallel prediction target to video. By aligning heterogeneous tactile data from five different hands into a unified representation, the system significantly improves success rates in high-contact dexterous manipulation tasks.