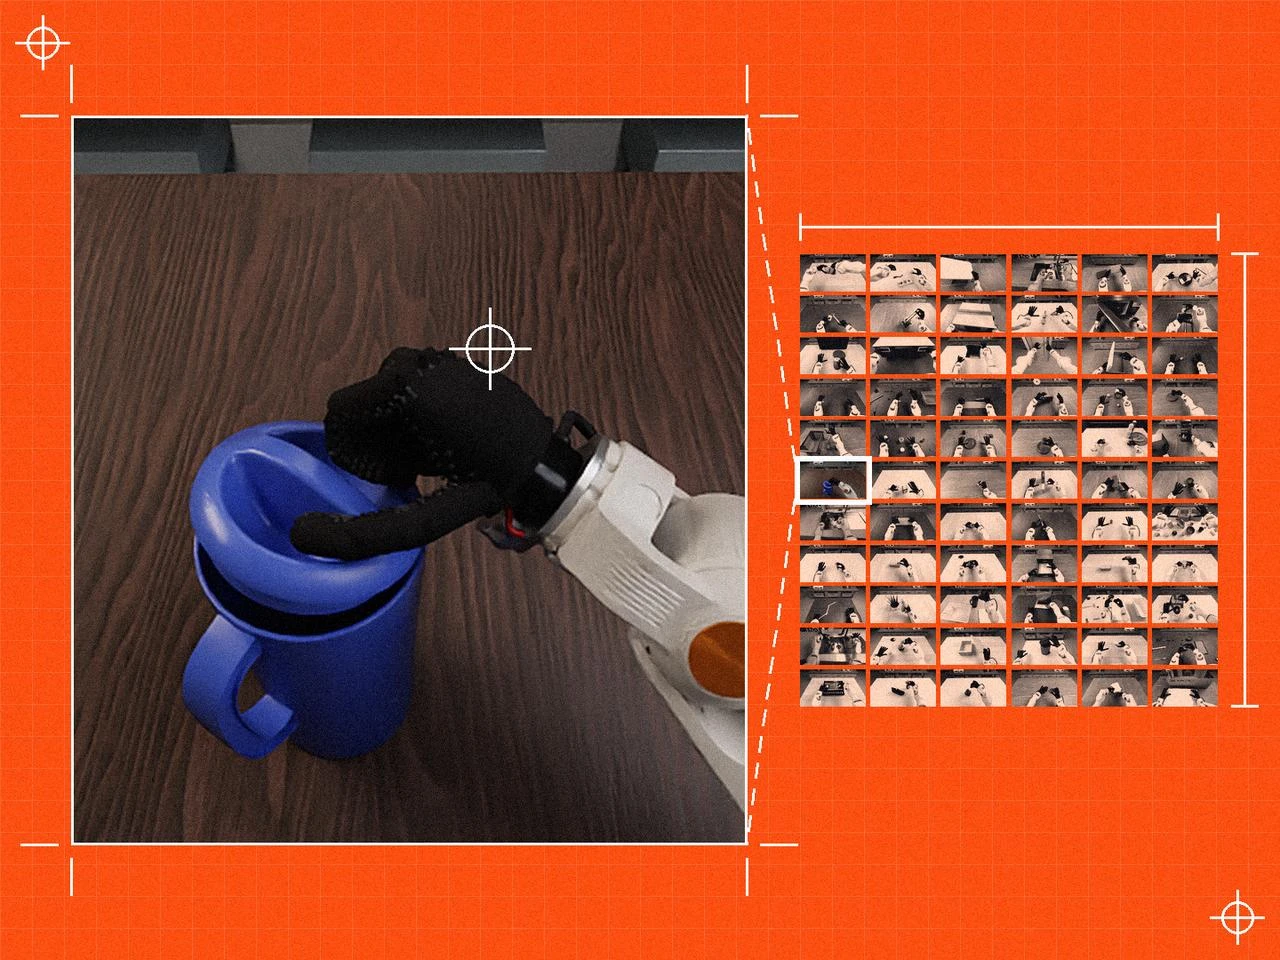
Tsinghua University Releases HandsOn Simulation Benchmark for Dexterous Manipulation with 18,000 Demonstrations
Most mainstream robot manipulation benchmarks focus on two-finger grippers, leaving five-finger dexterous hands under-evaluated with inconsistent metrics. To address this, researchers from Tsinghua University, Beijing University of Posts and Telecommunications, Natural Will, and Peking University have introduced HandsOn, a large-scale simulation benchmark featuring 66 tasks and 18,000 human teleoperation demonstrations.