Qiyuan Embodied Research Center Unveils PrimeSim, Exploring Video Generation Models for Robot Simulation
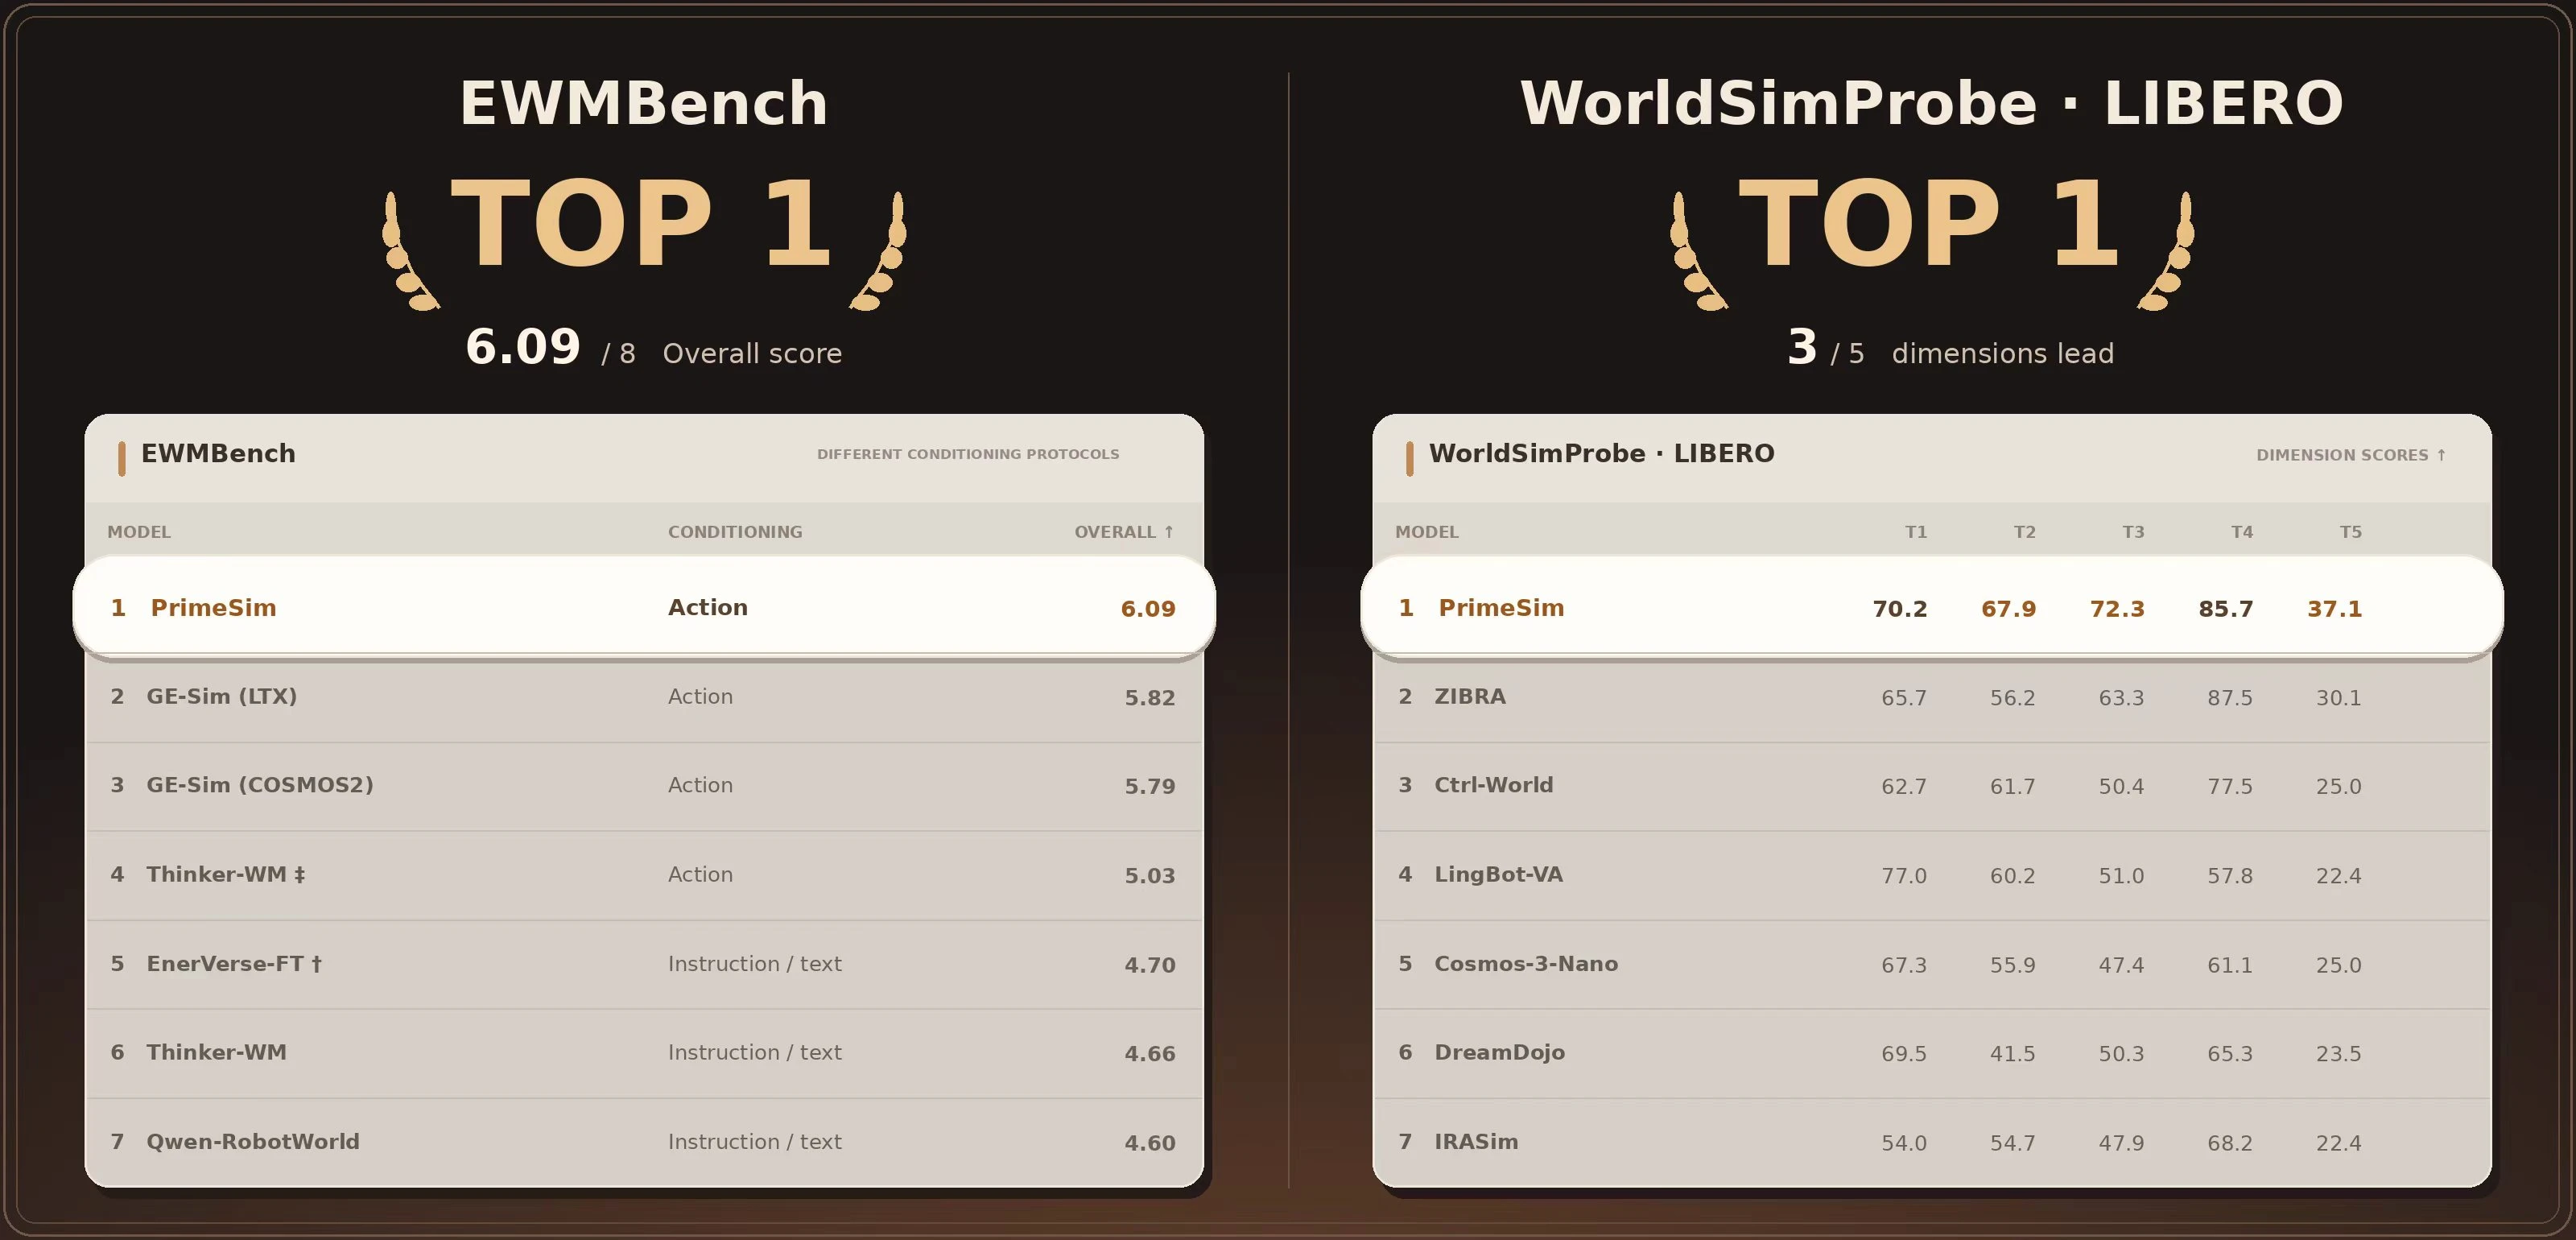
On November 4, Qiyuan Embodied Research Center released PrimeSim, a world model simulator for robot manipulation policy training built on a pretrained video generation model. The team plans to open-source the model weights, inference code, and training code on November 6.