HAF-VLA Enables Hierarchical Generation of Coordinated Full-Body Actions in Humanoid Robots
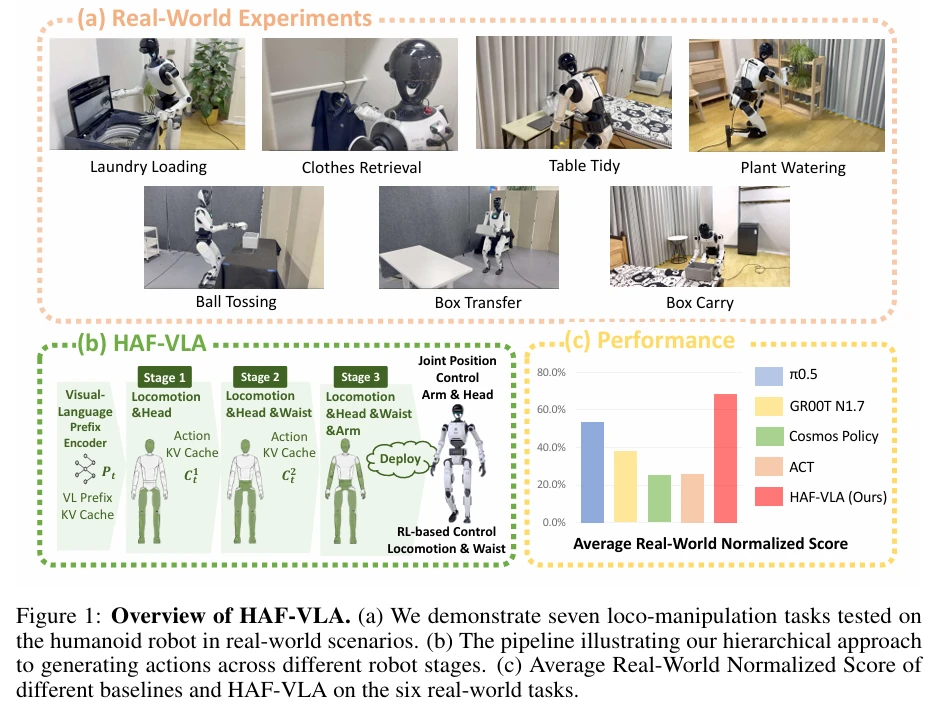
A joint team from Peking University, Tsinghua University, and other institutions has proposed HAF-VLA, a hierarchical framework that enables humanoid robots to generate coordinated full-body actions by sequentially planning movements along the kinematic chain to avoid compensatory instability.