NVIDIA and MIT Researchers Show Long-Context Robotics Requires Autoregressive World Models
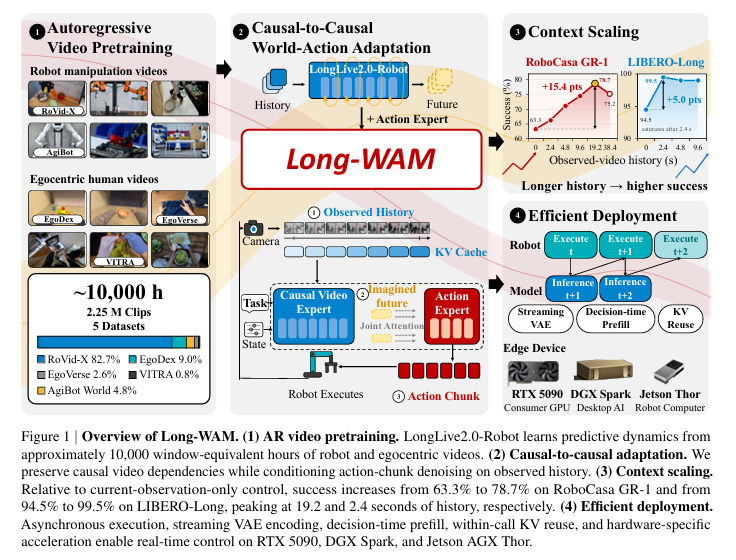
A joint paper from NVIDIA, MIT, HKU and UCSD demonstrates that simply extending visual history does not improve robot control; the model must first learn autoregressive prediction to effectively use long contexts. On the RoboCasa GR-1 platform, task success rates rose from 63.3% to 78.7% when context was extended to 19.2 seconds.