AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
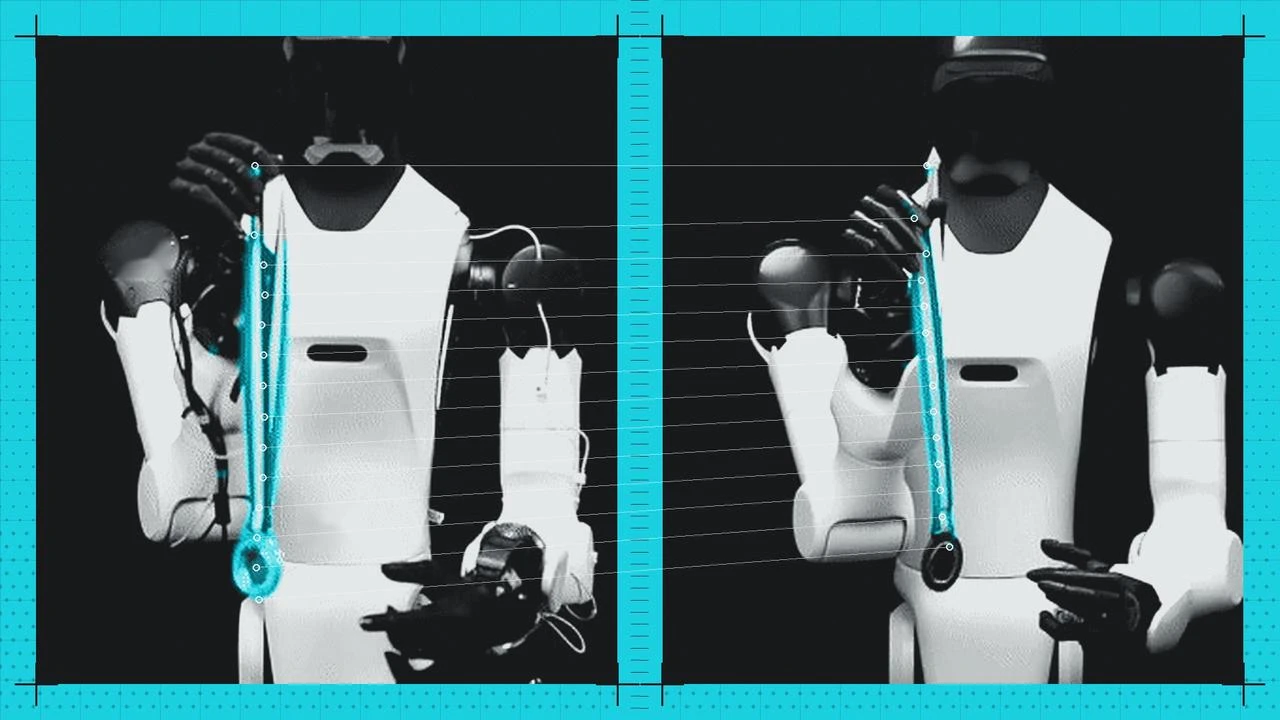
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.