Embodied AIRobotics Dexterous HandsMultimodal FusionHuman-Robot InteractionRobot ManipulationTactile PerceptionInstinct-Driven
Tactile Sensing
2 related stories
Purdue Team's IROS Best Paper Nominee: Active Palm and Multimodal Sensing in a Three-Finger Robot Hand
Yuhao Zhou and team from Purdue University present the VTAP Gripper, a three-fingered robot hand that achieves complex manipulation by making the palm active and multimodal. The design challenges the trend of adding fingers, proving that dexterity can come from effective use of existing contact surfaces rather than increased degrees of freedom.
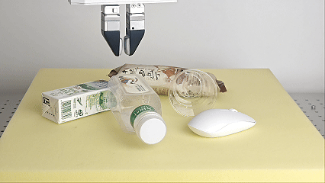
Oakfruit Robotics Unveils 'Instinct-Driven' Bottom-Up Approach for Embodied AI
Oakfruit Robotics has released its 'instinct-driven' technical route for Embodied AI, adopting a bottom-up approach where robots acquire operational instincts at the foundational level and autonomously emerge with intelligent manipulation through interaction with the physical world.