
World Action Model
3 related stories
LiberAI Launches Liber-0 to Transfer Human Action Experience to Robots
On November 4, physical world model startup LiberAI released its world action model, Liber-0. The model was pretrained on more than 2.2 million hours of human experience data. The team evaluated its zero-shot performance on 60 manipulation tasks proposed by GPT-6, conducting 600 test rounds across three categories of 20 tasks each, with every task repeated 10 times.

Copper-Policy Replaces Pixel Prediction With Compact Latent Representations for Robot Control
The Copper-Policy model jointly learns compact latent world representations and action policies, bypassing the heavy computational cost of pixel-level video prediction. First author Zexin Feng from The University of Hong Kong explains how this asymmetric architecture achieves robust control without extensive embodied pre-training.
Five Universities and Knowin AI Release AffordanceWAM to Bridge Human Video and Robot Training via Affordance Prediction
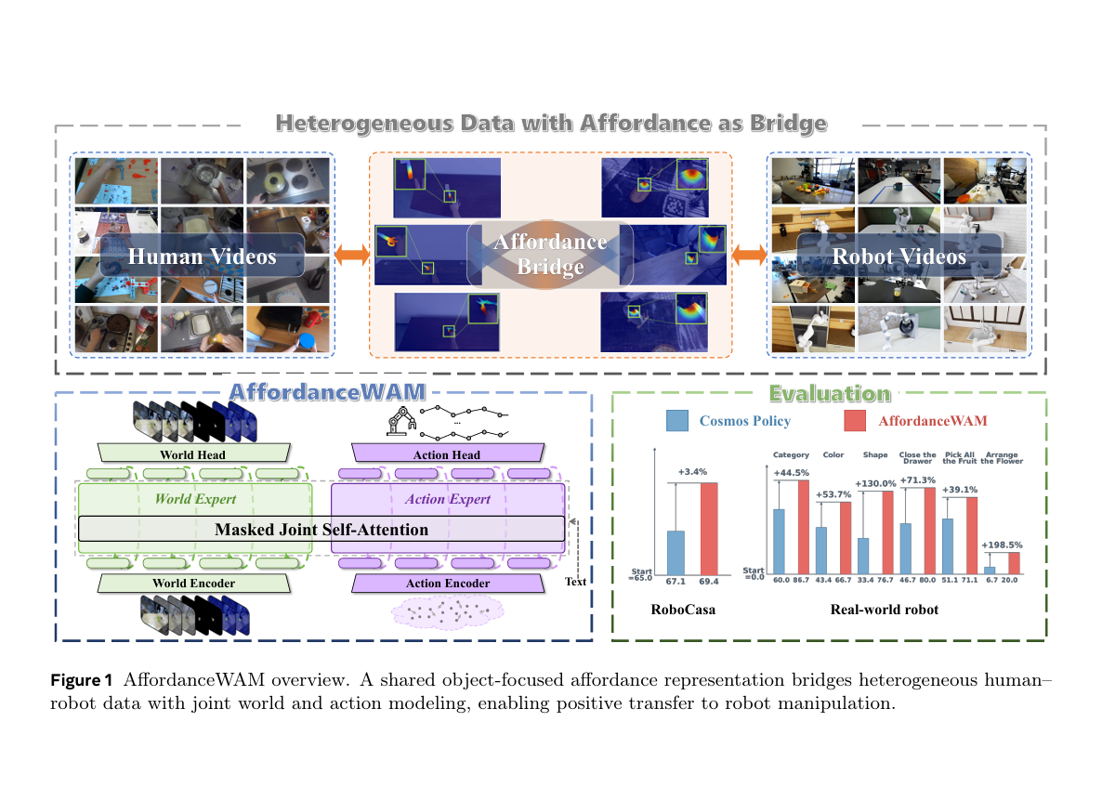
A joint team from five universities and Knowin AI introduces AffordanceWAM, a world-action model that uses explicit affordance prediction to align human video data with robot training, resolving long-standing semantic mismatches in embodied AI.