
World Model
15 related stories
Xinghai Tu's Zhao Xing: The Next Scaling of Robots Will Not Only Occur in Pre-training
At the 2026 WRC Forum, Xinghai Tu Chief Scientist Zhao Xing argues that Embodied AI's next scaling depends not just on pre-training data and models, but on continuous learning from real-world operations through post-training and true-machine reinforcement learning.
Yann LeCun Praises INTACT: ZJU’s Sun Junhan and Tsinghua’s Zhao Hao Eliminate the 'Search Tax' from JEPA World Models
Researchers propose INTACT, a search-free world model framework that aligns physical and goal intentions using a shared operator. Achieving 95.33% success rate with 300x faster inference than LeWM, it upgrades JEPA from prediction to deployable control.
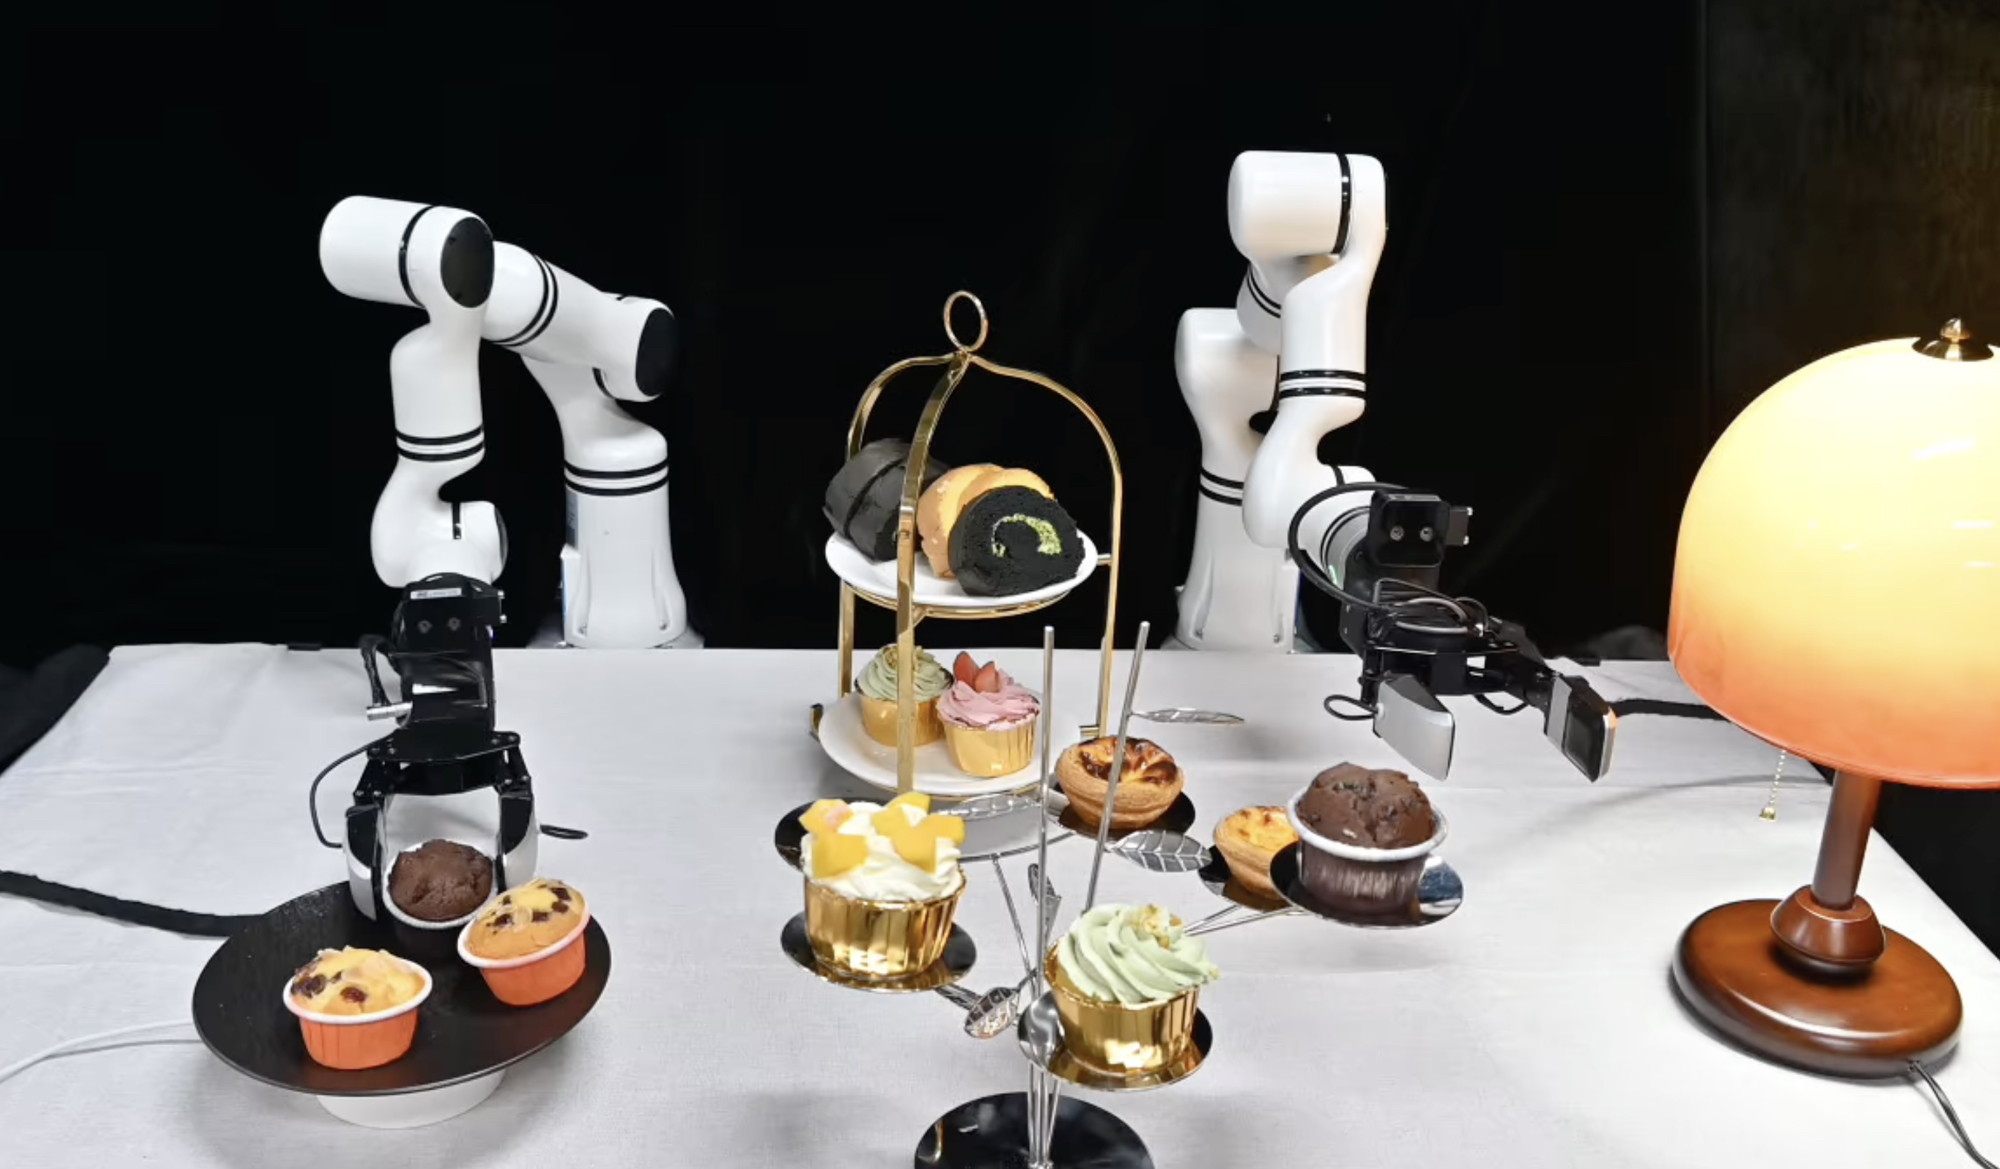
500,000 Hours of First-Person Video: How to Add 'Touch' to Embodied World Models
Zhiwu Wujie releases Being-H0.8, a latent tactile world-action model trained on over 500,000 hours of first-person video. By generating pseudo-tactile labels from visual data and unifying robot sensor inputs, it aims to bridge the gap between visual observation and physical contact for embodied AI.

Open-Sourcing Three Major Models: Tencent Robotics Is 'Overtaking'
Tencent's Robotics X Lab and Futian Lab, in collaboration with Hunyuan, have released three open-source embodied AI foundation models based on the Hunyuan large model: Hy-Embodied-VLM-1.0, Hy-Embodied-RxBrain-1.0, and Hy-Embodied-VLA-0.5.

Chatting with Wang Xiaofeng on Gigaworld-1: When World Models Become the Physical Referees for Embodied AI
As physical evaluation bottlenecks slow down embodied foundation model iteration, Flexiv and Tsinghua University release GigaWorld-1, using world models as evaluators to reduce reliance on real-world robot testing. Wang Xiaofeng discusses how this approach can accelerate development cycles.
Beyond Prediction: Xiaomi Turns World Models into Data Engines
Xiaomi has open-sourced U0, a 38B-parameter multimodal model that integrates five embodied synthesis functions. By treating embodied generation as a natural extension of foundation models rather than domain-specific fine-tuning, U0 acts as an expandable data engine, significantly enhancing robot generalization in real-world scenarios.
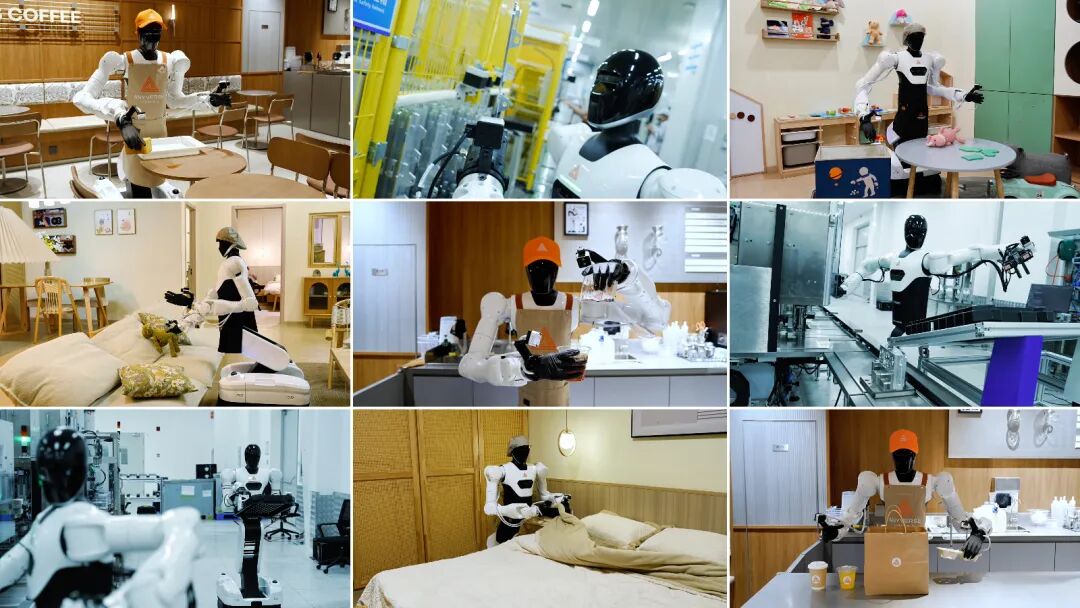
After Raising Hundreds of Millions in Funding, Top Rankings Achieved: WuJie Dynamics Releases MWA Latent Space World Model
WuJie Dynamics officially released the MWA Embodied General Brain, a latent space world model based on long-horizon bidirectional physical causal chains, and topped the RoboCasa GR1 TableTop leaderboard. The company recently completed a $200 million angel round.
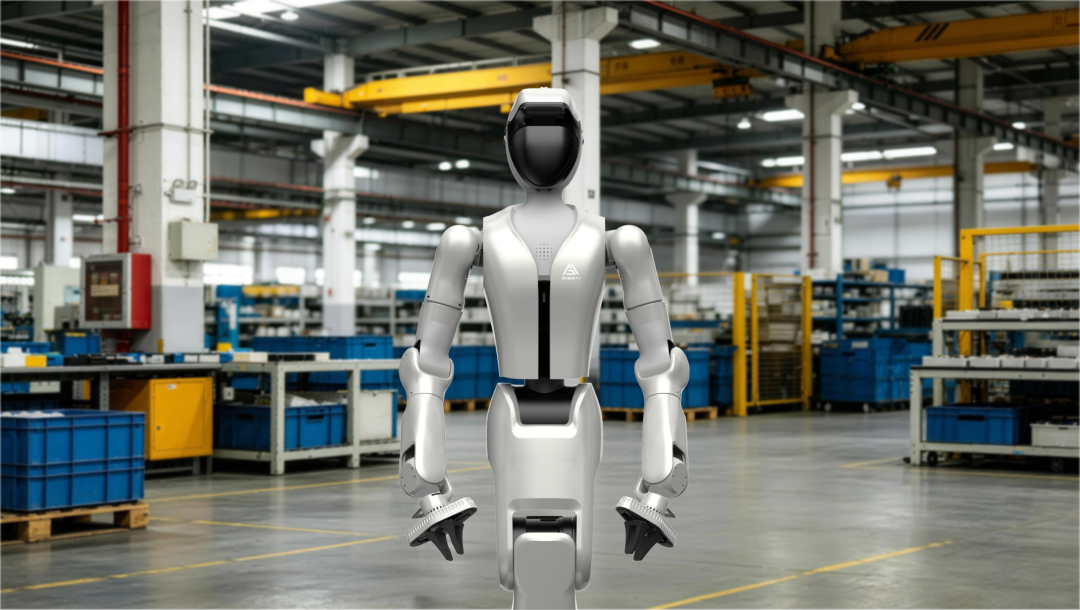
JiJia Vision Secures Another 1 Billion RMB in Funding: How World Models Are Entering Homes and Factories?
JiJia Vision has completed a 1 billion RMB B2 round of financing, bringing its total funding to 3.5 billion RMB in just three months. The company is leveraging its "Dual Pyramid" data and algorithm system to deploy embodied AI with world models in both C-end home scenarios and B-end industrial applications.
After Valuation Exceeds 10 Billion, This Robotics Company Unveils the 'Fastest' World Model
StarSeaMap's Fast-WAM boosts robot reaction speed by 4x by decoupling training from inference, proving world models rely on implicit physics understanding rather than explicit future video generation.
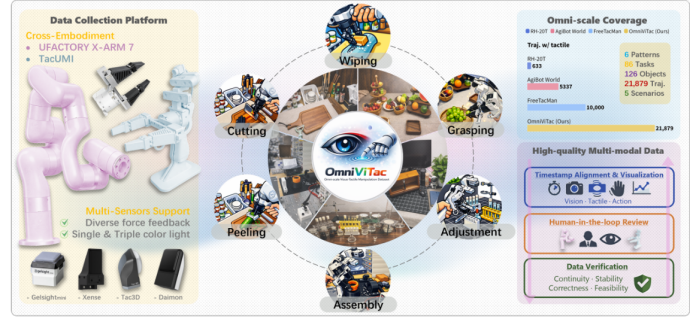
ItStone Zhihang and Six Institutions Release OmniVTA Vision-Tactile World Model
ItStone Zhihang, in collaboration with six institutions including NUS and Tsinghua University, releases the OmniVTA framework and OmniViTac dataset, enabling robots to transition from passive perception to active tactile prediction and closed-loop control for dexterous manipulation.

Sklid AI Raises Approximately $9.8 Billion in Series C; 1X Unveils World Model Progress; ZhiJi Dynamics Releases Embodied AI Agent System | Weekly Tech Roundup
Sklid AI completes a $1.4 billion (approx. 9.8 billion RMB) Series C round led by SoftBank, raising its valuation to over $14 billion. Meanwhile, 1X introduces its generative world model 1XWM for robotic autonomy, and ZhiJi Dynamics launches COSA, an embodied agent OS for humanoid robots.

1X Unveils Latest Progress on World Model: Can NEO Robot Successfully Enter Homes?
1X has released 1XWM, a generative world model pre-trained on internet videos, to enhance NEO's autonomous capabilities and accelerate its deployment in household environments.