World Models
19 related stories
Tactile sensing emerges as the next critical data modality for robot learning at IROS 2026
At IROS 2026 in Pittsburgh, sessions on tactile sensing were fully packed, highlighting a critical gap: while vision records appearance and motion, it cannot capture contact physics. Researchers from MIT, Columbia University, and Amazon presented low-cost sensors and human-demonstration methods to scale tactile data collection.
RIMBOT Unveils Physical RSI Framework, Targets Industrial Validation
RIMBOT, a robotics startup founded in March 2026, is deploying its Physical Recursive Self-Improvement framework in industrial ICT testing lines. Co-founder Yuanxin Zhong explains why factories offer the necessary failure data and infrastructure to move beyond zero-shot generalization toward continuous real-world learning.
Tsinghua and Peking University Teams Release SkelWAM for Zero-Shot Cross-Embodiment Manipulation
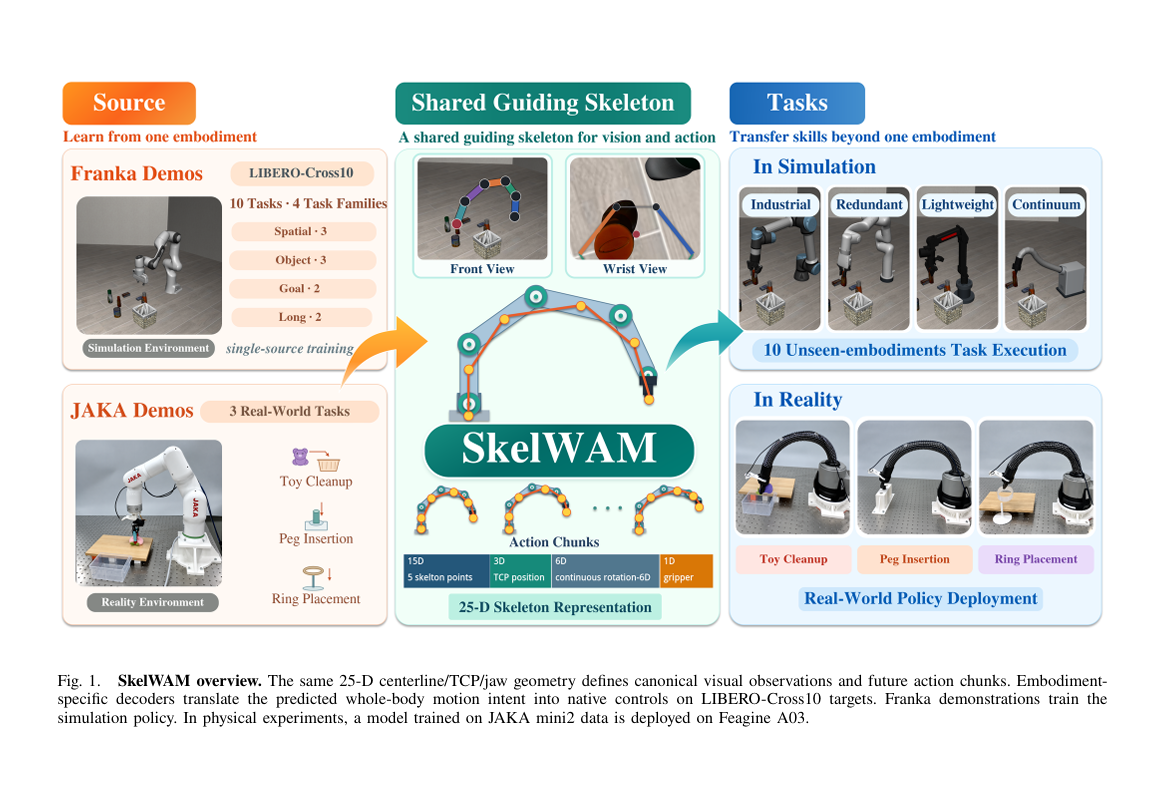
Researchers from Tsinghua University and Peking University have introduced SkelWAM, a skeleton-guided world-action model that enables zero-shot transfer of manipulation policies across ten different robotic arm structures without retraining.
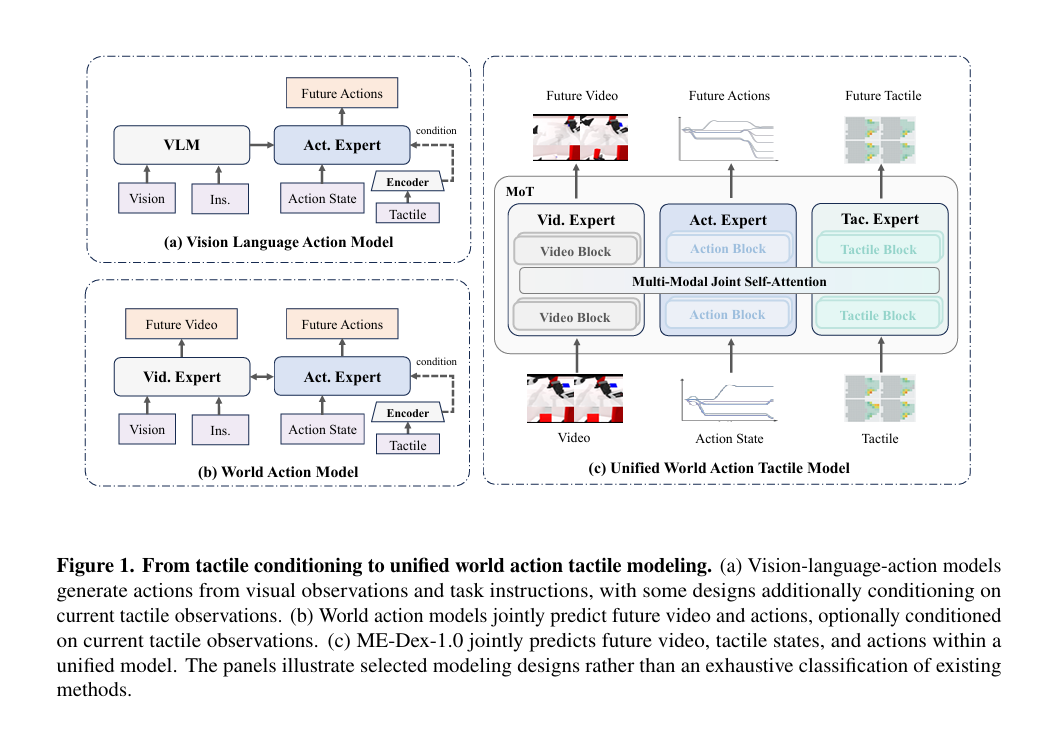
Li Auto's ME-Dex 1.0 Predicts Future Tactile States Alongside Visual Observations
Li Auto’s foundation model team released ME-Dex 1.0, a world action model that treats tactile sensing as a parallel prediction target to video. By aligning heterogeneous tactile data from five different hands into a unified representation, the system significantly improves success rates in high-contact dexterous manipulation tasks.
Galaxea's Hang Zhao: The Next Embodied AI Scaling Goes Beyond Pre-Training
At the 2026 WRC Forum, Galaxea Chief Scientist Hang Zhao argues that Embodied AI's next scaling depends not just on pre-training data and models, but on continuous learning from real-world operations through post-training and real-robot reinforcement learning.
INTACT: Search-Free World Model for Robotics Achieves Faster, More Reliable Control
Researchers propose INTACT, a search-free world model framework that aligns physical and goal intentions using a shared operator. Achieving 95.33% success rate with 300x faster inference than LeWM, it upgrades JEPA from prediction to deployable control.
How 500,000 Hours of First-Person Video Can Add 'Touch' to Embodied World Models
BeingBeyond releases Being-H0.8, a latent tactile world-action model trained on over 500,000 hours of first-person video. By generating pseudo-tactile labels from visual data and unifying robot sensor inputs, it aims to bridge the gap between visual observation and physical contact for embodied AI.

Tencent Open-Sources Three Embodied AI Models to Build a Unified Robotics Foundation
Tencent's Robotics X Lab and Futian Lab, in collaboration with Hunyuan, have released three open-source embodied AI foundation models based on the Hunyuan large model: Hy-Embodied-VLM-1.0, Hy-Embodied-RxBrain-1.0, and Hy-Embodied-VLA-0.5.

GigaAI and Tsinghua University Release GigaWorld-1 to Use World Models as Robot Evaluators
As physical evaluation bottlenecks slow down embodied foundation model iteration, GigaAI and Tsinghua University release GigaWorld-1, using world models as evaluators to reduce reliance on real-world robot testing. Xiaofeng Wang discusses how this approach can accelerate development cycles.
Xiaomi Turns World Model Into a Data Engine, Beyond Prediction
Xiaomi has open-sourced U0, a 38B-parameter multimodal model that integrates five embodied synthesis functions. By treating embodied generation as a natural extension of foundation models rather than domain-specific fine-tuning, U0 acts as an expandable data engine, significantly enhancing robot generalization in real-world scenarios.
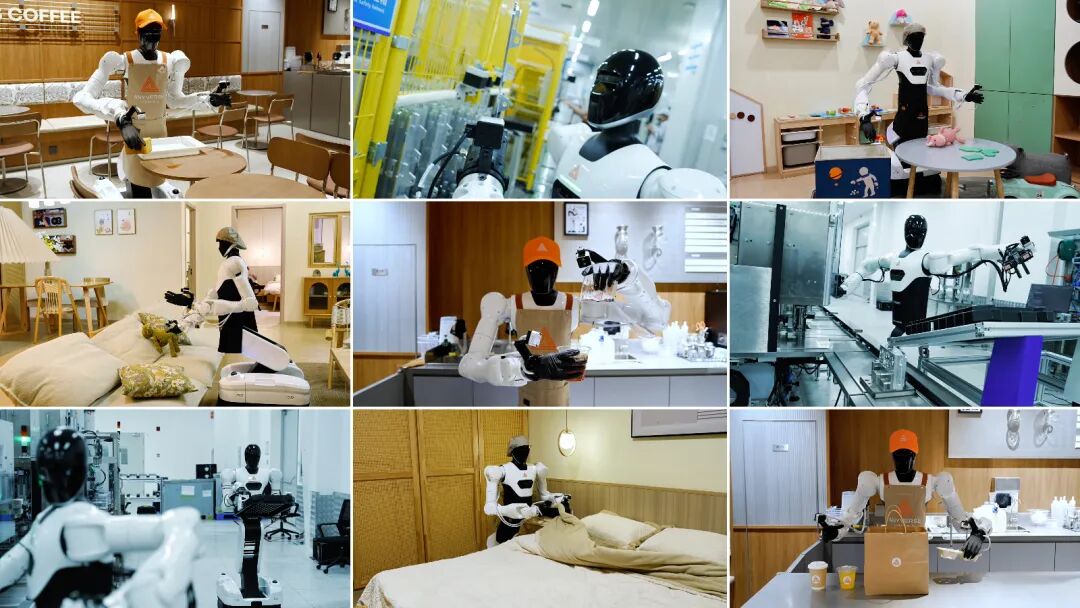
After Raising Hundreds of Millions, WuJie Dynamics Launches MWA Latent World Model
WuJie Dynamics officially released the MWA Embodied General Brain, a latent space world model based on long-horizon bidirectional physical causal chains, and topped the RoboCasa GR1 TableTop leaderboard. The company recently completed a $200 million angel round.
GigaAI Secures RMB 1 Billion in Funding to Bring World Models to Homes and Factories
JiJia Vision has completed a 1 billion RMB B2 round of financing, bringing its total funding to 3.5 billion RMB in just three months. The company is leveraging its "Dual Pyramid" data and algorithm system to deploy embodied AI with world models in both C-end home scenarios and B-end industrial applications.