

PokeBot Launches Free RoboAPI to Adapt a Single World-Action Model Across Multiple Robot Arms
On October 30, PokeBot released RoboAPI, a public interface for its proprietary Poke-Aurora world-action model, aiming to eliminate the need for repeated data collection and retraining when developers switch robot hardware.
NVIDIA Proposes ThinkWorld to Train VLAs on Unannotated Human Videos via Chain-of-Dynamics and Imagined Futures
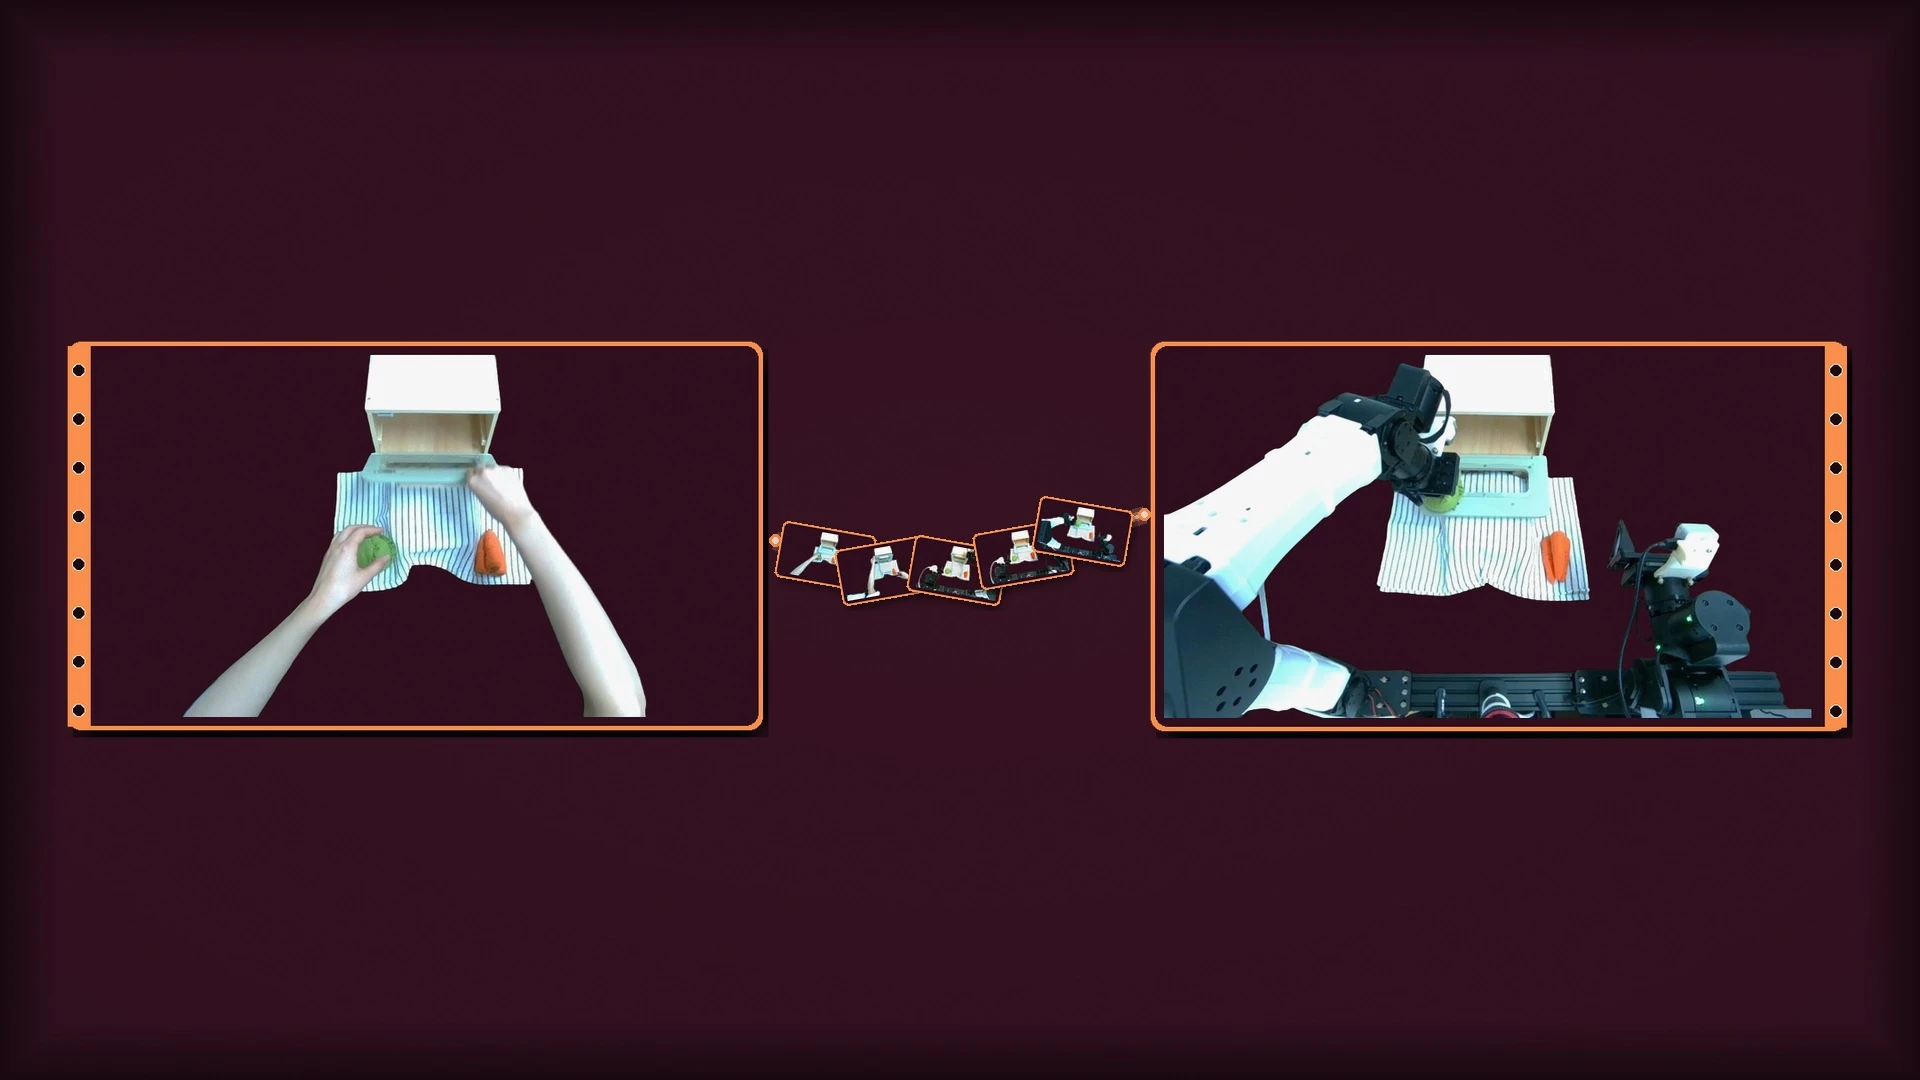
NVIDIA and KAIST introduce ThinkWorld, a vision-language action framework that leverages chain-of-dynamics reasoning and imagined future states to extract training signals from unannotated human videos for robot policy learning.
AgiBot's Rollback Method Uses World Model 'Rewind' to Surpass Human Averages in 8 Hours of Real-Robot Training
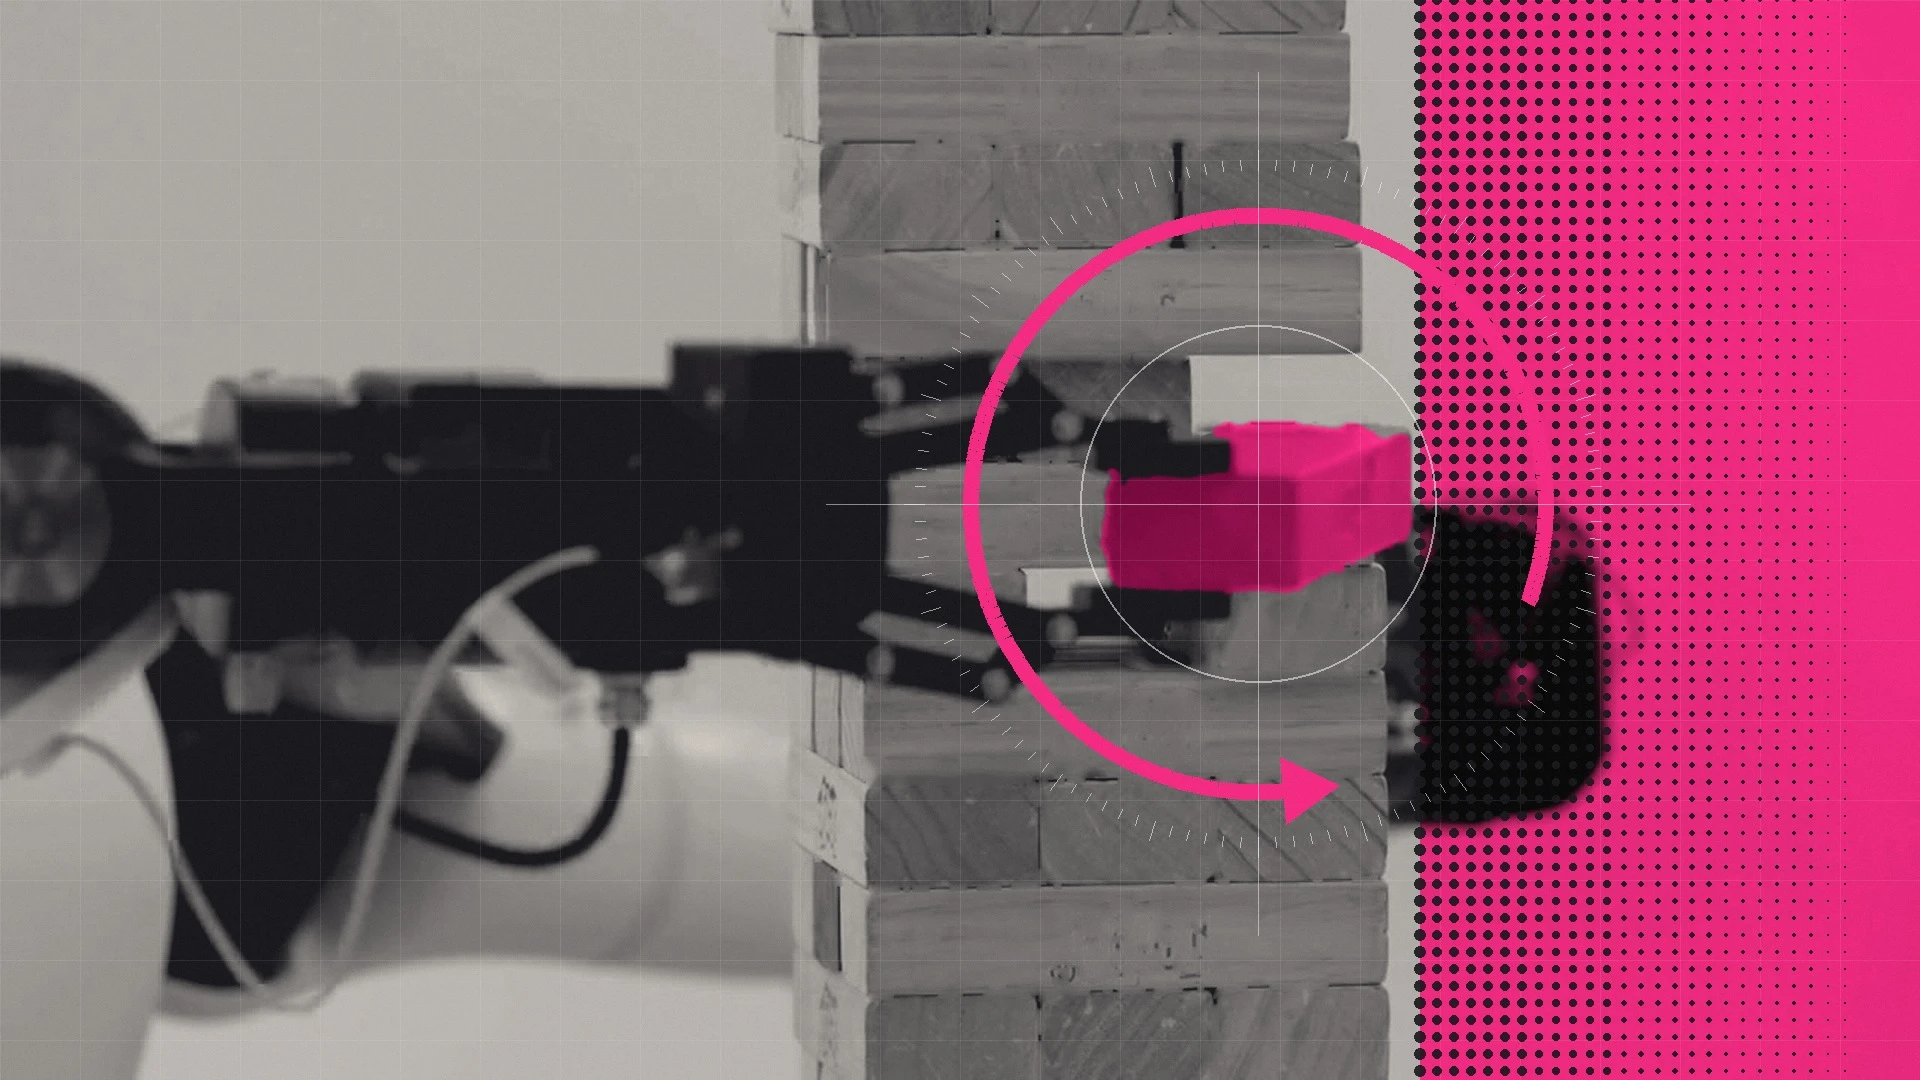
AgiBot, Beihang University, and the National University of Singapore introduced Rollback, a policy improvement method that backtracks within a world model to explore alternative actions. Trained on a single real robot for eight hours, the approach outperformed human baselines in ball tossing and tabletop curling by eliminating costly physical scene resets.
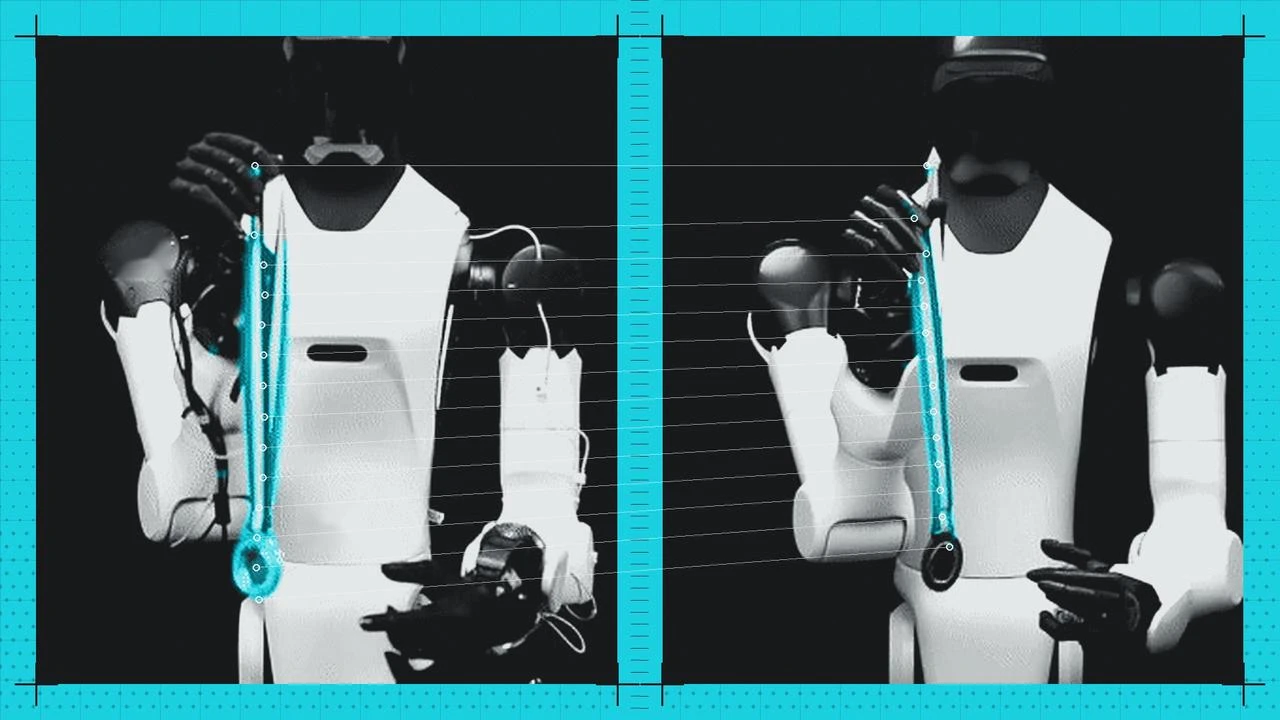
AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.
Google DeepMind Unveils Genie 4, the First World Model in the Series to Generate Native Audio
Google DeepMind has released Genie 4, a new real-time interactive world model that natively generates audio, prompting questions about how close such sounding, simulated environments are to being used for robot training.
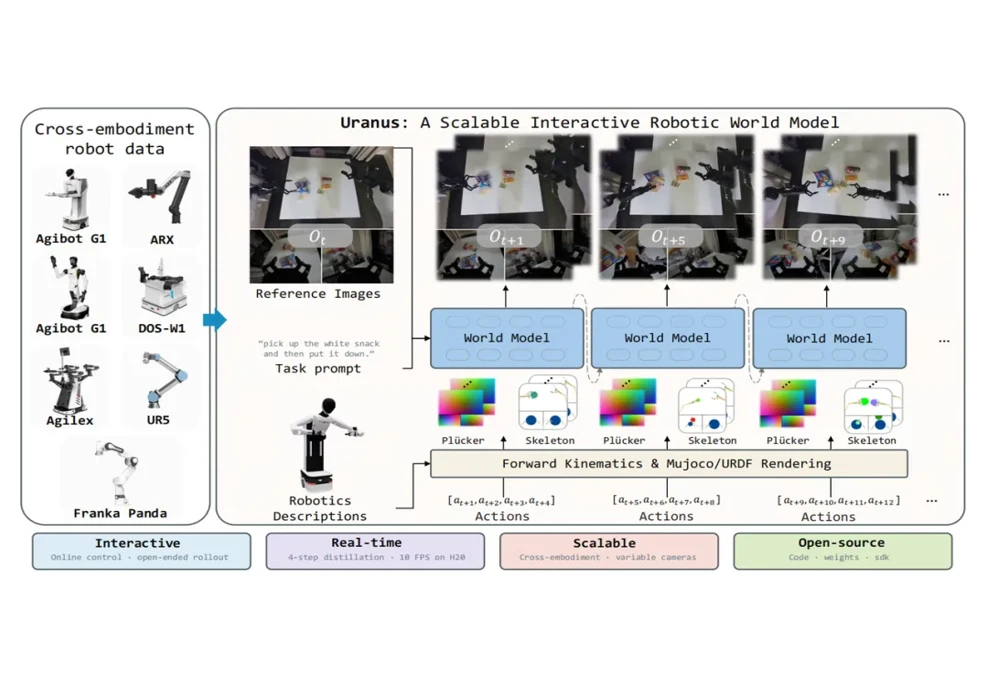
D-Robotics Open-Sources Uranus World Model Simulation Platform, Achieving 0.98 Correlation in RoboTwin Closed-Loop Evaluation
On October 27, the D-Robotics large model team open-sourced the Uranus technical report alongside its inference code, SDK, and model weights, offering 100 early access slots to developers and researchers worldwide.
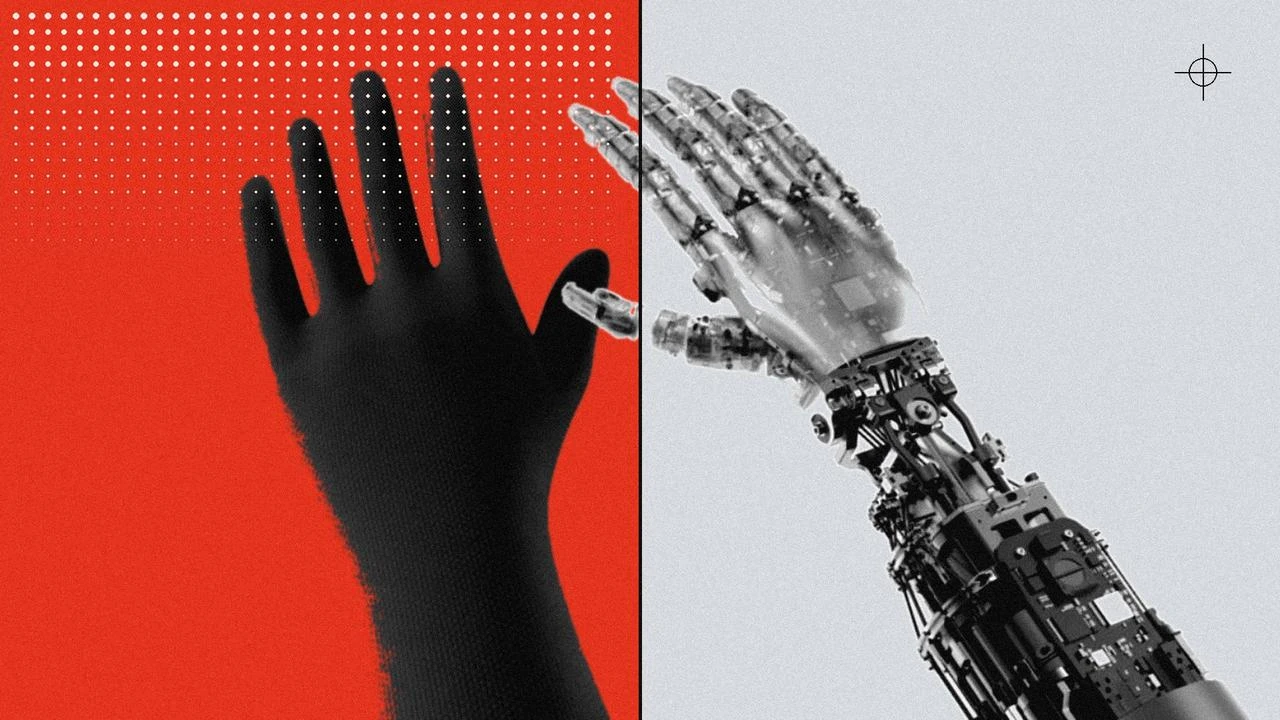
Xiaomi Unveils 21-DOF Bionic Hand Designed From 1,827 Factory SOPs
On October 27, Xiaomi Technology revealed a 21-degree-of-freedom bionic dexterous hand driven by 26 hybrid motors and equipped with 1,500 high-density tactile points across the palm. Its configuration is derived from 1,827 real-world Standard Operating Procedures at the pilot center of Xiaomi Automobile's Intelligent Manufacturing Department, which the company used to determine the optimal number of degrees of freedom.
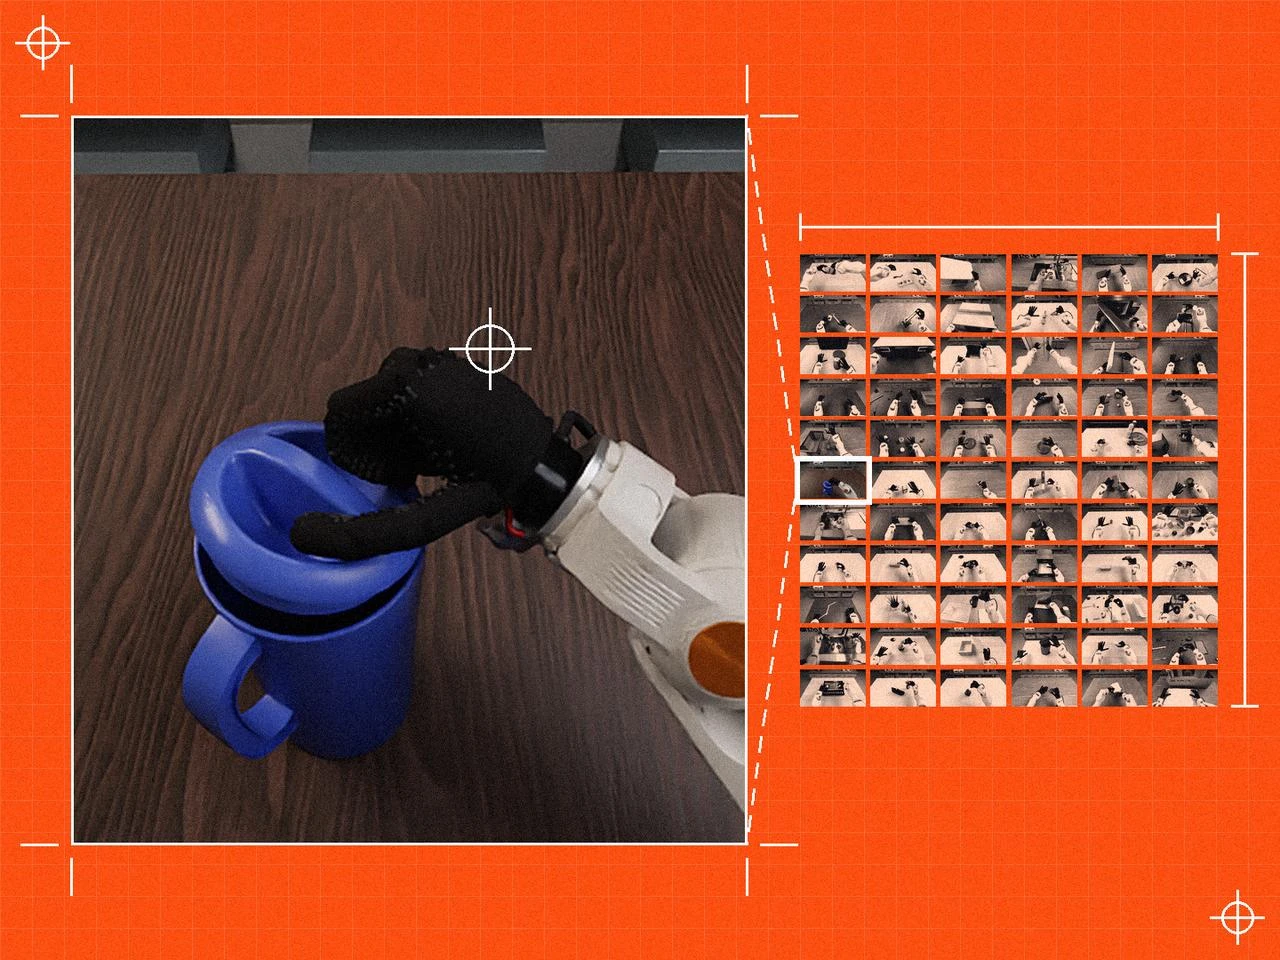
Tsinghua University Releases HandsOn Simulation Benchmark for Dexterous Manipulation with 18,000 Demonstrations
Most mainstream robot manipulation benchmarks focus on two-finger grippers, leaving five-finger dexterous hands under-evaluated with inconsistent metrics. To address this, researchers from Tsinghua University, Beijing University of Posts and Telecommunications, Natural Will, and Peking University have introduced HandsOn, a large-scale simulation benchmark featuring 66 tasks and 18,000 human teleoperation demonstrations.
Shihang Intelligence's CEORION Marine Foundation Model Completes CAC Filing for Underwater Operations
Shihang Intelligence announced that its CEORION marine general foundation model has completed filing with the Cyberspace Administration of China. Built on a Language-World-Action Model architecture, the system integrates multimodal sensor data to enable underwater robots to perceive, plan, and execute tasks within a single framework.
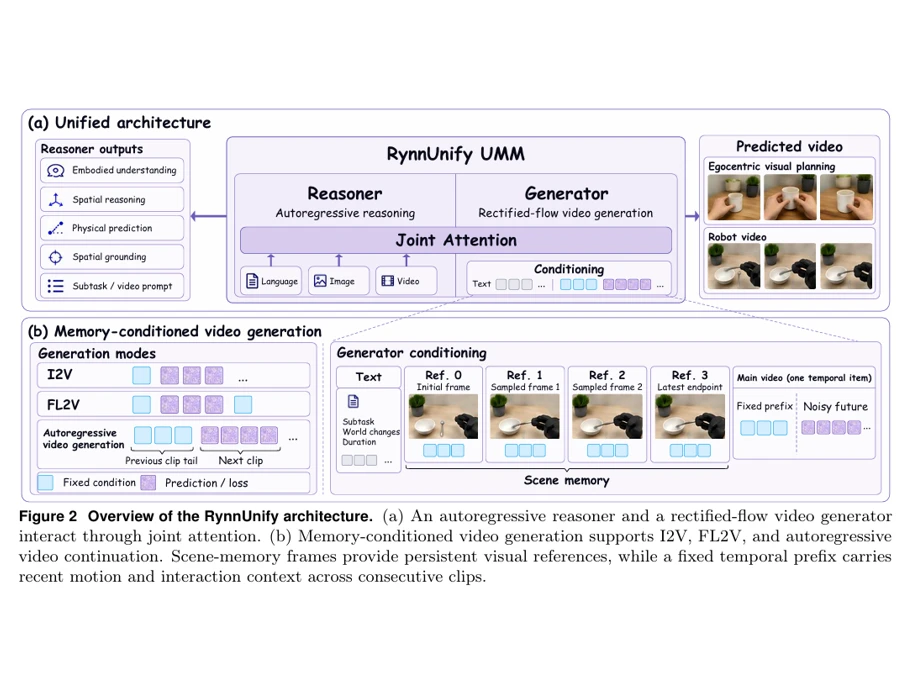
Alibaba DAMO Academy Introduces RynnUnify, a 16B Unified Embodied Model Pairing 8B Reasoning with 8B Video Generation
On October 23, Alibaba DAMO Academy and Hupan Lab published a paper on RynnUnify, a 16-billion-parameter unified embodied model that uses an 8B reasoning module and an 8B video generator to predict future scene changes and guide sequential robotic actions.
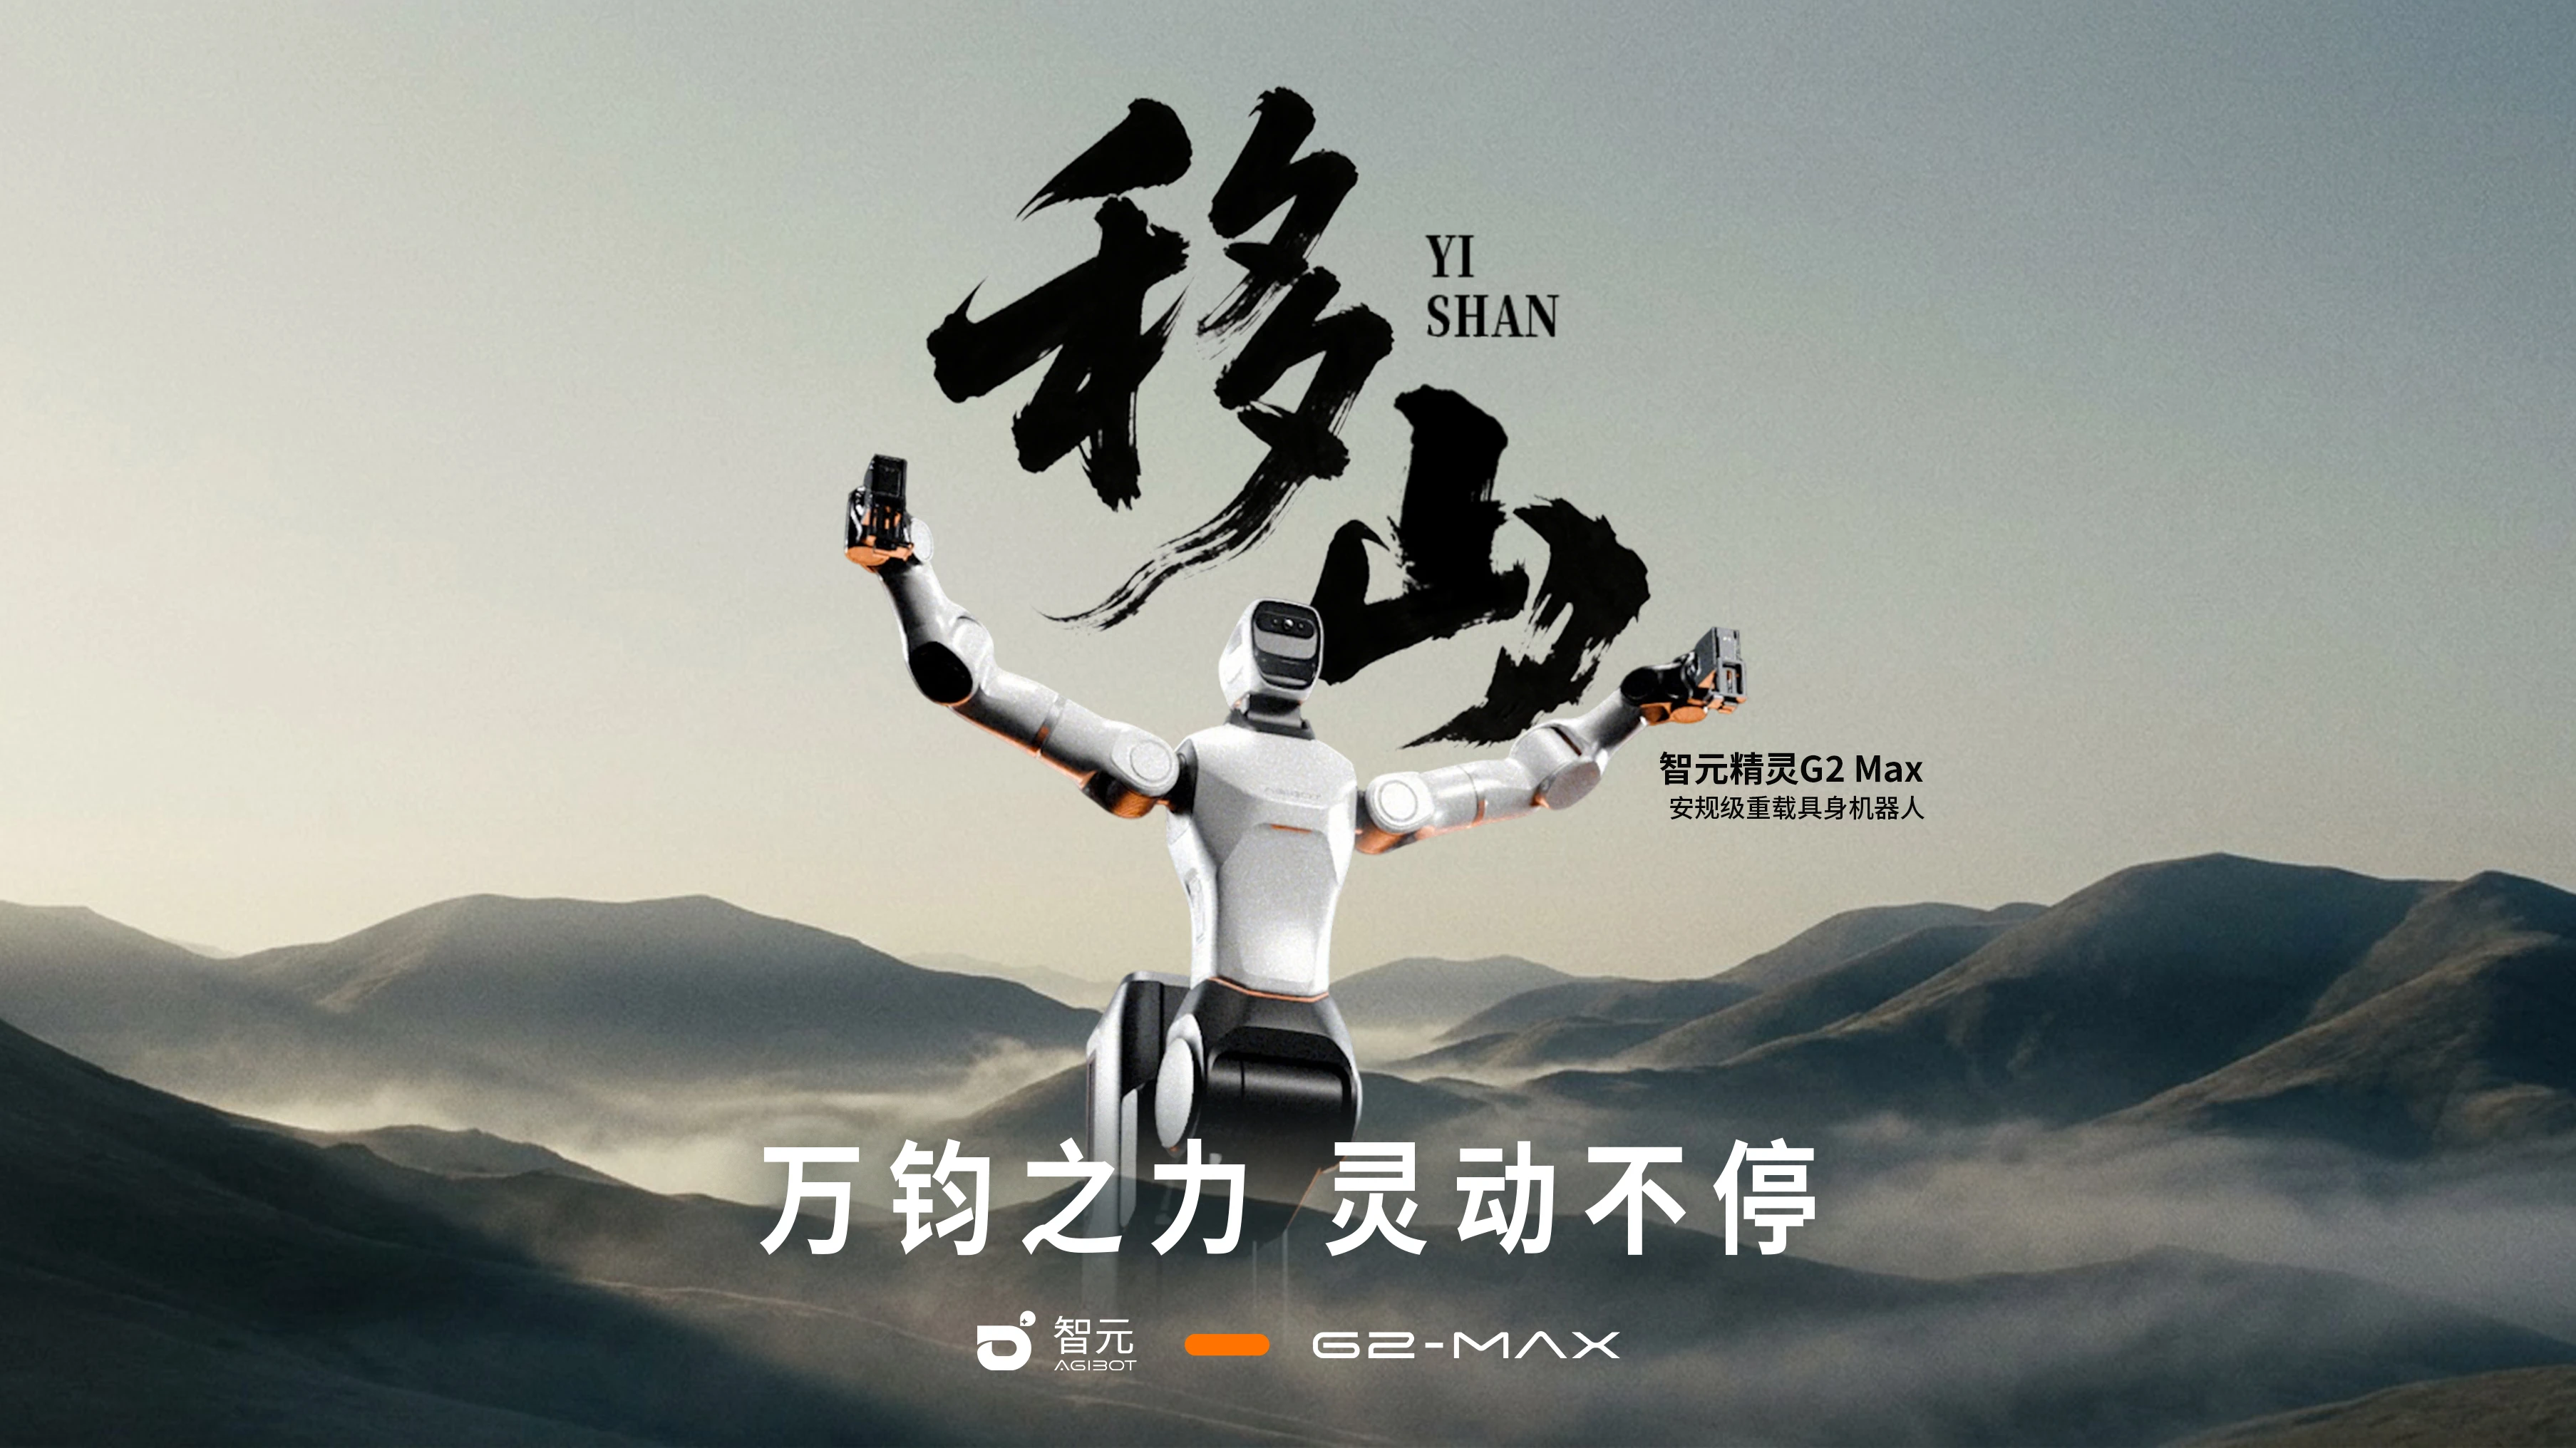
AgiBot Launches AGIBOT G2 Max, a Safety-Certified Heavy-Duty Embodied Robot Combining High Payload and Precision
On October 26, AgiBot launched the AGIBOT G2 Max, a safety-certified heavy-duty embodied robot designed for depalletizing, material transport, and production line feeding. The robot features 7-DOF force-controlled dual arms with a 20 kg single-arm and 40 kg dual-arm rated payload, a 50 kg peak payload, and a ±0.5 mm repeat positioning accuracy for tasks requiring both heavy lifting and precise placement.
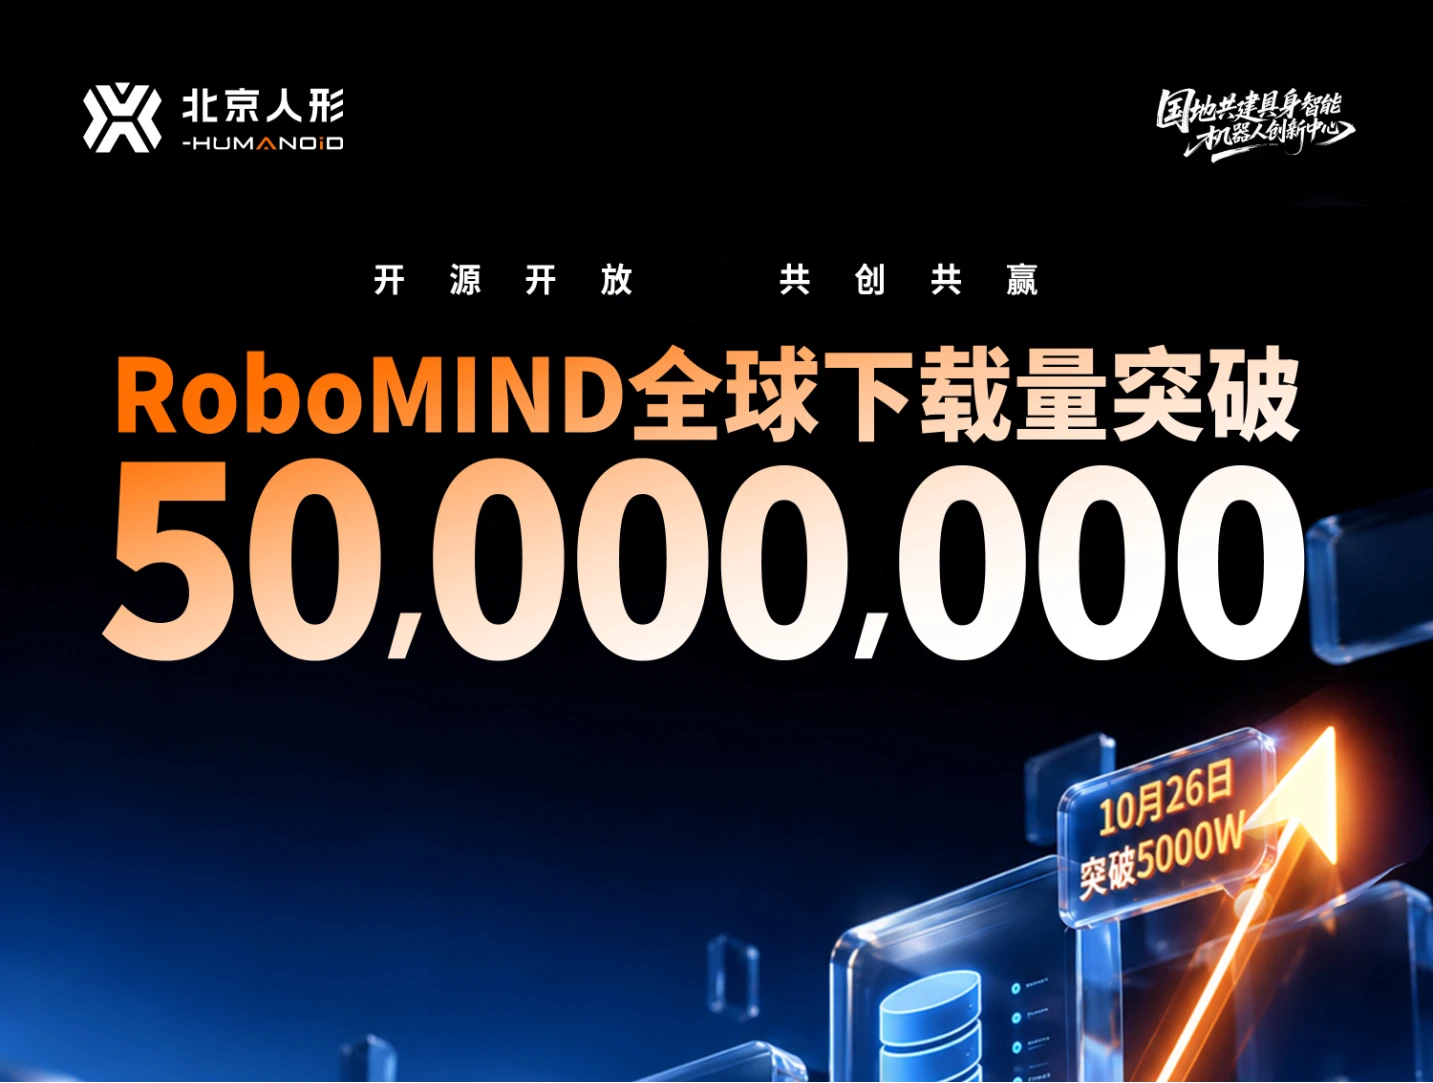
RoboMIND Open-Source Dataset Surpasses 50 Million Downloads, Latest 10 Million Reached in 18 Days
The Beijing Humanoid Robot Innovation Center announced on October 26 that the open-source dataset RoboMIND has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, accelerating significantly from the 223 days required for the first 10 million and 39 days for the second.