

Robotics
Robotics, embodied intelligence and real-world applications.
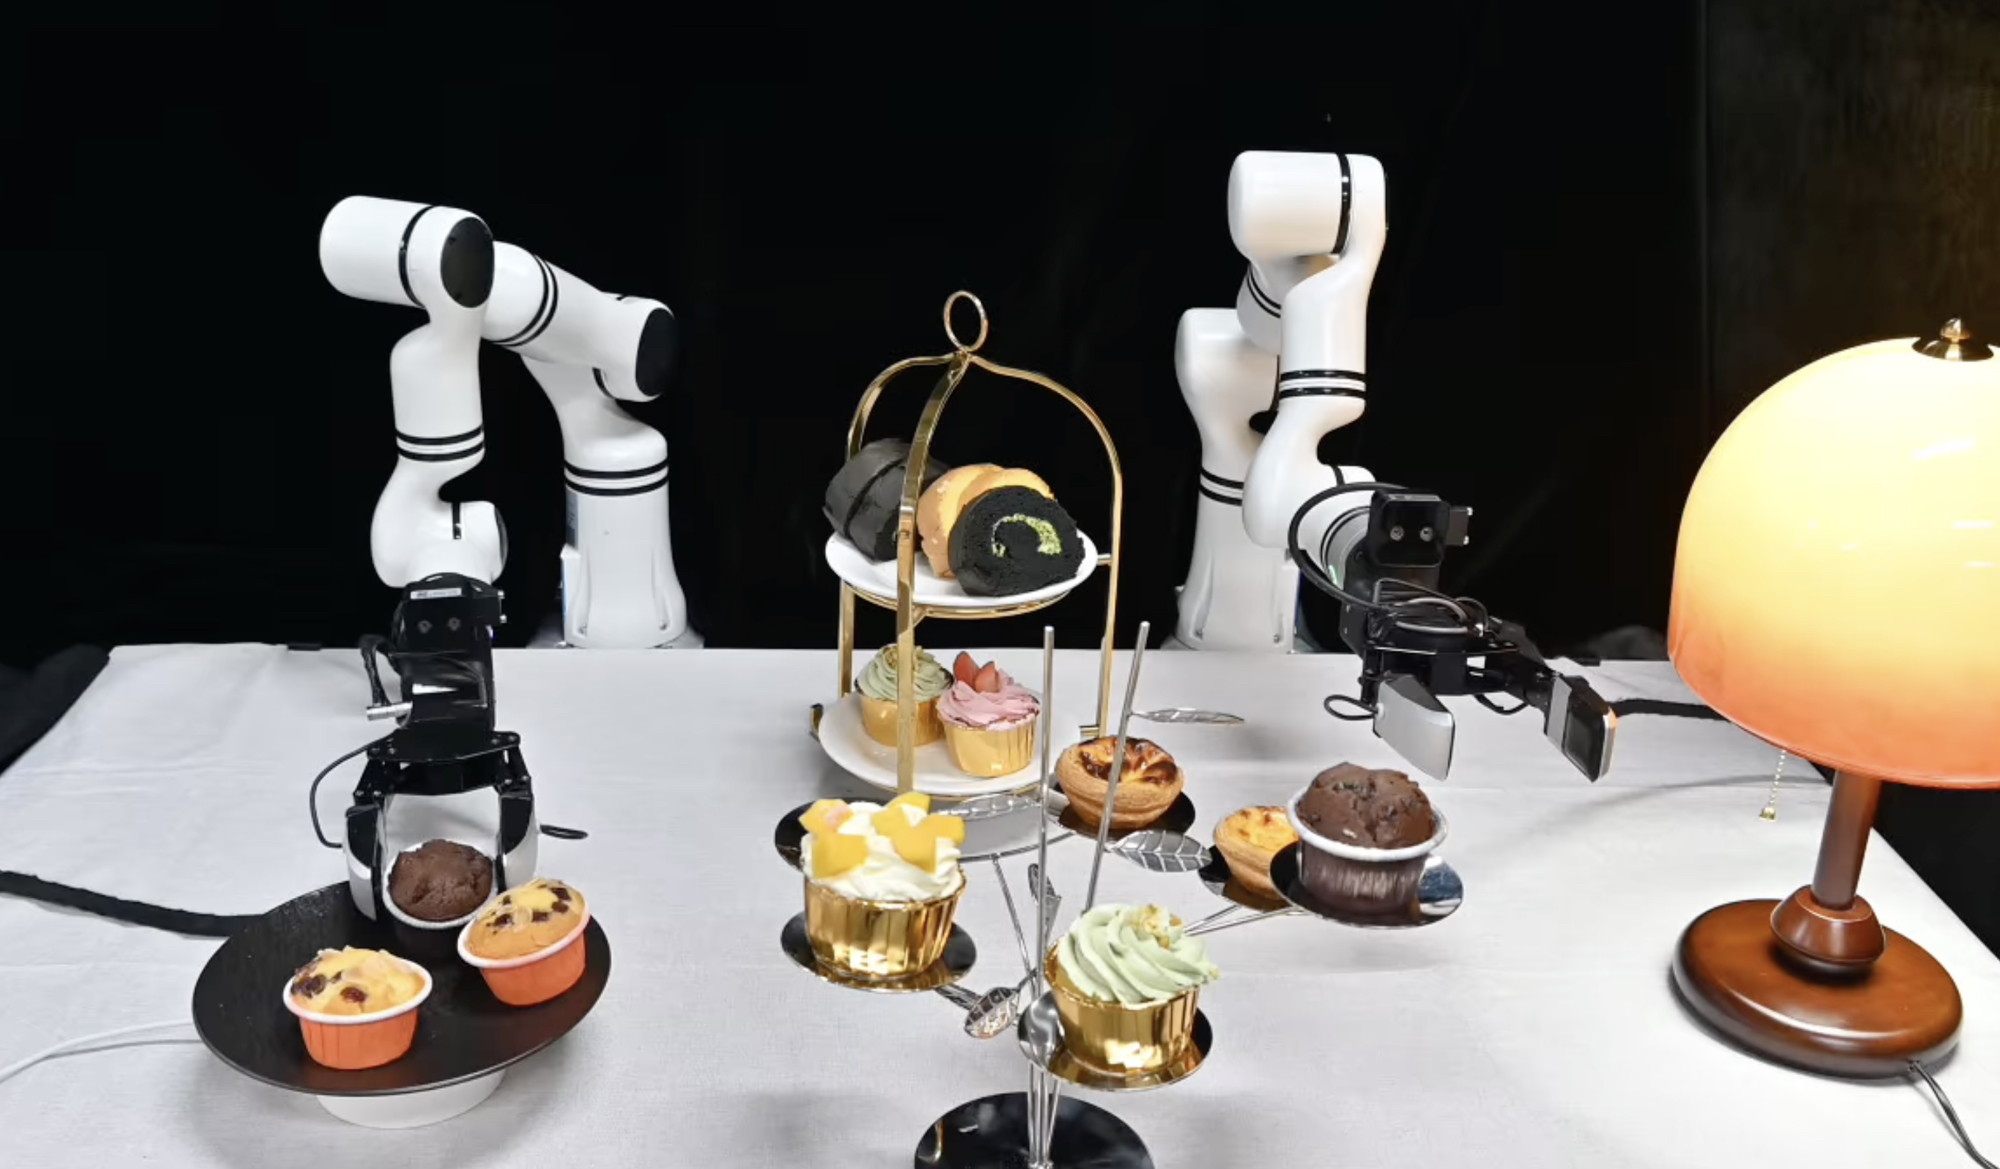
How 500,000 Hours of First-Person Video Can Add 'Touch' to Embodied World Models
BeingBeyond releases Being-H0.8, a latent tactile world-action model trained on over 500,000 hours of first-person video. By generating pseudo-tactile labels from visual data and unifying robot sensor inputs, it aims to bridge the gap between visual observation and physical contact for embodied AI.

Tencent Open-Sources Three Embodied AI Models to Build a Unified Robotics Foundation
Tencent's Robotics X Lab and Futian Lab, in collaboration with Hunyuan, have released three open-source embodied AI foundation models based on the Hunyuan large model: Hy-Embodied-VLM-1.0, Hy-Embodied-RxBrain-1.0, and Hy-Embodied-VLA-0.5.
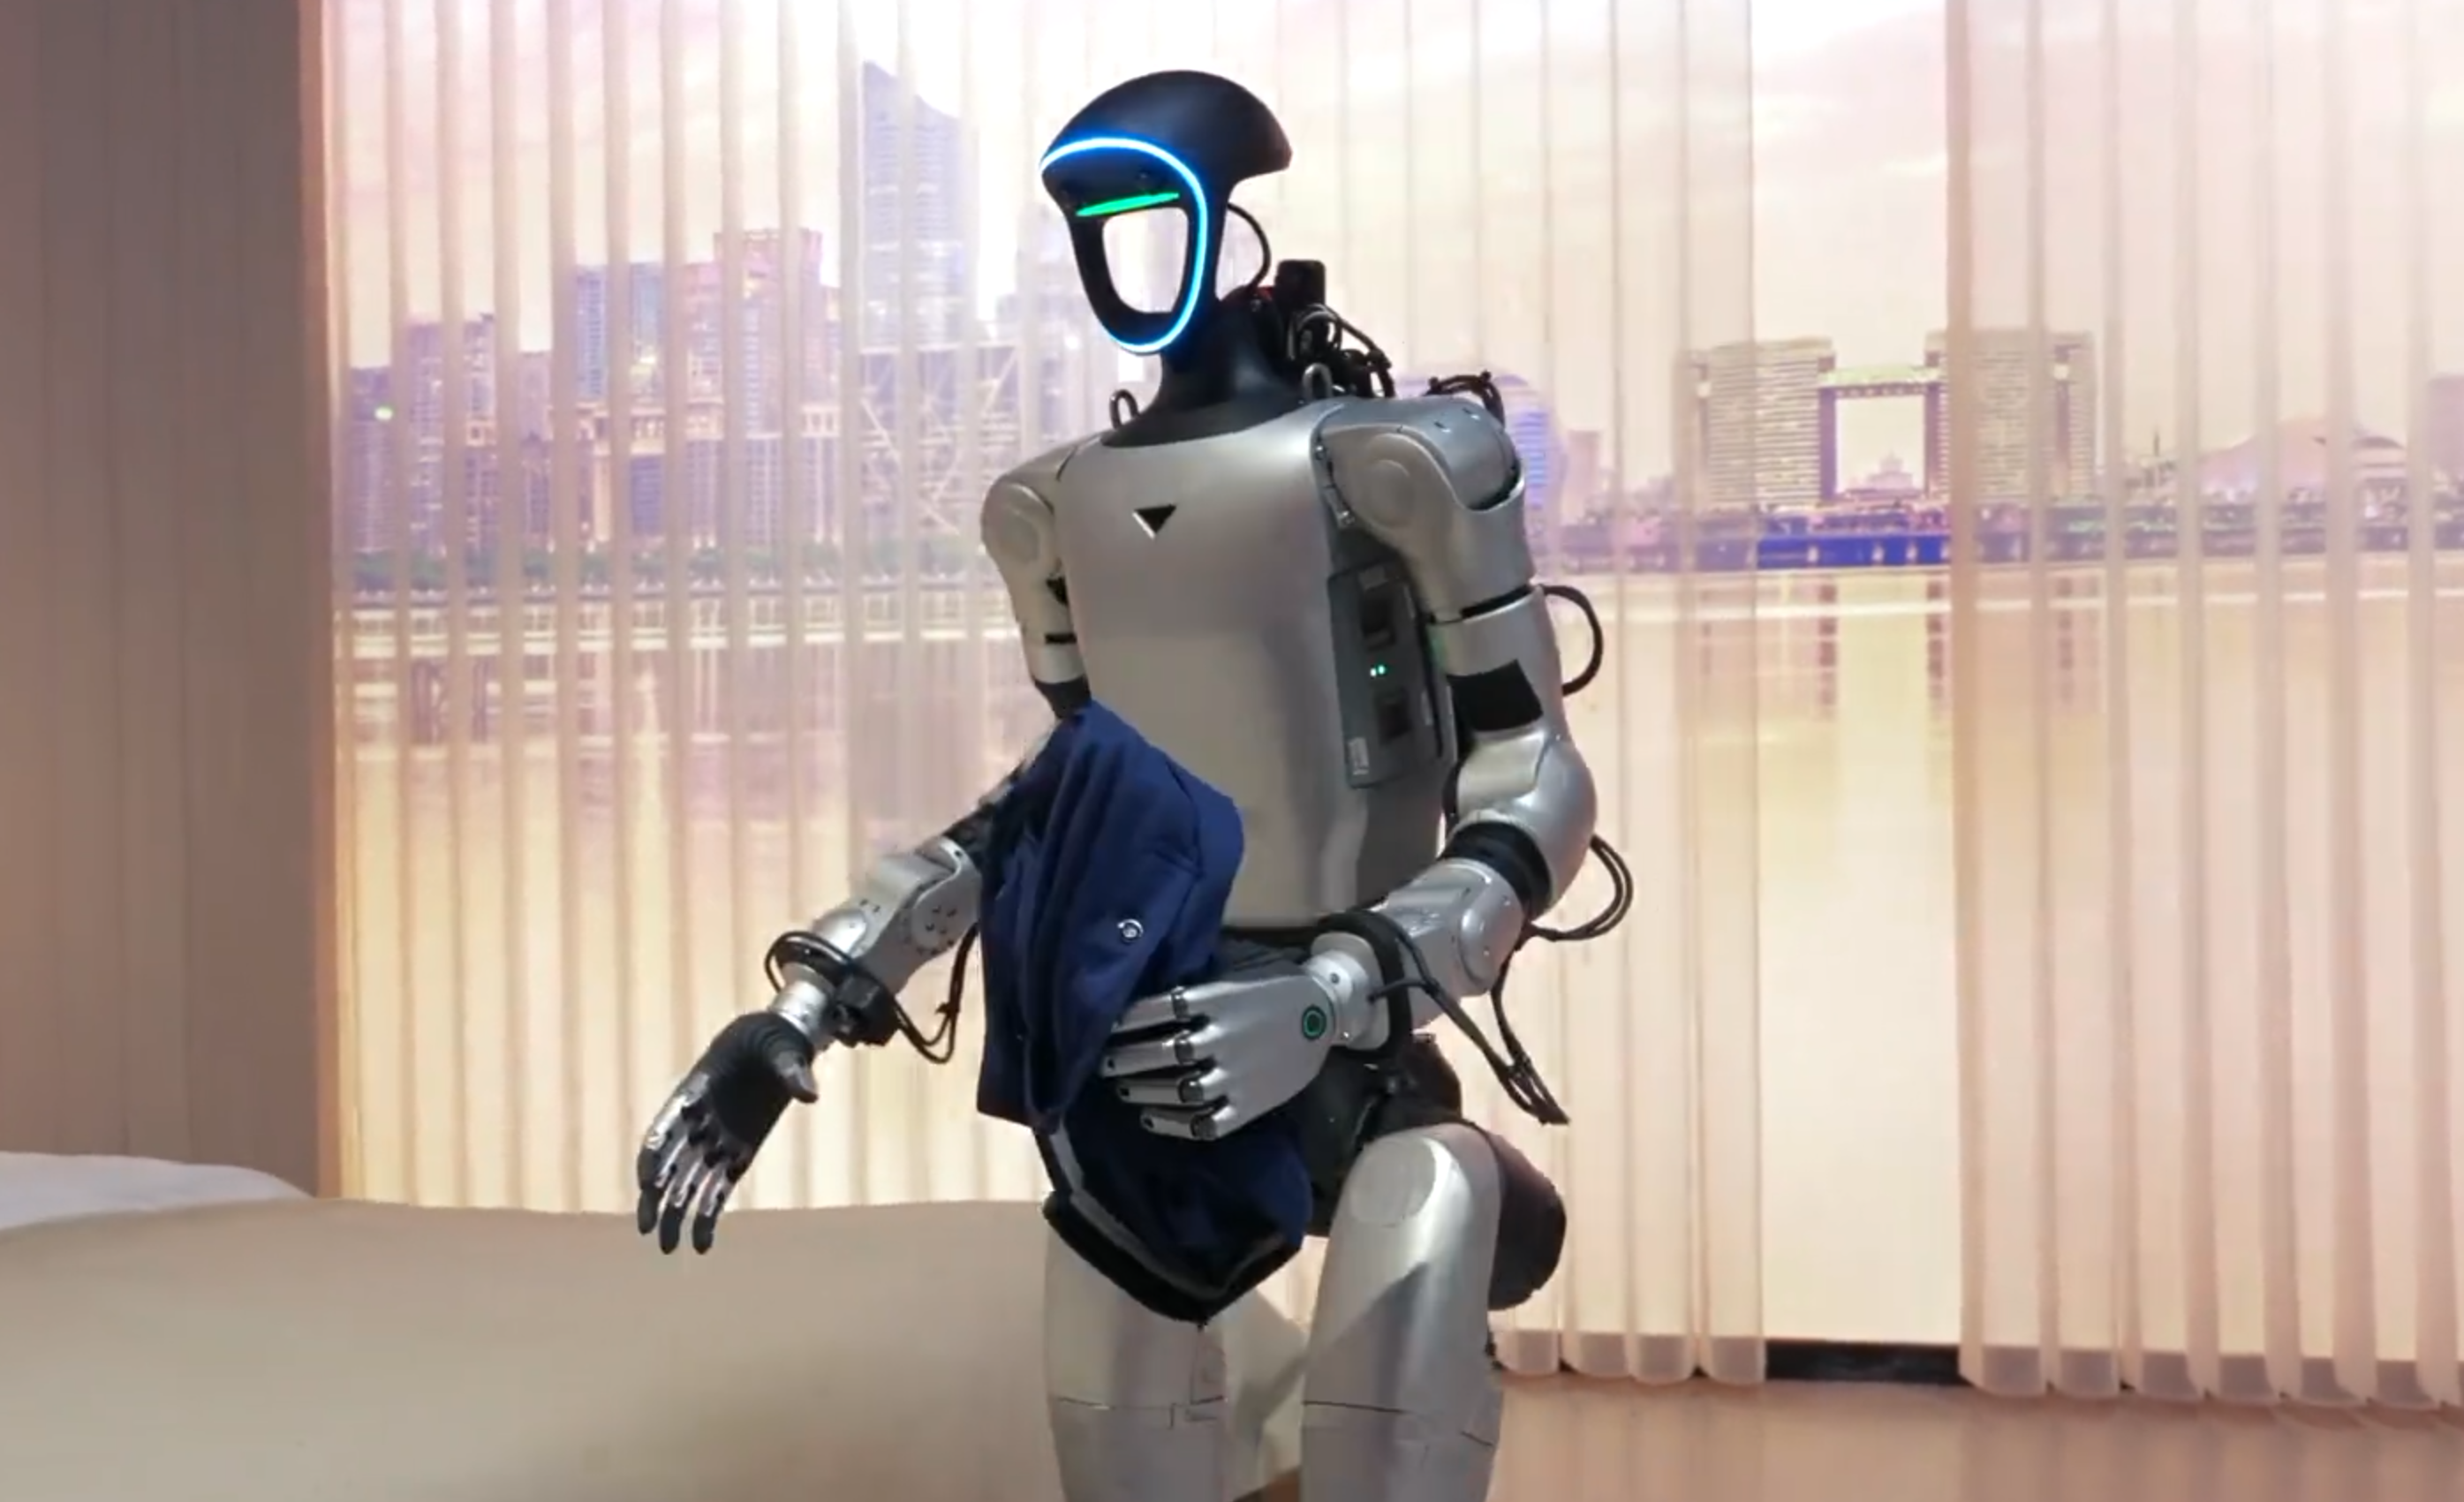
Unitree's New Brain Debuts, Moving Whole-Body Intelligence from Concept to Real Robots
On July 20, Unitree Technology officially released UnifoLM-OminiA-0.3, an embodied large model for home care tasks, natively integrated into the G1 robot. This marks a substantive step toward real-world deployment in civilian service.
Xiaomi Turns World Model Into a Data Engine, Beyond Prediction
Xiaomi has open-sourced U0, a 38B-parameter multimodal model that integrates five embodied synthesis functions. By treating embodied generation as a natural extension of foundation models rather than domain-specific fine-tuning, U0 acts as an expandable data engine, significantly enhancing robot generalization in real-world scenarios.
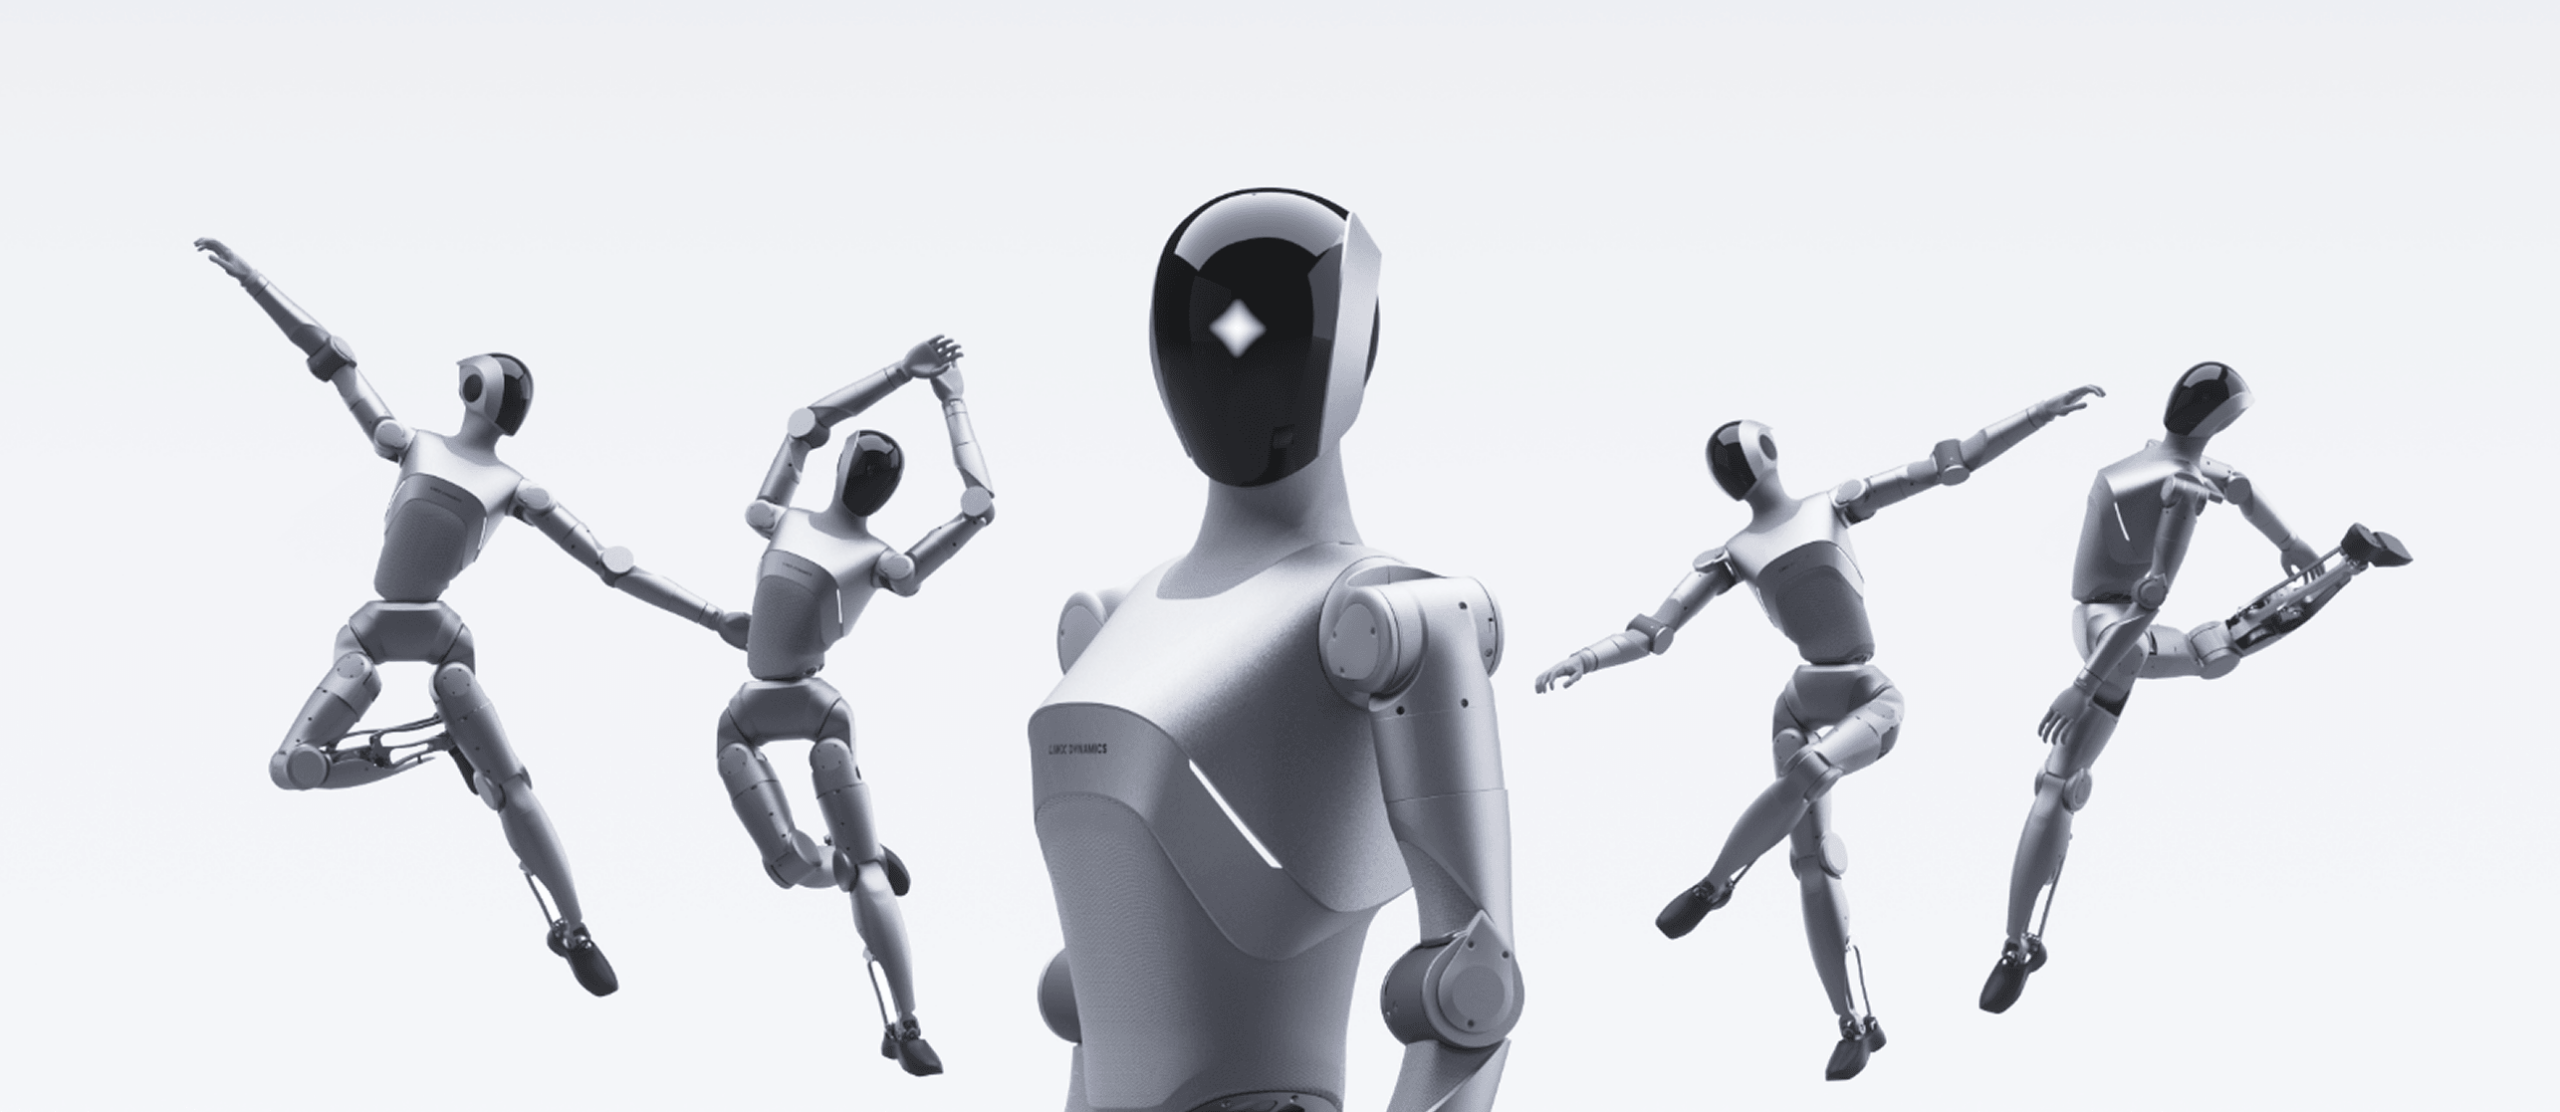
LimX Dynamics, Which Raised USD 400 Million in Six Months, Accelerates Plans for Public Listing
Embodied AI unicorn LimX Dynamics announces a nearly $200 million Pre-IPO round, bringing its half-year total to $400 million and pushing its IPO process forward.
ASPIRE: A Continuous Learning System for Robotics by Zhu Yuke, Jim Fan and NVIDIA
The new paper ASPIRE introduces a continuous learning system for embodied AI, where agents debug robot failures using execution traces, evolve solutions, and build reusable skill libraries.
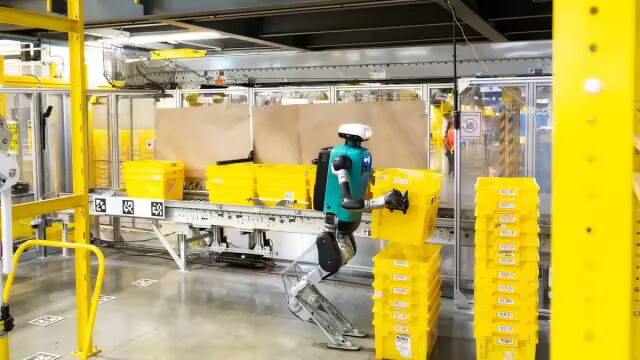
The First Embodied AI IPOs in China and America: Unitree and Agility's Divergent Paths
Agility Robotics and Unitree Technology represent two diverging paths for embodied AI commercialization. Agility focuses on specialized, vertical integration in logistics and manufacturing, while Unitree pursues a broad, horizontal hardware platform strategy to lower costs and expand ecosystems.
Nvidia's SimFoundry Bridges the Final Gap in Real-to-Sim Robot Data
Nvidia and Stanford's Fei-Fei Li team released SimFoundry, an automated Real2Sim infrastructure that transforms real-world environments into high-fidelity simulations for scalable robot policy training.
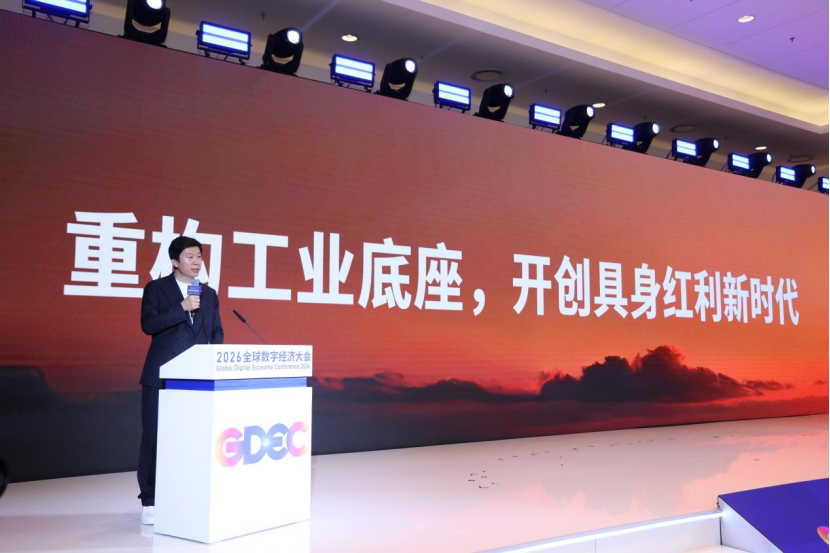
Xiaoyu Intelligence Unveils 'Embodied Dividend' Concept and First Welding Robot at Global Digital Economy Conference
At the 2026 Global Digital Economy Conference, Xiaoyu ZhiZao unveiled its first welding robot and three core technologies. CEO Qiao Zhongliang introduced the concept of 'Embodied Dividend,' defining it as using Embodied AI to create scalable silicon-based labor for heavy industrial tasks.
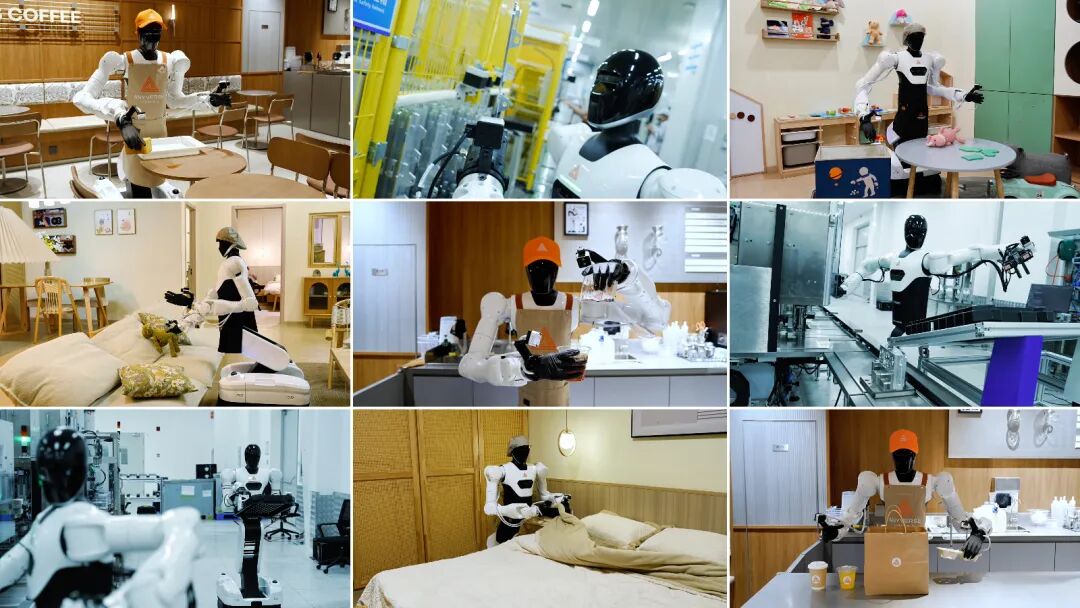
After Raising Hundreds of Millions, WuJie Dynamics Launches MWA Latent World Model
WuJie Dynamics officially released the MWA Embodied General Brain, a latent space world model based on long-horizon bidirectional physical causal chains, and topped the RoboCasa GR1 TableTop leaderboard. The company recently completed a $200 million angel round.
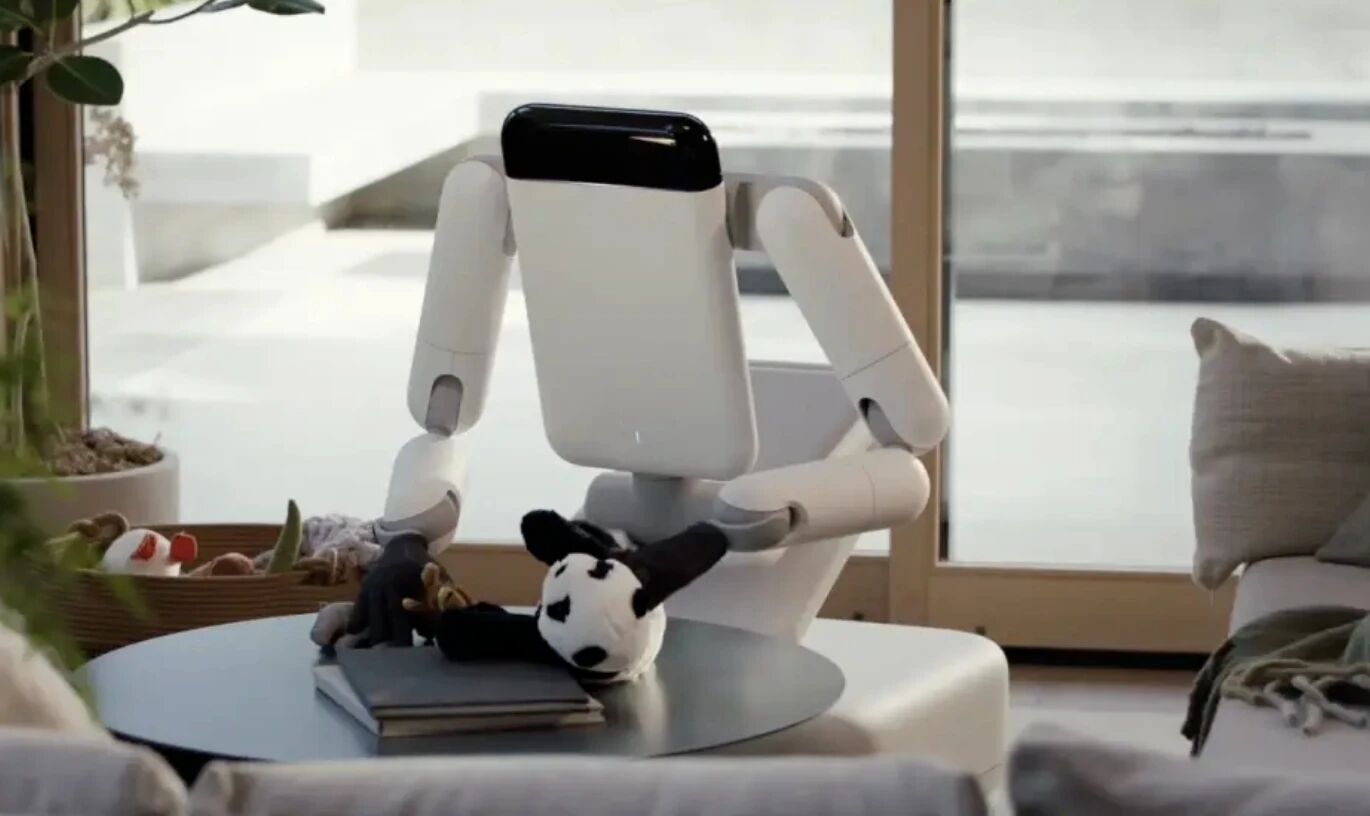
Genesis AI Unveils Eno: A Non-Humanoid Robot Prioritizing Dexterity Over Human Form
Genesis AI unveils Eno, a non-humanoid general-purpose robot with a foldable torso and advanced dexterous hands. The design prioritizes functional capability over human appearance, targeting industrial and laboratory applications first.
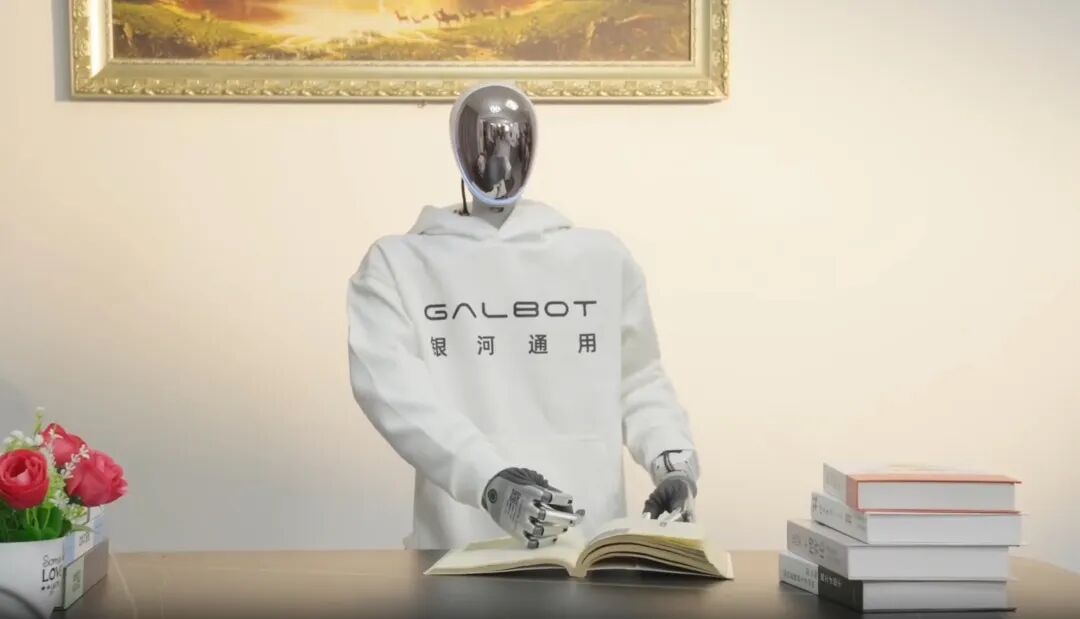
Galbot Unveils AstraBrain-WBC 0.5, a Breakthrough in Humanoid Robot 'Cerebellum' Control
Galbot launches AstraBrain-WBC 0.5, the world's first general-purpose cerebellum foundation model for humanoid robots. With 80.4 million parameters, it becomes the first in its field to reach the GPT-1 scale, addressing the trade-off between agility and generalization in motion control.