

Robotics
Robotics, embodied intelligence and real-world applications.
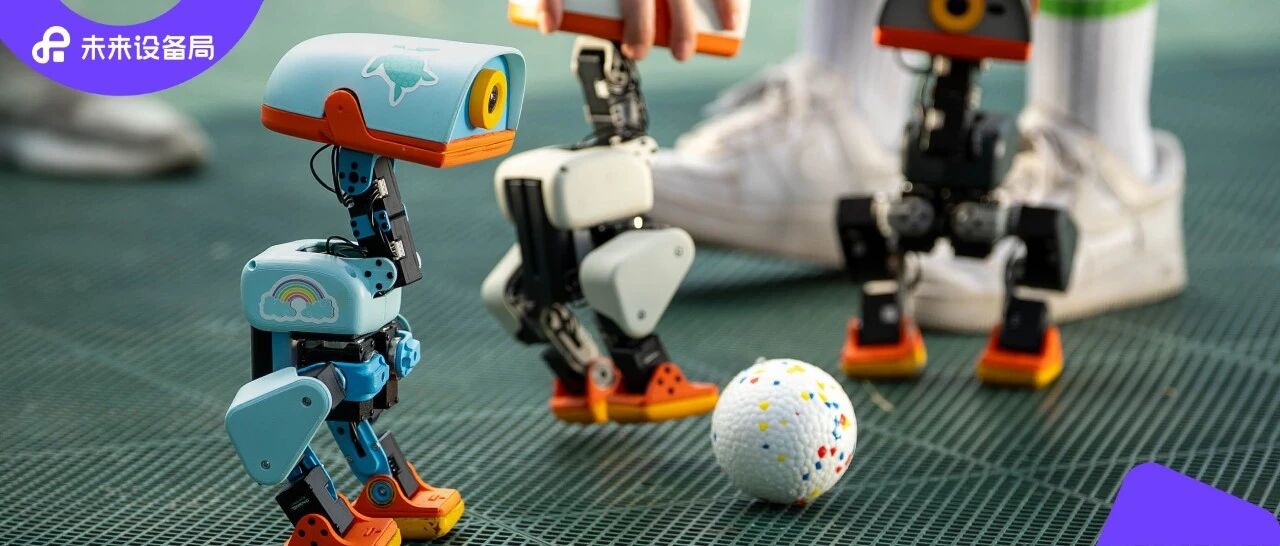
Hugging Face’s Pollen Robotics Launches $399 Microduck Robot for Embodied AI Training
Hugging Face’s Pollen Robotics has opened pre-orders for Microduck, a $399 bipedal robot designed as an affordable development platform for reinforcement learning and sim-to-real deployment.
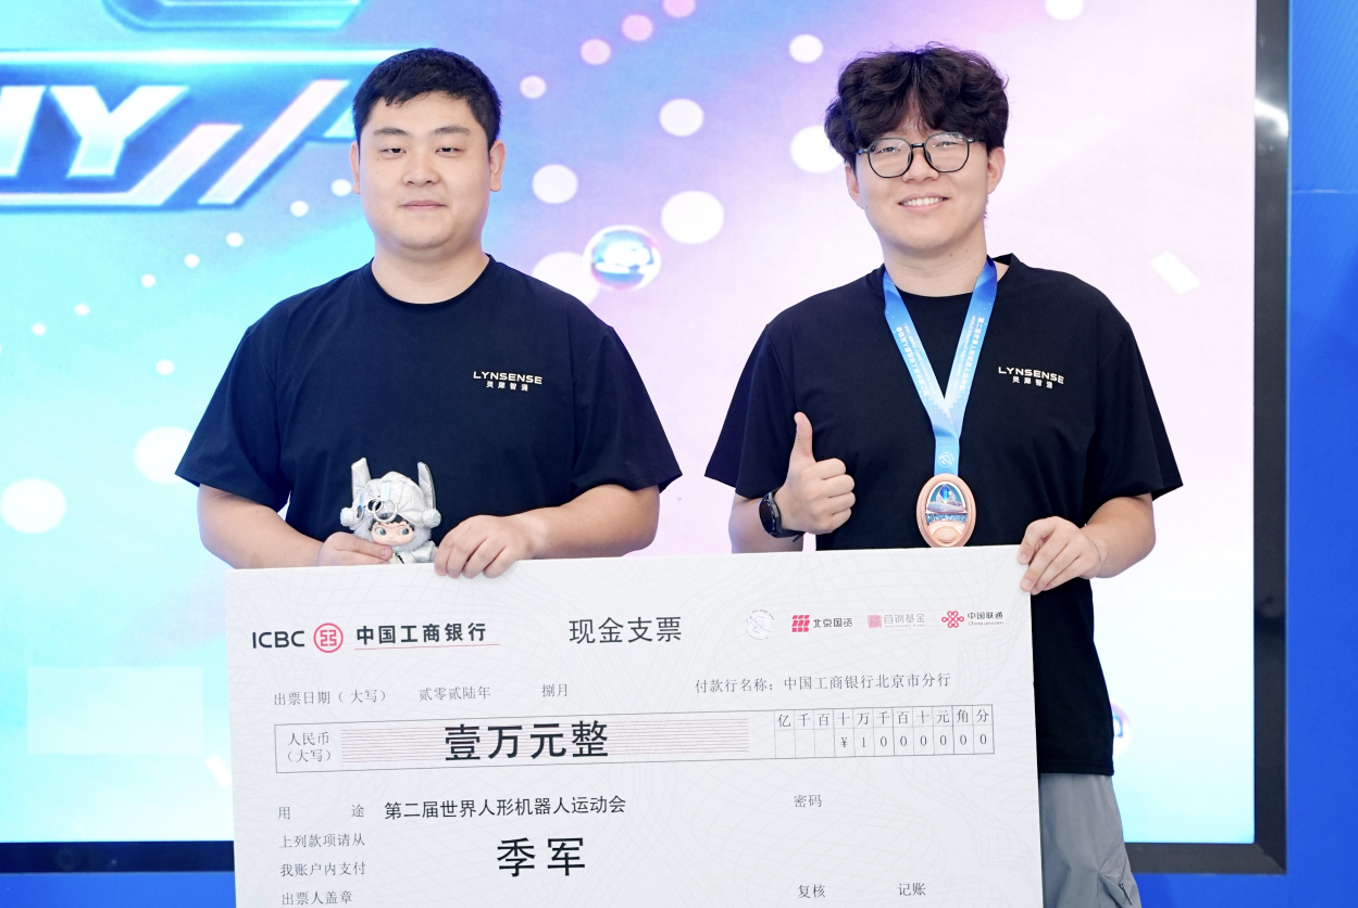
Newcomer Lingxi Zhiyong Ranks Top Three in World Humanoid Robot Games with ROSS Harness
Lingxi Zhiyong's robot achieved 160 points and ranked among the top three at the World Humanoid Robot Games. The company attributes this success to its self-developed ROSS Harness Agent, which bridges AI models and hardware execution.
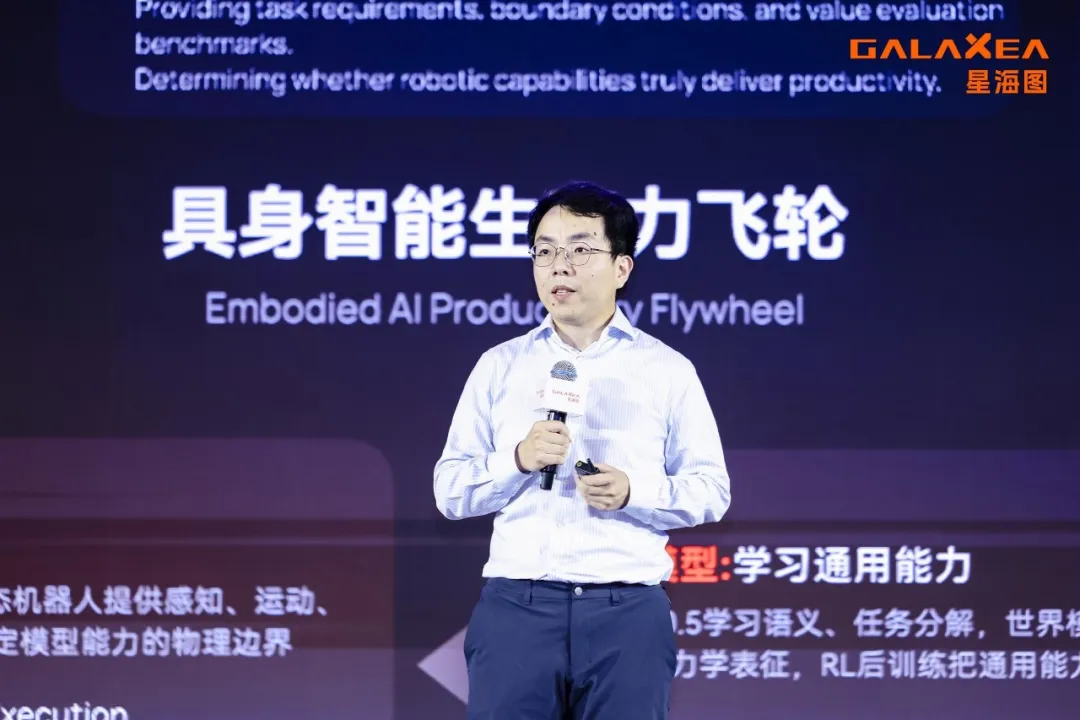
Galaxea's Hang Zhao: The Next Embodied AI Scaling Goes Beyond Pre-Training
At the 2026 WRC Forum, Galaxea Chief Scientist Hang Zhao argues that Embodied AI's next scaling depends not just on pre-training data and models, but on continuous learning from real-world operations through post-training and real-robot reinforcement learning.

Why AgiBot Became the Top Medal Winner at the Robotics Competition
At the 2nd World Humanoid Robot Games, AgiBot won 18 gold, 16 silver, and 12 bronze medals, ranking first in both gold and total medal counts. This success highlights its dual strengths in embodied AI motion control and commercial deployment capabilities.

Huawei Veteran Zhou Shunbo’s New Home Robot Startup Secures Hundreds of Millions in Funding
Zhou Shunbo, founder of Ou La Wan Xiang, discusses his journey from Huawei to creating a wheeled home robot. He argues that data is the first principle of embodied AI and believes that high-value, non-AGI-dependent robots can succeed in family scenarios.
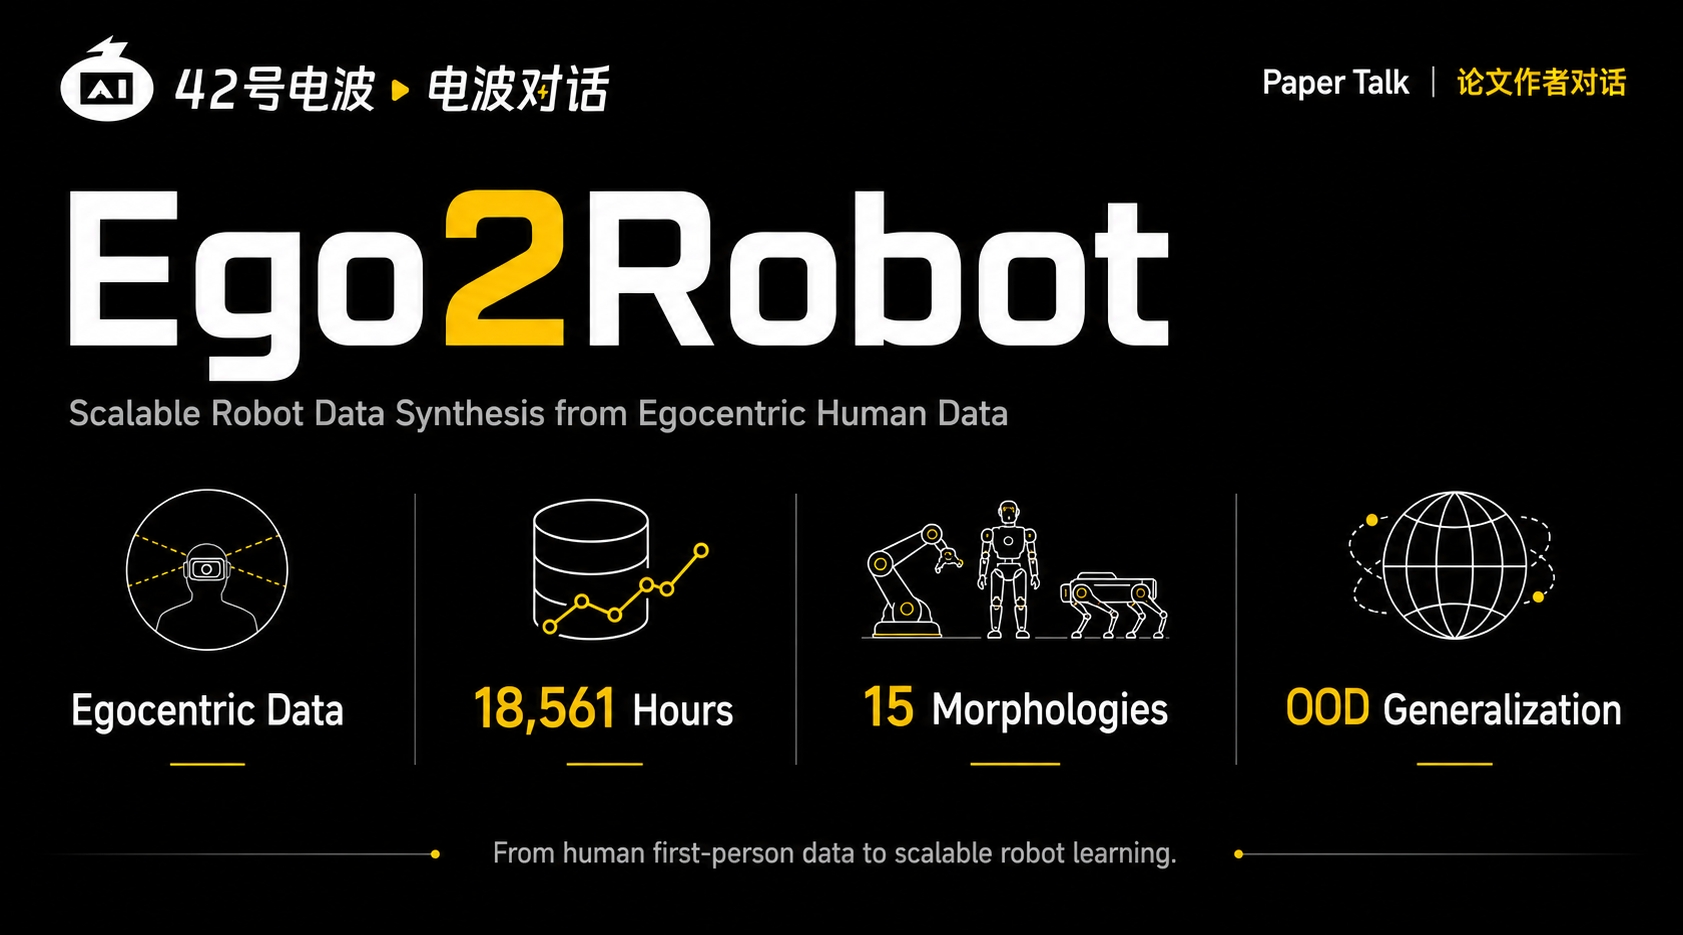
Ego2Robot: Scaling Robot Data Synthesis from Egocentric Human Video
Ego2Robot demonstrates that scalable robot data synthesis from egocentric human video relies less on model architecture and more on rigorous data governance, including action alignment, visual alignment, and multi-level quality filtering.
Track4Action: Distilling 3D World Dynamics Into VLA Policies for Robust Robot Control
A new approach by Shanghai Jiao Tong University and Zhejiang University integrates 3D world tracking knowledge into Vision-Language-Action models to help robots understand how their actions change the physical environment.
Three Major Embodied AI Papers Reveal the Gap Between VLMs and Reliable Robotic Agents
Recent reports from Anthropic highlight the race to make LLMs and VLMs the brains of robots. Three new papers from Meta/NUS/University of Washington, Sungkyunkwan University, and Tsinghua/Purdue propose different frameworks to bridge the gap between frozen models and reliable robotic agents.
The University of Hong Kong and INFIFORCE Team Tests VLA Continual Learning on Real Robots
A new study from HKU and other institutions demonstrates how experience replay and action normalization can prevent catastrophic forgetting in Vision-Language-Action models during continuous learning on real-world robots.
First collaborative study by 30 researchers from PKU, NTU & others maps the embodied data pyramid
A comprehensive review by nearly 30 researchers clarifies the five-layer embodied data pyramid, exploring data scaling laws, model-specific requirements, and the synergy between simulation and real-world data.

Chemical Materials Firm's Subsidiary Launches Consumer Robot Division in Shanghai
PrimeBot New Ventures (Shanghai) Technology Co., Ltd., a robotics subsidiary of Shangwei New Materials Technology Co., Ltd., has officially settled in Zhangjiang Robotics Valley, Pudong, Shanghai. The project was signed during the 2026 World Artificial Intelligence Conference (WAIC).
D-Robotics Unveils 0.04B X-Lens for Real-Time Depth Estimation on Heterogeneous Cameras
D-Robotics, in collaboration with Tokyo University and Suzhou University, released a technical report on July 15 introducing X-Lens, a lightweight depth estimation model with only 0.04B parameters. Capable of real-time metric depth estimation with heterogeneous cameras on edge devices, X-Lens uses a 'ray space' approach to unify fisheye and pinhole camera inputs, achieving high accuracy and efficiency compared to larger models.