
Embodied AI
126 related stories
Nvidia Uses SimFoundry to Bridge the Last Mile of Robot Real2Sim
Nvidia and Stanford's Fei-Fei Li team released SimFoundry, an automated Real2Sim infrastructure that transforms real-world environments into high-fidelity simulations for scalable robot policy training.
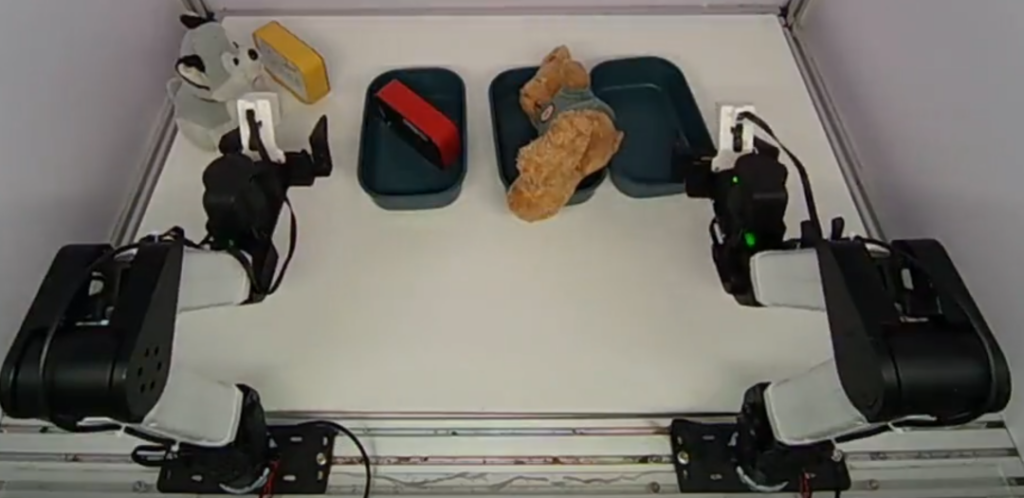
KEMO: Equipping VLA with a 'Memory Plugin' Boosts Long-Horizon Task Performance by 23.6%
XDOF releases KEMO, an event-driven keyframe memory plugin for VLA models that improves long-horizon manipulation success rates by 23.6% without retraining the base model.
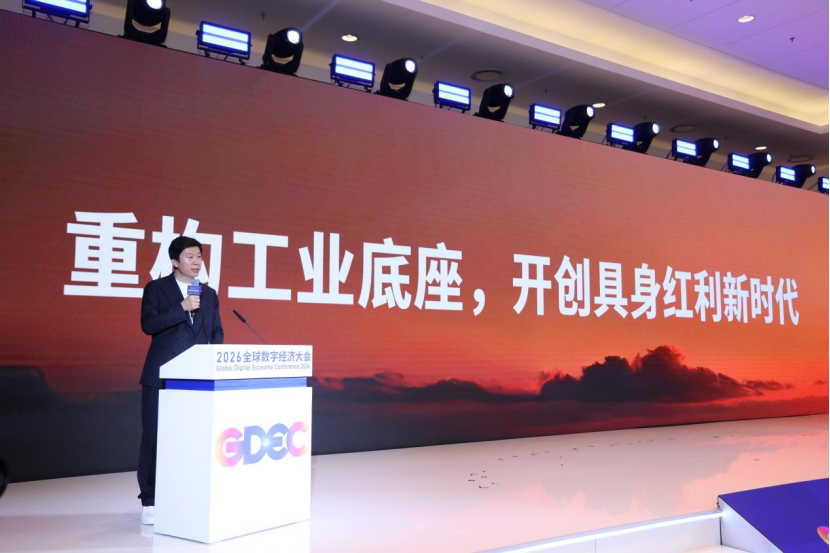
Xiaoyu ZhiZao's Qiao Zhongliang First Proposes 'Embodied Dividend', Three Technologies Launched Alongside First Welding Robot
At the 2026 Global Digital Economy Conference, Xiaoyu ZhiZao unveiled its first welding robot and three core technologies. CEO Qiao Zhongliang introduced the concept of 'Embodied Dividend,' defining it as using Embodied AI to create scalable silicon-based labor for heavy industrial tasks.
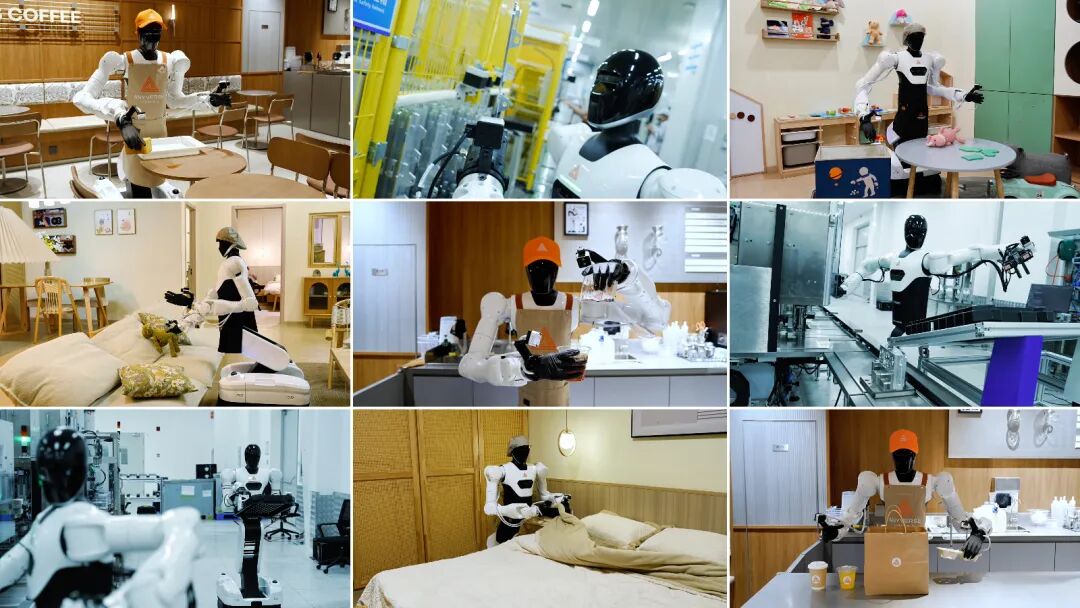
After Raising Hundreds of Millions in Funding, Top Rankings Achieved: WuJie Dynamics Releases MWA Latent Space World Model
WuJie Dynamics officially released the MWA Embodied General Brain, a latent space world model based on long-horizon bidirectional physical causal chains, and topped the RoboCasa GR1 TableTop leaderboard. The company recently completed a $200 million angel round.
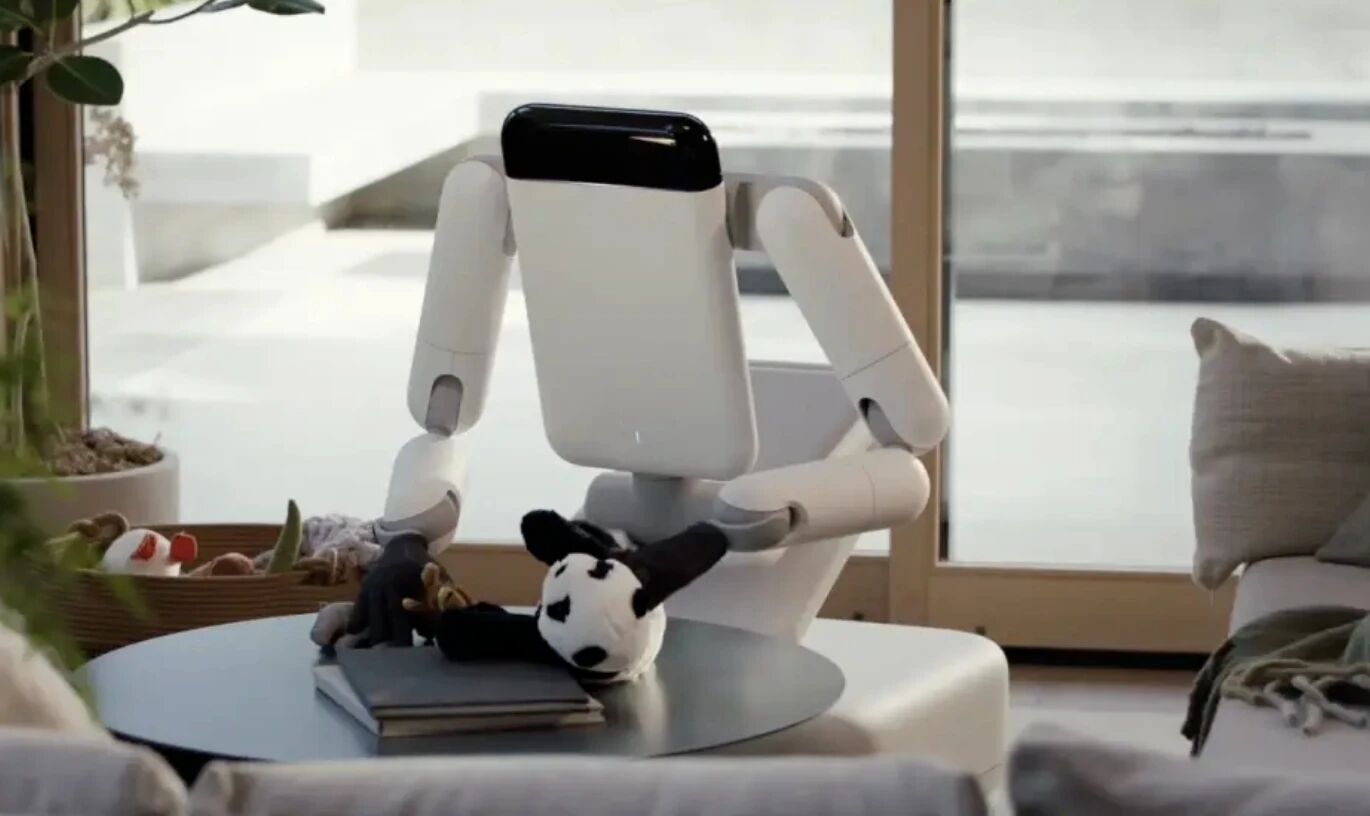
Genesis AI Releases Eno: Robot Commercialization May Not Require a Humanoid Form
Genesis AI unveils Eno, a non-humanoid general-purpose robot with a foldable torso and advanced dexterous hands. The design prioritizes functional capability over human appearance, targeting industrial and laboratory applications first.
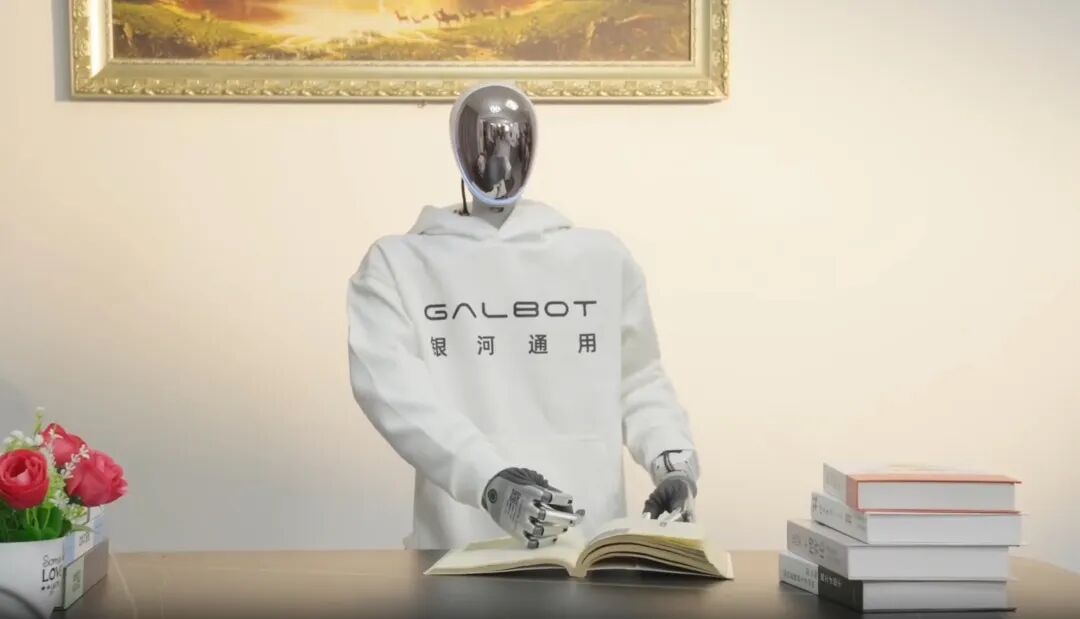
General Robotics Unveils AstraBrain-WBC 0.5: The GPT Moment for Humanoid Robot 'Cerebellum'
General Robotics launches AstraBrain-WBC 0.5, the world's first general-purpose cerebellum foundation model for humanoid robots. With 80.4 million parameters, it becomes the first in its field to reach the GPT-1 scale, addressing the trade-off between agility and generalization in motion control.
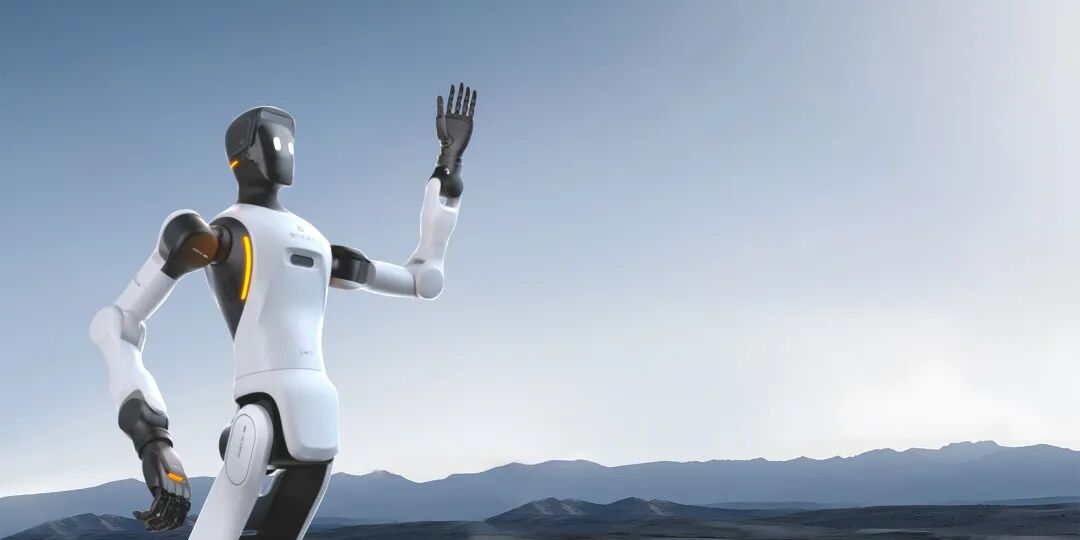
From Zhiyuan's 6-Day Factory Operations, Viewing the 'Deployment Phase' Turning Point of Embodied AI
Zhiyuan's Genie G2 robots completed over 11,000 tablet quality inspections with a 99.985% success rate in a transparent 6-day factory trial, marking the industry's shift from experimental 'development phase' to scalable 'deployment phase'.
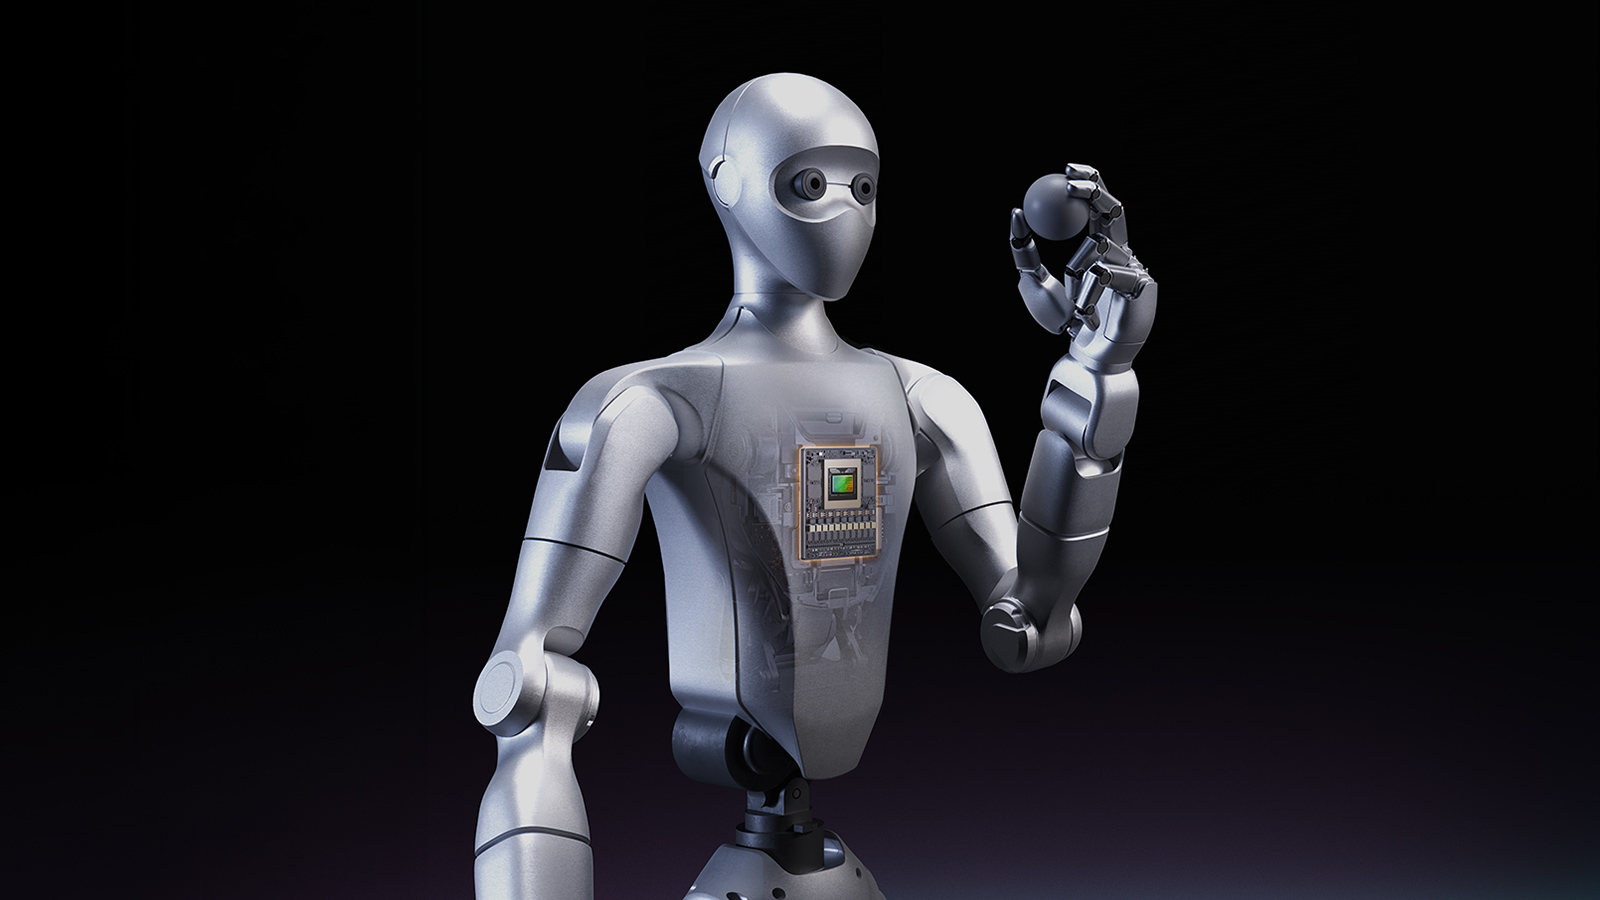
Behind the Unitree Controversy: NVIDIA's New Compute Business
While Unitree faces regulatory scrutiny, NVIDIA is leveraging its Isaac GR00T reference design to build a 'CUDA-like' ecosystem for embodied AI, turning robot training into a sustainable compute business.
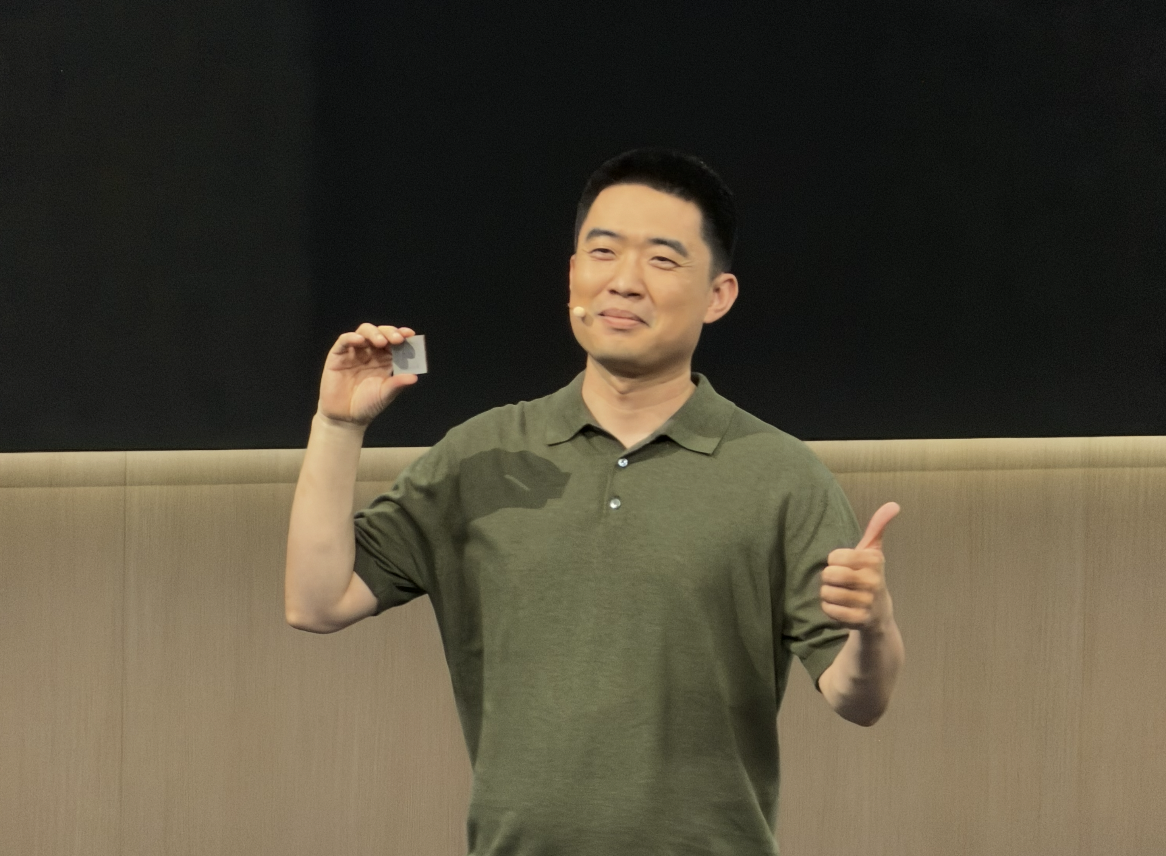
Li Auto's Livis Day: Moving Beyond Car Manufacturing to Define Embodied AI
At Livis Day, Li Auto unveiled its transition from a traditional automaker to an AI-driven company, showcasing new chips, embodied AI models, and concrete OTA milestones for 2026.
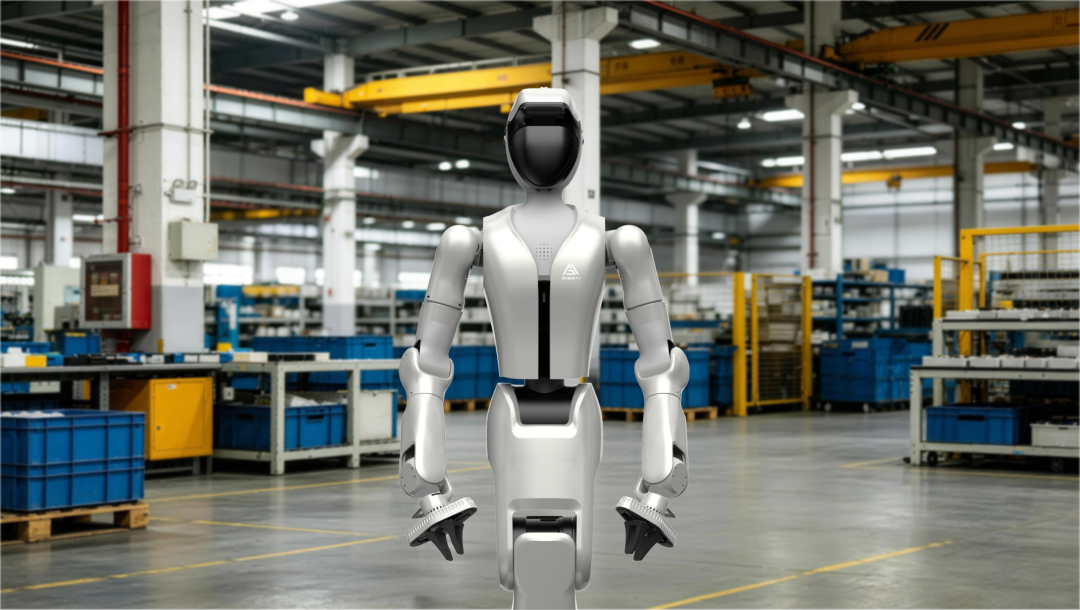
JiJia Vision Secures Another 1 Billion RMB in Funding: How World Models Are Entering Homes and Factories?
JiJia Vision has completed a 1 billion RMB B2 round of financing, bringing its total funding to 3.5 billion RMB in just three months. The company is leveraging its "Dual Pyramid" data and algorithm system to deploy embodied AI with world models in both C-end home scenarios and B-end industrial applications.
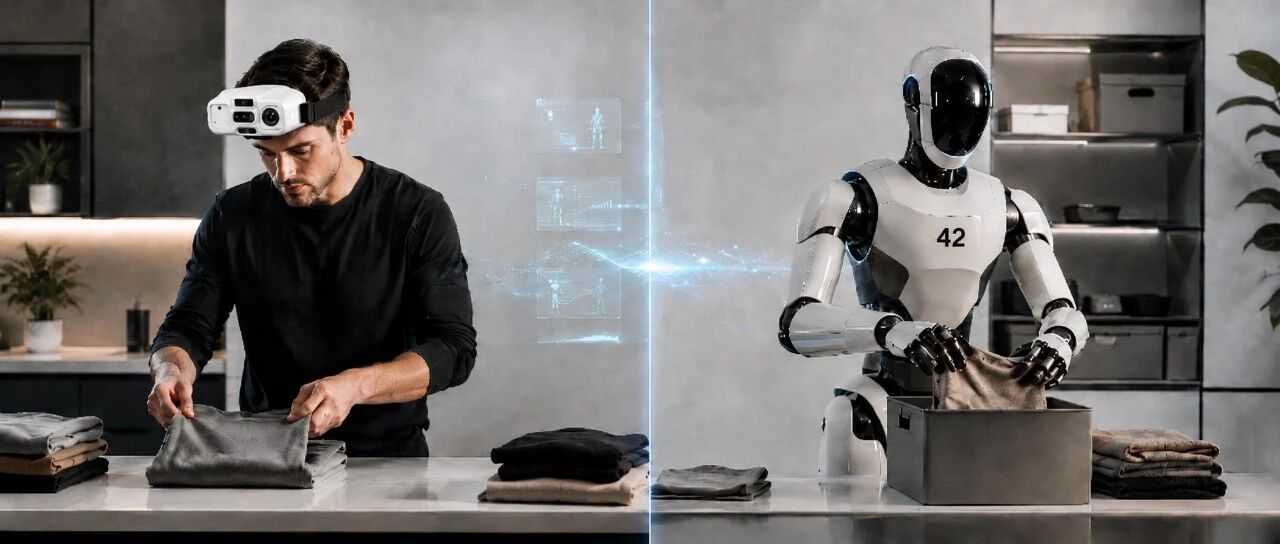
Robots Are Starting to 'Eat Data': From Indian Data Factories to the Hidden Supply Chain of Billion-Dollar Humanoid Robots
As Embodied AI companies face a critical data shortage, a new supply chain is emerging. This article explores how human demonstration data, particularly Ego Data from low-cost labor hubs like India, is becoming the key asset in training general-purpose humanoid robots.
Starting from Bottom-Up Instincts, Oakfruit Robotics Unveils 'Instinct-Driven' Technical Route
Oakfruit Robotics has released its 'instinct-driven' technical route for Embodied AI, adopting a bottom-up approach where robots acquire operational instincts at the foundational level and autonomously emerge with intelligent manipulation through interaction with the physical world.